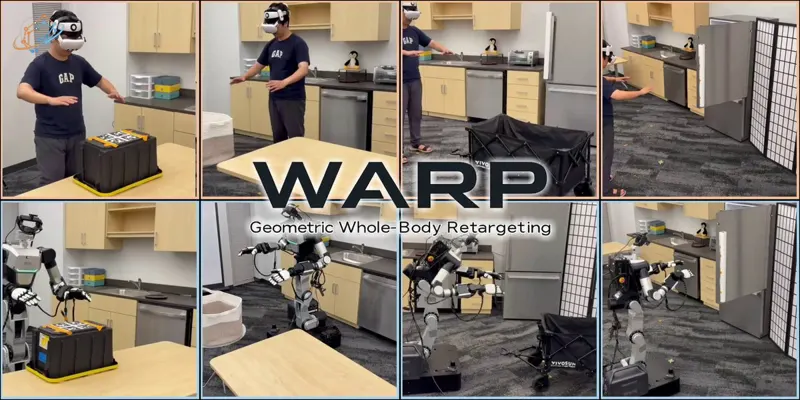
0:12WARP Retargets Offline Human Motion into Robot Actions@DanielZhenyang · 132 views · 2026-08-19RetargetingWARPHuman Motion
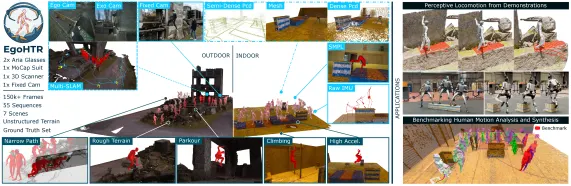
EgoHTR: Egocentric 4D Demonstrations of Human Terrain TraversalDeploying humanoid robots in unstructured terrain remains an open problem. While classic reinforcement learning struggles with the sheer complexity of real-world interactions, more promising methods leveraging human priors remain limited to models lacking contextual awareness. The restricted motion synthesis is a direct consequence of existing dataset pipelines failing to capture human-scene sequences in challenging environments. To bridge this gap between humanoid learning and scene reconstruction, we introduce the Egocentric Human-Terrain Reconstruction (EgoHTR) dataset. We develop and open-source a reconstruction pipeline capturing 55 scene-aligned 4D human motion sequences in diverse, complex environments using a multi-sensor setup of egocentric wearables and a portable 3D scanner. The resulting dataset comprises over 150k frames, which we evaluate against motion-capture ground truth, demonstrating state-of-the-art accuracy and establishing a rigorous benchmark for human motion analysis and synthesis. Further, we leverage this data to train perceptive locomotion policies, demonstrating hardware deployment on a Unitree G1 for reconstructed reference motions. Our pipeline enables community-driven dataset extensions and factors the problem to help researchers build foundational, context-aware robots that reliably traverse uneven terrain.Alex Brandes, Haig Conti Georges Sajelian, Manthan Patel·Jul 15, 20264DTerrain TraversalGait optimizationJul 15, 2026
 0:12