GeoFlow-SLAM: A Robust Tightly-Coupled RGBD-Inertial and Legged Odometry Fusion SLAM for Dynamic Legged Robotics
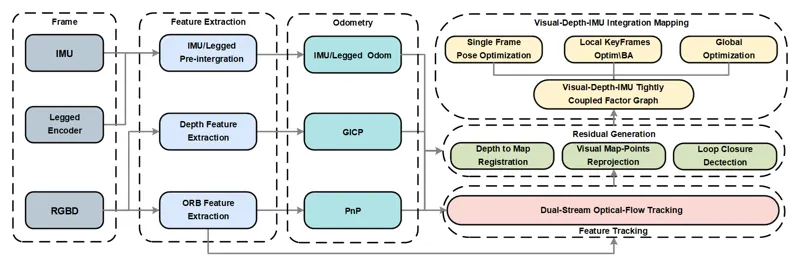
GeoFlow-SLAM targets the feature-matching, initialization, and texture-robustness failures that arise when legged robots move aggressively at high frequency. It tightly couples dual-stream optical flow, legged odometry, PnP, GICP, and depth-to-map geometric constraints in one optimization framework. Experiments on Unitree Go2 and G1 robots plus OpenLORIS, ScanNet, and TUM datasets show state-of-the-art robustness and accuracy.
Xiao, Tingyang, Zhou, Xiaolin, Liu, LiuMar 18, 2025
SLAMLegged RoboticsRGBD-InertialMar 18, 2025