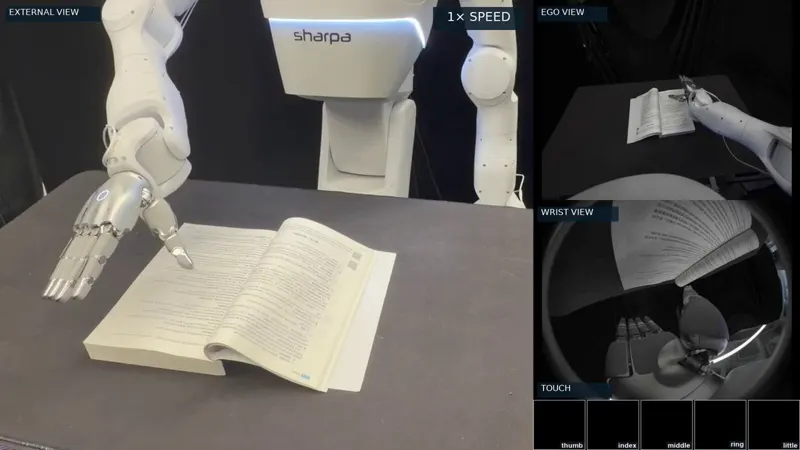
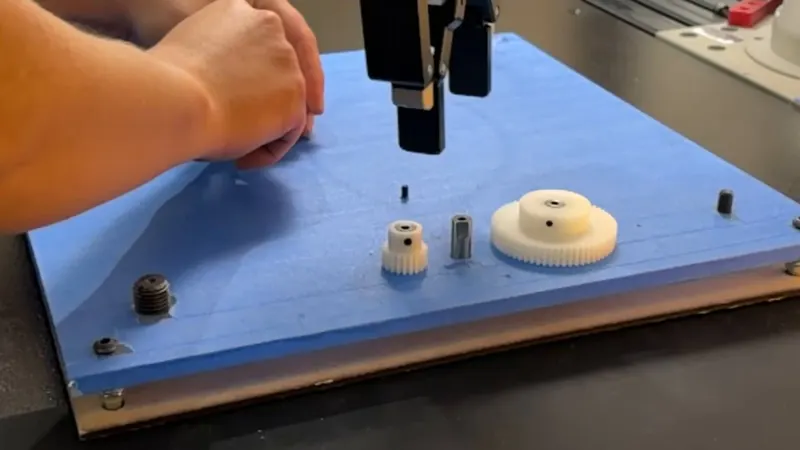
ORA:开放权重模型零样本控机械臂
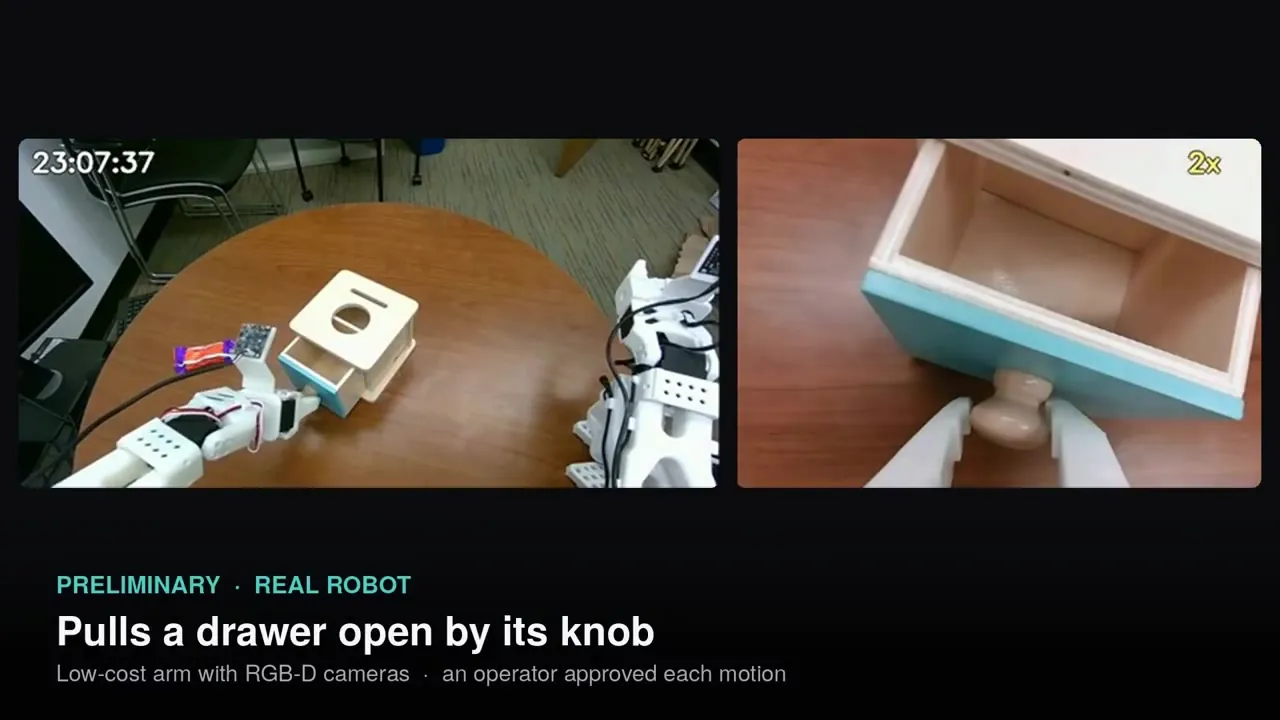
视频加载中
视频加载中ORA 用 DeepSeek V4.1-Flash 零样本控机械臂,无需 VLA 或训练,仅凭视觉与工具调用;两个仿真基准达 69.2% 和 81.4%。
ORAOpen Robot-Use AgentsDeepSeek V4.1-FlashRobot-Use AgentOpen-Weight ModelsZero-Shot ManipulationRobot HarnessVisual Grounding运动规划具身智能开放权重模型机器人智能体零样本操作
Category: manipulation
Author: @haoailab
Date: 2026-10-16T00:00:00
Duration: 53.2s
Reference: https://github.com/hao-ai-lab/ORA