Skip to content
← Back to Components

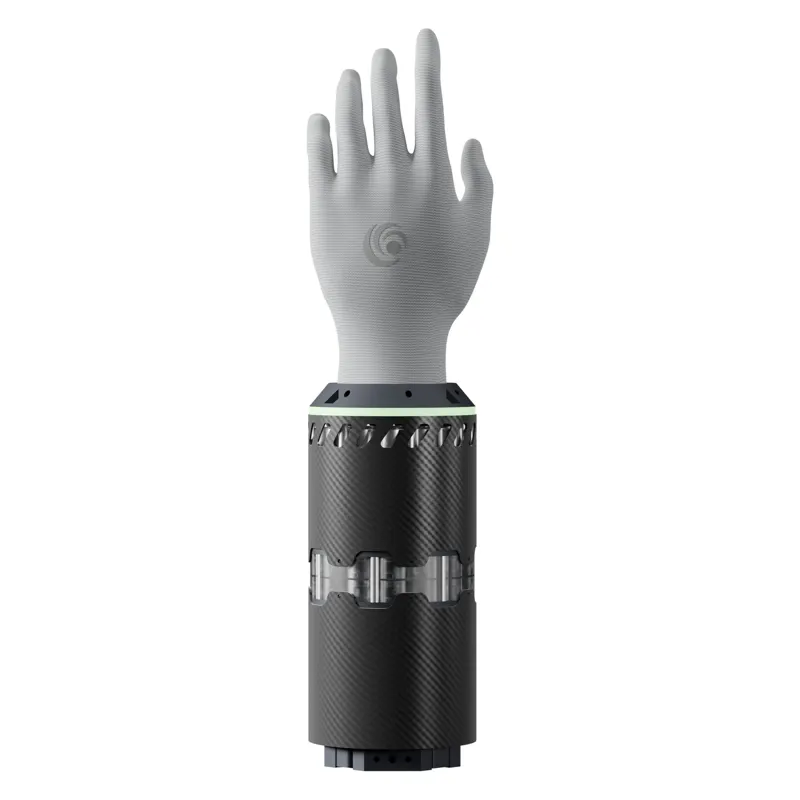
Yuequan Bionic X-Hand M1 Bionic Dexterous Hand

Vendor: Moon Spring Bio-mimicry

Product: X-Hand M1
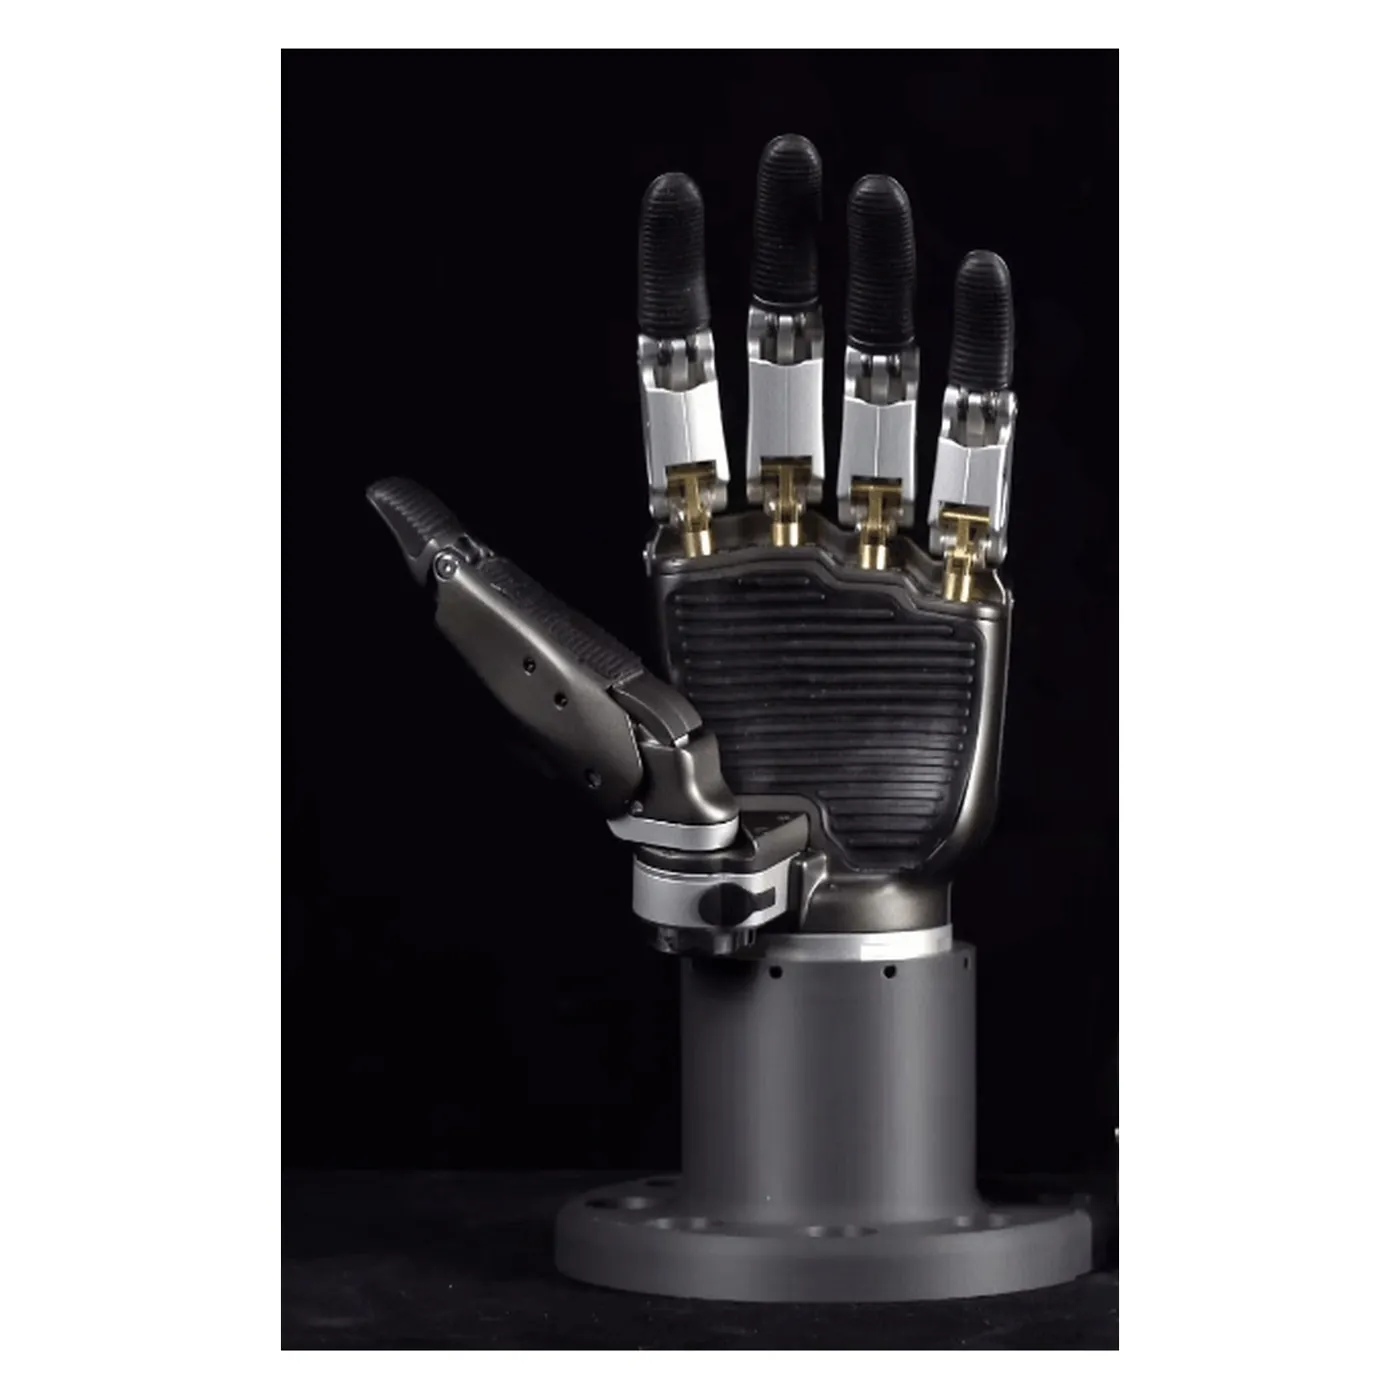
Yuequan Bionic X-Hand M1 Bionic Dexterous Hand

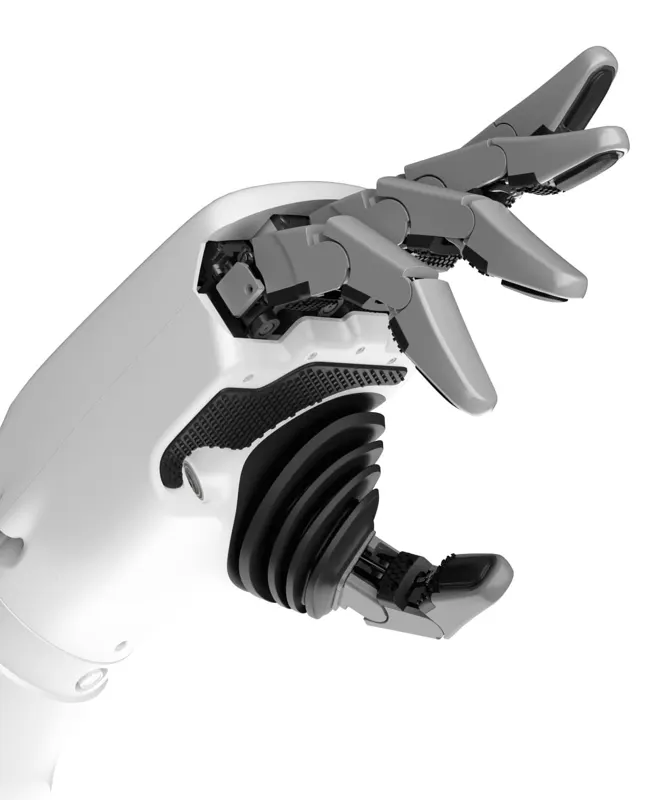
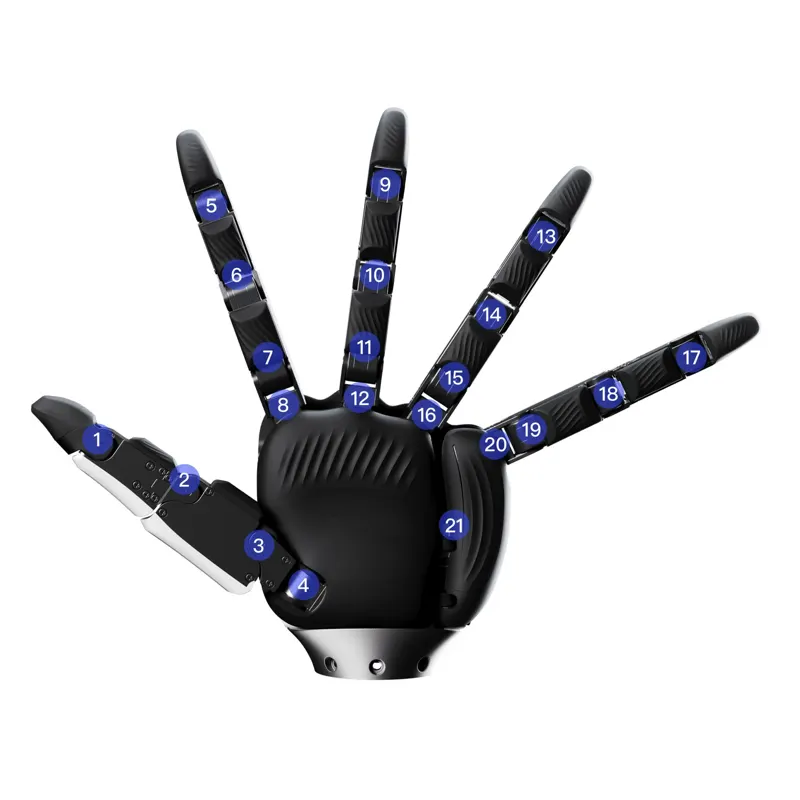
The X-Hand M1 is Yuequan Bionic's rigid bionic dexterous hand: 11 joints with human-like hand size and segment proportions, a bionic palmar arch and ring-shaped oblique-axis design driven by a high power-density motor matrix. Strong and fast: 100 N five-finger grip and 30 N fingertip force, 40 kg whole-hand lift capacity at only 630 g; 0.4 s five-finger close time with ±0.1 mm fingertip repeatability. Sensitive perception via 472 tactile sensing units. Ethernet interface with CAN/RS485 customization; pairs with the X-Bot and W-Bot humanoids.

Typedexterous-hand
Tactile sensing472

Related Components

Yuequan Bionic Y-Hand M1 Bionic Tension-Compression Dexterous Hand

Yuequan Bionic Y-Hand M1 Bionic Tension-Compression Dexterous Hand

The Y-Hand M1 builds on Prof. Lei Ren's pioneering bionic tension-compression body robot theory: it replaces rigid hinges with joints capable of 3D 6-DOF motion, uses magnetic-collection electric-driven artificial muscles replicating human skeletal-muscle biomechanics, and a multi-layer rigid-flexible coupled design. With 38 whole-hand DOF it delivers 330 N grip (28.7 kg whole-hand grasp) and 180 N per-finger output; 0.2 s whole-hand close time; 0.04 mm fingertip positioning accuracy; and 59 mm/N finger compliance for safe, compliant physical interaction combining strength, speed, precision, dexterity and compliance.

Dexterous HandMoon Spring Bio-mimicryY-Hand M1Biomorphic Tensile-Compressive BodySmoothness
X Square ArtiXon Hand Humanoid Five-Finger Dexterous Hand

X Square ArtiXon Hand Humanoid Five-Finger Dexterous Hand

20-DoF / 15-actuator humanoid five-finger hand with 0.1-20 N (+/-0.1 N) fingertip force sensing, tendon drive, <1 s open-close, 3-5 kg payload, <1 kg weight, 1M-cycle life and ROS1/ROS2 SDK.

Dexterous HandTactile SensingTendon RopeX Square
RobotEra XHAND 1 PRO Dexterous Hand

RobotEra XHAND 1 PRO Dexterous Hand

Flagship hand at 0.884 kg with 21 fully direct-driven and back-drivable active DoF, 160 mm maximum grasp diameter and 135° five-finger spread. 18 three-axis tactile sensors (5 fingertip, 10 finger-belly, 3 palm) cover 0.1-25 N at 0.01 N resolution with 10 mm proximity sensing; joint backlash under ±0.25 mm, ±0.1 mm repeatability, over 200k loaded cycles, above 5 Hz open-close and MIT, feedforward force, position and drag-teaching control modes.

Dexterous HandRobotEraXHAND 1 PROFull Direct DriveTactile Sensing
RobotEra XHAND 1 Dexterous Hand

RobotEra XHAND 1 Dexterous Hand

Fully direct-driven five-finger hand from RobotEra at 1100 g with 12 active DoF (thumb and index 3 each, others 2), ±0.20 mm fingertip repeatability, 5 kg+ per finger and 25 kg+ whole-hand lift. A 270° wrap-around tactile array with 120 points per finger at 0.05 N resolution returns three-axis force and temperature; 83 Hz whole-hand control rate, ≤0.1 N·s/m back-drivable damping and one million no-load cycles.

Dexterous HandRobotEraXHAND 1Full Direct DriveTactile Sensing

As an Amazon Associate, we earn from qualifying purchases.