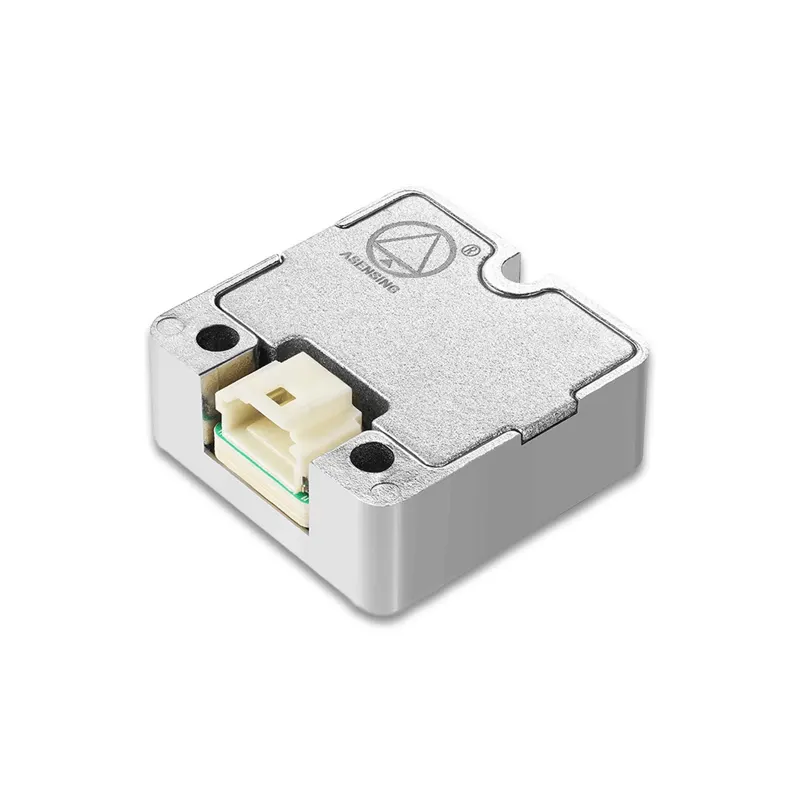
Asensing (Guangzhou) IMU5146 is an automotive-grade high-precision 6-axis IMU: gyro ±500 °/s (±2000 °/s optional) with bias instability ≤1.2 °/h and angular random walk ≤0.14 °/√h; accelerometer ±16 g (±32 g optional) with bias instability ≤0.015 mg; roll/pitch accuracy ≤0.1° and heading accuracy ≤0.2°, with optional ±49 Gauss magnetometer. Measures 22.4×22.4×8.8 mm, weighs 14±1 g, 5 V supply ≤50 mA, UART+PPS output. Asensing is a leading domestic automotive inertial-positioning vendor; the module also fits attitude estimation on robots and robot dogs.
HiPNUC (Beijing) HI14 is a high-precision industrial IMU: gyro ±2000 °/s (±4000 °/s on S* high-range variants) with best S5-grade three-axis bias instability of 0.9/1.1/1.0 °/h; accelerometer ±24 g/±32 g with best bias instability of 0.0045~0.01 mg. IP68-rated housing (M12 version 59×40×20 mm, PG version 40×36×16.5 mm), wide 7~48 V supply, output at UART 1000 Hz / RS485 250 Hz / CAN 200 Hz, RoHS/CE certified — built for harsh environments such as outdoor robots, robot dogs, unmanned boats and industrial mobile platforms.
HiPNUC (Beijing) HI12 is a compact industrial 6-axis IMU for robotics, officially listed on the vendor's humanoid-robot and robot-dog solution pages. Gyro ±2000 °/s with 2.5/3.2/3 °/h three-axis bias instability at H1 grade; accelerometer ±24 g with 0.021~0.032 mg bias instability; static pitch/roll accuracy 0.15~0.2°. UART output at 1000 Hz and CAN at 200 Hz, measuring only 22×22×10 mm with 3.2~5.5 V supply, 240~300 mW power and −40 to +85 °C operation — suited to attitude estimation and motion control on humanoid robots, robot dogs and small mobile platforms.
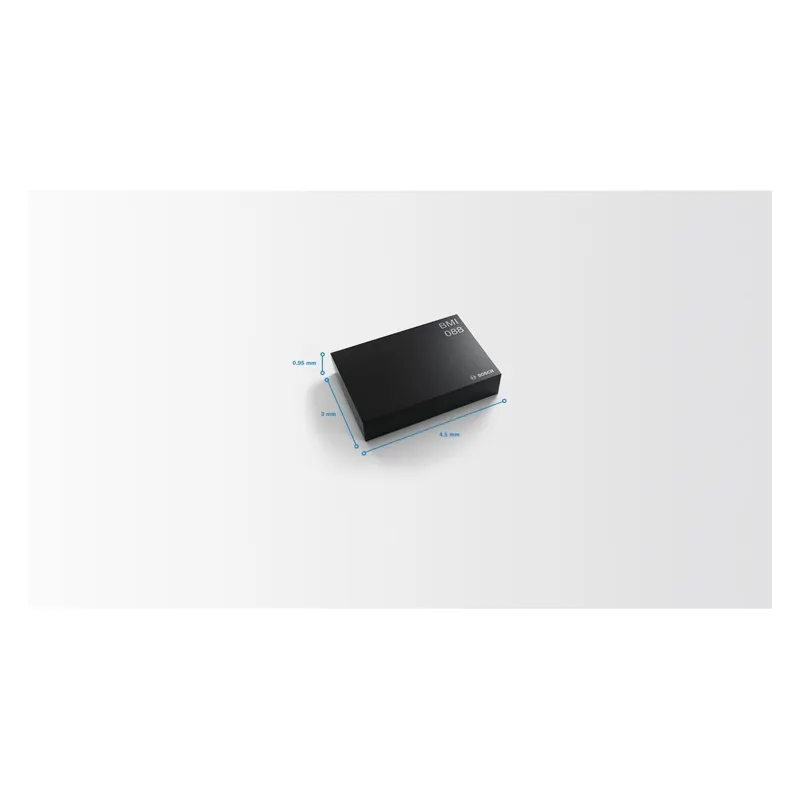
Bosch Sensortec (Germany) BMI088 is a high-performance inertial measurement unit purpose-built for drones and robots, providing highly accurate orientation and motion measurement along three orthogonal axes with excellent temperature stability. Accelerometer range selectable from ±3/±6/±12/±24 g with 16-bit resolution of 0.09 mg, 175 µg/√Hz noise density and programmable 5~523 Hz bandwidth; gyro range ±125 to ±2000 °/s with 16-bit resolution of 0.004 °/s, 0.014 °/s/√Hz noise density and output data rates of 12.5 Hz to 2 kHz. Zero offset (typ. over lifetime) is ±20 mg (accel) and ±1 °/s (gyro) with TCO of ±0.2 mg/K and ±0.015 °/s/K respectively. SPI/I²C interfaces, 2.4~3.6 V supply at 5.15 mA full-operation current, −40 to +85 °C — a classic choice for flight/attitude control on racing drones, robot dogs and humanoid robots.
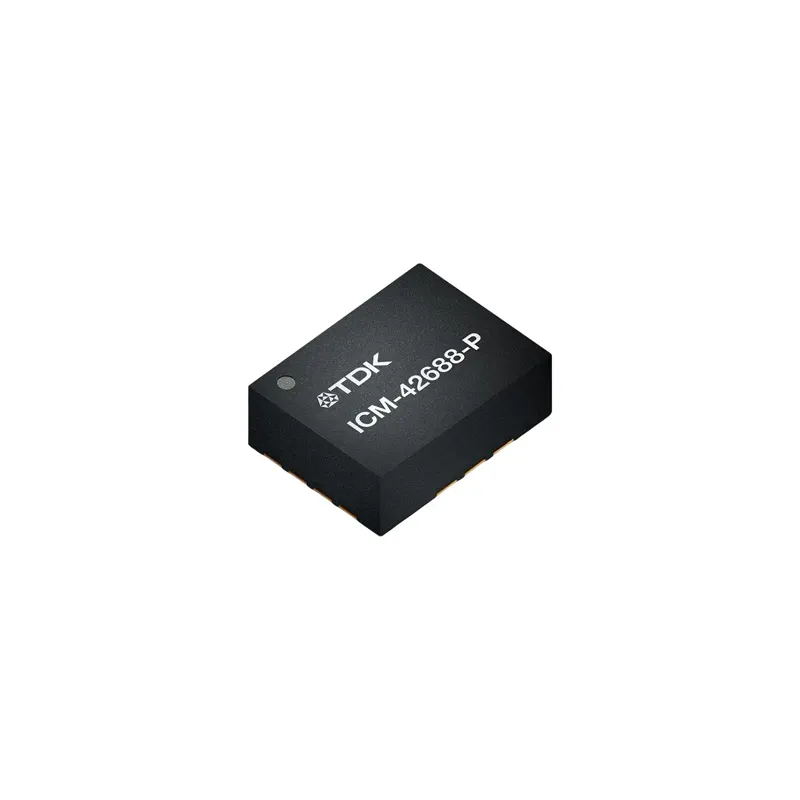
TDK InvenSense ICM-42688-P is the flagship 6-axis SmartIndustrial™ MotionTracking MEMS device for robotics and high-performance IoT, combining a 3-axis gyro and 3-axis accelerometer. Gyro noise is only 2.8 mdps/√Hz and accelerometer noise 70 µg/√Hz, with 6-axis current as low as 0.88 mA in low-noise mode; gyro full scale is selectable from ±15.6 to ±2000 dps and accelerometer from ±2 to ±16 g, with user-programmable digital filters. Host interfaces include 12.5 MHz I3C, 1 MHz I²C and 24 MHz SPI in a thin 2.5 × 3 × 0.76 mm 14-pin LGA package with drop-in 6-axis footprint compatibility. Officially targeted at AR/VR/XR, robotics and high-performance IoT, it is one of the most widely used consumer/industrial IMUs for joint and body attitude sensing on humanoid robots and robot dogs.
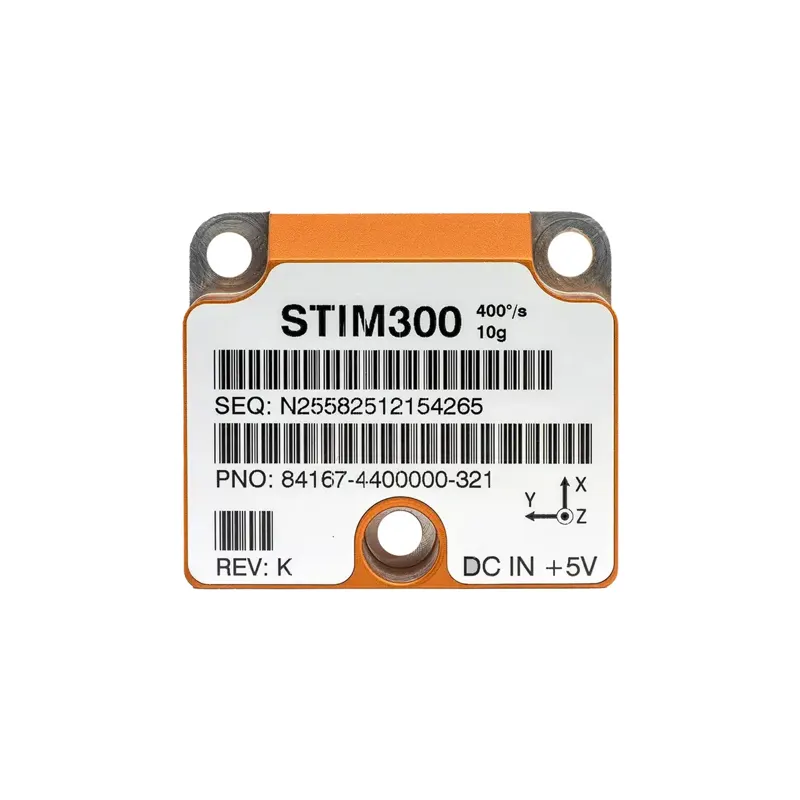
Safran Navigation & Timing (formerly Sensonor, Norway) STIM300 is a small, lightweight, high-performance non-GPS-aided tactical-grade MEMS IMU containing 3 highly accurate MEMS gyros, 3 high-stability accelerometers and 3 inclinometers, factory calibrated and temperature compensated. Gyro full scale ±400 °/s (output capped at ±480 °/s) with 262 Hz bandwidth and up to 2000 samples/s; 0.3 °/h bias instability and 0.15 °/√h angular random walk (Allan variance, 25 °C), 3 °/h drift-rate stability over temperature; the ±10 g accelerometer shows 0.04 mg bias instability and 0.07 m/s/√h velocity random walk; axis misalignment is just 1 mrad. Single +5 V supply at 1.5~2 W, RS422 interface, 55 g mass, ITAR-free — a cost-effective FOG-class alternative for precision navigation on humanoid robots, robot dogs, unmanned systems and stabilization platforms.
Analog Devices (USA) ADIS16501 is a precision miniature MEMS IMU: triaxial digital gyroscope with ±500 °/s range, 2.7 °/h in-run bias stability, 0.15 °/√hr angular random walk (x/y, 1σ) and ±0.25° axis-to-axis misalignment; triaxial digital accelerometer with ±14 g range and 12.7 µg in-run bias stability (x/y). Each sensor is factory calibrated for sensitivity, bias, alignment, linear acceleration (gyro bias) and point of percussion; the SPI interface and register structure simplify integration with automatic/manual bias correction. It survives 1500 g mechanical shock, operates from −40 to +105 °C in a 100-ball BGA module, and ships with official Linux driver, ROS2 driver and PyADI-IIO support — a mainstream choice for humanoid robots, robot dogs and industrial mobile platforms.
Analog Devices (USA) ADIS16505 is the iSensor precision miniature MEMS IMU, offered with ±125/±500/±2000 °/s gyro range models (ADIS16505-1/2/3). The ADIS16505-1 achieves 2.3 °/h in-run bias stability, 0.13 °/√hr angular random walk (x/y axes, 1σ) and ±0.25° axis-to-axis misalignment; the triaxial digital accelerometer spans ±78.4 m/s² (±8 g). All axes are factory calibrated for sensitivity, bias and alignment over −40 to +85 °C; SPI interface with automatic/manual bias correction, −40 to +105 °C operation in an ~15 × 15 × 5 mm 100-ball BGA package. A common core sensor for high-accuracy attitude estimation, SLAM and control on humanoid robots, robot dogs and autonomous platforms.
Analog Devices (USA) ADIS16470 is the iSensor wide-dynamic-range miniature MEMS IMU, integrating triaxial digital gyroscope and accelerometer with signal conditioning in an ~11 × 15 × 11 mm 44-ball BGA module. Gyro full range ±2000 °/s with 8 °/h in-run bias stability and 0.008 °/s/√Hz rate noise density; accelerometer ±40 g range. Every axis is factory calibrated for sensitivity, bias and alignment (calibration range −10 to +75 °C); SPI interface with automatic/manual bias correction, −25 to +85 °C operation. With its high dynamics and low drift, the ADIS16470 is widely used for SLAM, attitude estimation and stabilization on humanoid robots, robot dogs, drones and mobile platforms.
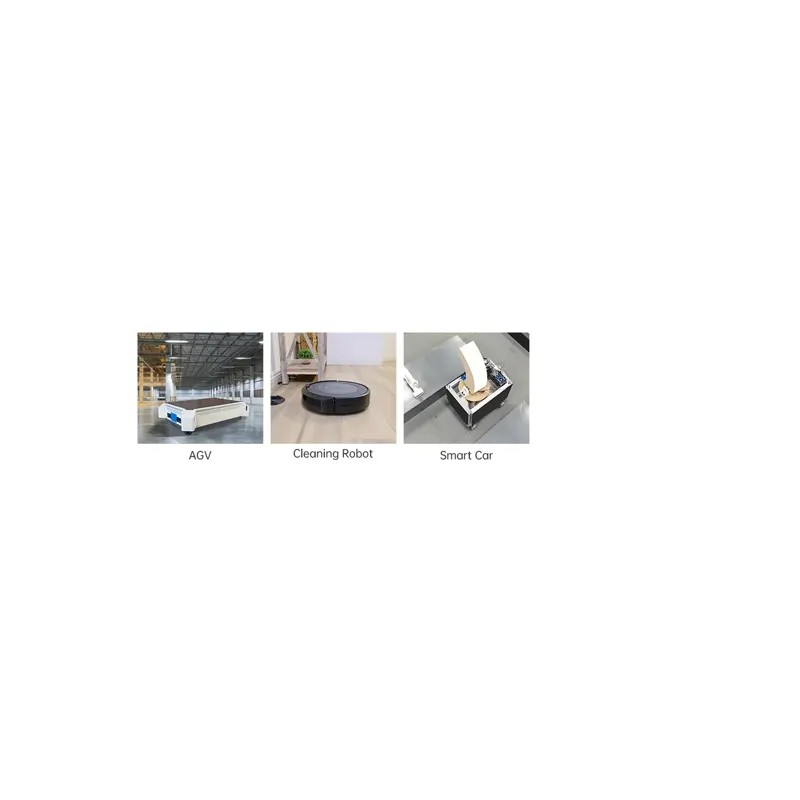
Wit Motion (Shenzhen) WT61 is a cost-effective 3-D attitude measurement system based on MEMS technology, integrating a 3-axis gyroscope and 3-axis accelerometer. Its proprietary Kalman-filter sensor-fusion algorithm outputs temperature-compensated 3-axis attitude angles at up to 100 Hz in real time. Accelerometer ±16 g range with 0.0005 g/LSB resolution and 0.75~1 mg RMS noise at 100 Hz bandwidth; gyro ±2000 °/s with 0.05 °/s RMS noise; 0.2° roll/pitch accuracy and 0.5° static heading accuracy (6-axis algorithm). The module ships with a metal shield case for good EMI immunity and easy mounting, making it one of the most popular entry-level IMUs for humanoid robots, robot dogs, AGVs, gimbals and education.
Wit Motion (Shenzhen) WT901 is its classic 9-axis attitude module combining a 3-axis accelerometer, 3-axis gyro and 3-axis magnetometer, using MEMS sensing with proprietary Kalman-filter sensor fusion to output angles, rates, acceleration, magnetic field and quaternions at up to 200 Hz. Accelerometer ±16 g range with 0.0005 g/LSB resolution and 0.75~1 mg RMS noise at 100 Hz bandwidth; gyro ±2000 °/s with 2.24 °/h bias instability (Allan variance) and 3.19 °/h zero-bias stability; 0.2° tilt accuracy and 0.1° heading accuracy without magnetic interference; default UART 115200 bps, -40 to +85 °C operation. Compact and affordable, it is widely used for attitude estimation and motion control in humanoid robots, robot dogs, drones and research.
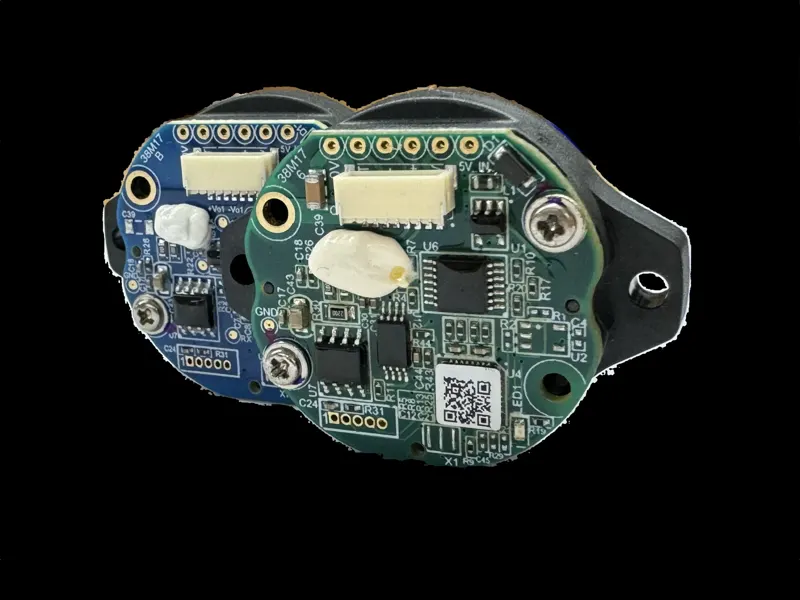
M17M standard 17-bit split magnetic-electric absolute encoders: 17-bit single-turn, 16-bit multi-turn, 5 V, RS485 at 2.5 Mbps. Strong vibration/shock/contamination resistance for reliable servo feedback in automation, robotics and logistics.