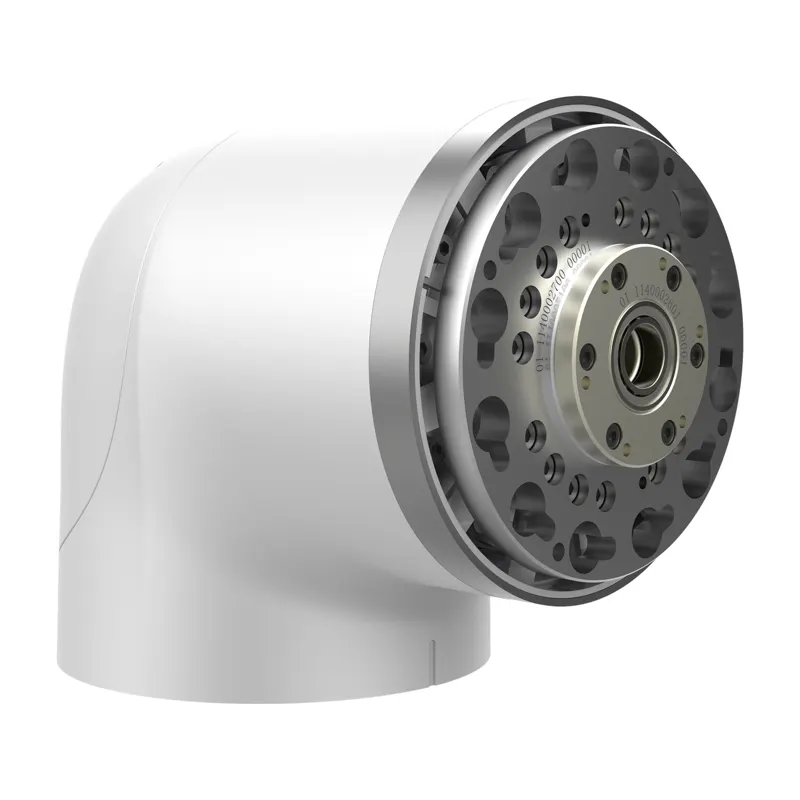
ESTUN Codroid (embodied-AI arm of ESTUN) SA-series rigid joint module SA17: rated torque 31 N·m, start/stop max 70 N·m, instantaneous peak 143 N·m, rated speed 34.6 RPM. Integrates driver, dual encoders, harmonic reducer, torque sensor, motor and electromagnetic brake in one unit; ratio 101, 11mm hollow shaft, dual 19-bit absolute magnetic encoders, EtherCAT/CiA402, 48VDC, IP54, ±0.01° positioning. Built for collaborative and humanoid robots, suited for small-to-medium joints.
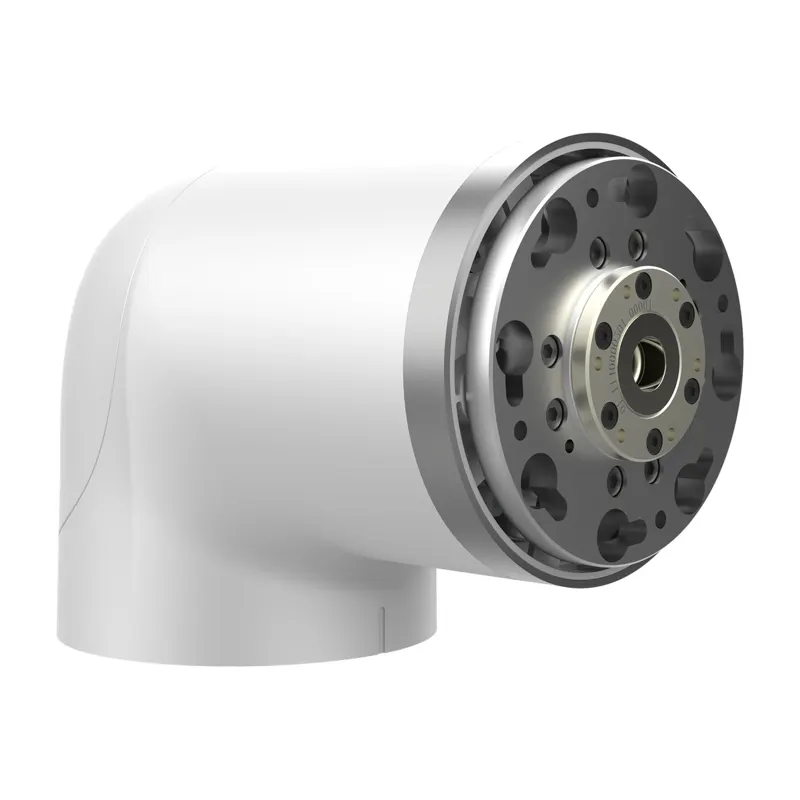
ESTUN Codroid (embodied-AI arm of ESTUN) SA-series rigid joint module SA14: rated torque 10 N·m, start/stop max 36 N·m, instantaneous peak 70 N·m, rated speed 49.5 RPM. Integrates driver, dual encoders, harmonic reducer, torque sensor, motor and electromagnetic brake in one unit; ratio 101, 8mm hollow shaft, dual 19-bit absolute magnetic encoders, EtherCAT/CiA402, 48VDC, IP54, ±0.01° positioning. Built for collaborative and humanoid robots, suited for small joints (wrist/ankle).
EYOBOT PP dedicated planetary joint module: φ52×67.6mm, 390g, ratio 36, rated 6.6 N·m / peak 10 N·m, 50rpm rated speed, 60W max power. Brushless torque motor, dual-absolute 16-bit encoders, CANopen, 24-42V, IP54, back-drive backlash ≤15 arcmin. For wrists, ankles and large dexterous-hand joints of humanoid robots.
Micro version of EYOBOT's PP dedicated planetary series: φ32×34.2mm, only 86g, ratio 6, rated 0.2 N·m / peak 0.48 N·m, 50rpm rated speed. Brushless torque motor, dual-absolute 16-bit encoders, CANopen, 24-42V, IP54, back-drive backlash ≤15 arcmin. Ultra-compact integrated joint for dexterous-hand finger joints of humanoid robots.
High-torque version of EYOBOT's RP humanoid planetary series: φ96.5×56mm, only 1075g, 8mm hollow shaft, ratio 21.91, rated 35 N·m / peak 120 N·m, 115rpm rated speed, 421W rated power. Inductive absolute encoders (17-bit input / 19-bit output), CANopen (CAN FD customizable), 48V, backlash ≤12 arcmin, >3000h life. High torque density for lower-limb joints of humanoid robots.
EYOBOT RP humanoid planetary joint module: φ77×58.3mm, 760g, 6mm hollow shaft, ratio 20, rated 17 N·m / peak 60 N·m, 125rpm rated speed. Inductive absolute encoders (17-bit input / 19-bit output), CANopen (CAN FD customizable), 48V, backlash ≤12 arcmin, >3000h life. For arm, shoulder and elbow joints of humanoid robots.
Micro version of EYOBOT's RP humanoid planetary joint series: φ45×52mm, only 215g, 4mm hollow shaft, ratio 25, rated 2 N·m / peak 6 N·m, 120rpm rated speed. Inductive absolute encoders (17-bit input / 19-bit output), CANopen (CAN FD customizable), 48V, backlash ≤12 arcmin, >3000h life. For finger and wrist joints of humanoid robots.
EYOBOT PHA lightweight harmonic joint module: φ80×68mm, only 900g, 10.8mm hollow shaft, ratio 101, rated torque at 2000rpm 30 N·m, peak 66 N·m, instantaneous max 134 N·m, backlash ≤15 arcsec. Dual-absolute 16-bit encoders, CANopen, 48V, >10000h life. Significant weight reduction at this torque class, ideal for upper-limb joints of humanoid robots.
EYOBOT PHA lightweight harmonic joint module: φ43×48.3mm, only 207g, 4.4mm hollow shaft, ratio 101, peak torque 3.3 N·m, instantaneous max 6.3 N·m, backlash ≤15 arcsec. Dual-absolute 16-bit encoders, CANopen, 24-36V, >10000h life. Weight-optimized for end-effectors and dexterous-hand joints of humanoid robots.
High-torque version of EYOBOT's RHU humanoid harmonic series: φ130 class, 6150g (B) / 5820g (N), ratio 120/160, rated torque at 2000rpm 248/363 N·m, peak 648/800 N·m, instantaneous max 1458 N·m. Dual-absolute 19-bit encoders, EtherCAT/CANopen, 24-48V, >10000h life. The workhorse for heavy-load waist/hip joints of humanoid robots.
EYOBOT RHU humanoid-dedicated harmonic joint module: φ120×126mm, 4360g (B) / 4080g (N), 22mm hollow shaft, ratio 120/160, rated torque at 2000rpm 124/169 N·m, peak 270/459 N·m, instantaneous max 848 N·m. Dual-absolute 19-bit encoders, EtherCAT/CANopen, 24-48V, >10000h life. Suits hip and knee joints of humanoid robots.
EYOBOT RHU humanoid-dedicated harmonic joint module: φ52×61.1mm, 397g (B) / 382g (N), 8mm hollow shaft, ratio 50/80/100, peak torque 12/16/19 N·m, instantaneous max 24/35/35 N·m. Dual-absolute 19-bit encoders, EtherCAT/CANopen, 24-48V, optional brake, >10000h life. Optimized for small upper-limb joints of humanoid robots.