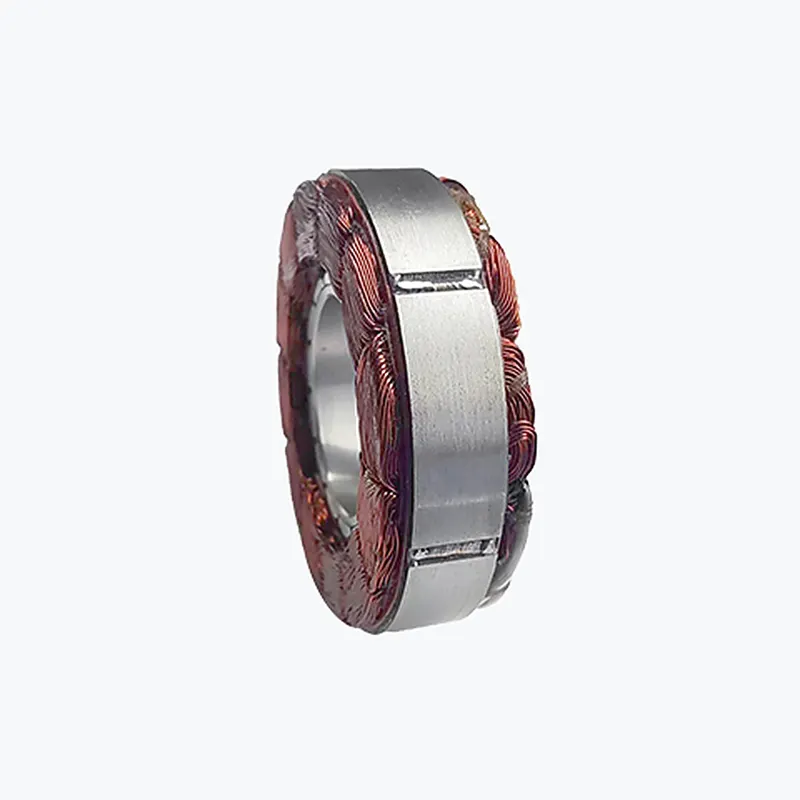
Haozhi frameless torque motor for direct-drive collaborative-robot joints; globally optimized electromagnetic design with rare-earth PM, non-oriented cold-rolled silicon steel, corona-resistant magnet wire and Class-H insulation plus innovative winding and EM packaging for high torque density, ≤1% torque ripple, fast dynamic response, low temperature rise and light weight; 3.5x overload, turn-on voltage <24 V and holding voltage <7 V for lower heating, stable output across wide speed and load ranges.
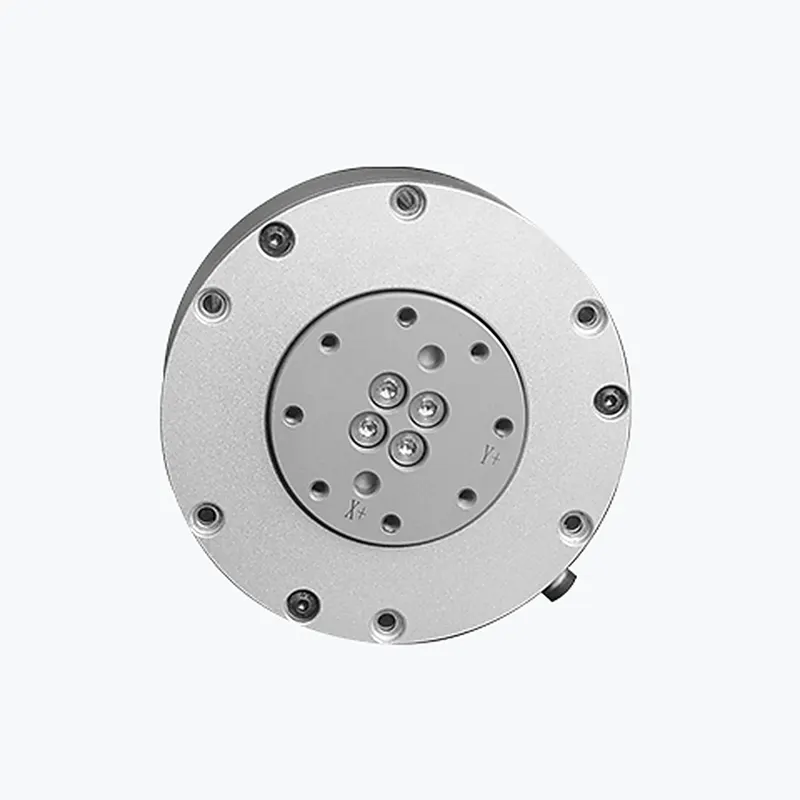
Haozhi DSA series 6-axis force/torque sensors for collaborative-robot force control, five ranges spanning Fxy/Fz 100-1600 N and Mxy/Mz 3-50 Nm; world-class force-control accuracy ≤0.1 Nm with temperature self-compensation, low zero drift/creep and structural decoupling; 18/24-bit A/D at 1 kHz sampling with Kalman + Butterworth dual filtering for smoother output; 6-channel analog input with low-noise instrumentation amplifiers; nonlinearity/hysteresis 0.5 %F.S, crosstalk 2 %F.S, overload ≥300% (≥500% for DSA-16050), IP64, 12-24 V, EtherCAT/RS485/CAN/Ethernet interfaces.
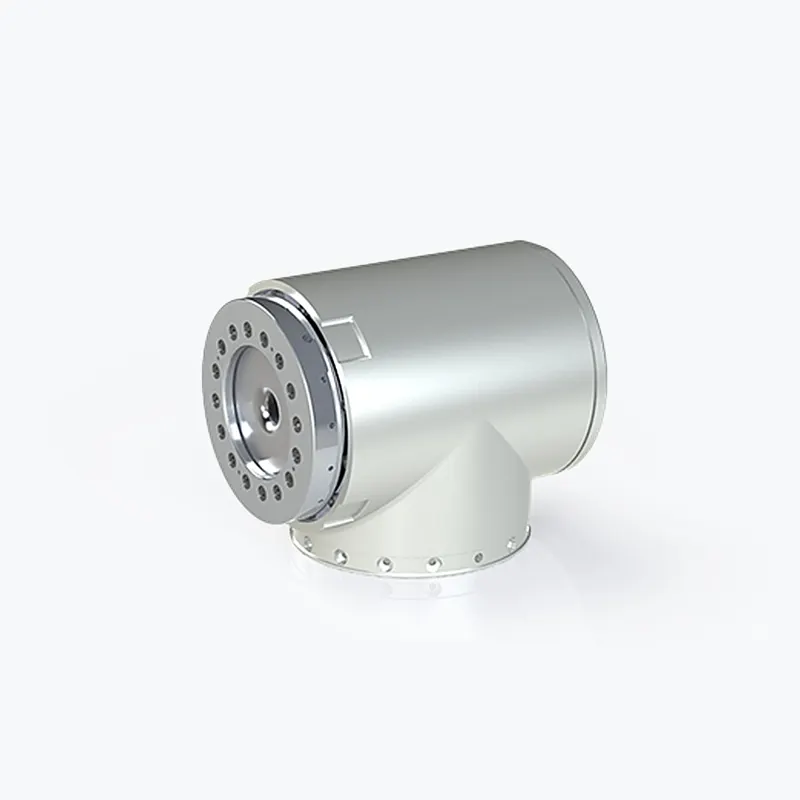
Haozhi integrated robot joint module in six sizes (14-40), combining a frameless torque motor, high-stiffness harmonic reducer, dual absolute multi-turn 18-bit BISS-C encoder and large-hollow low-voltage drive; ratios 50-160, peak torque 23-841 N.m with 3.5x overload, positioning <0.015° and repeatability 0.003°, EtherCAT/CANopen daisy-chain, 48 V supply with 24 V STO/SBC safety, friction brake, 12/18 mm through-bore, torsional stiffness 1.1-41 Nm/arc-min; for collaborative and humanoid robot arms.
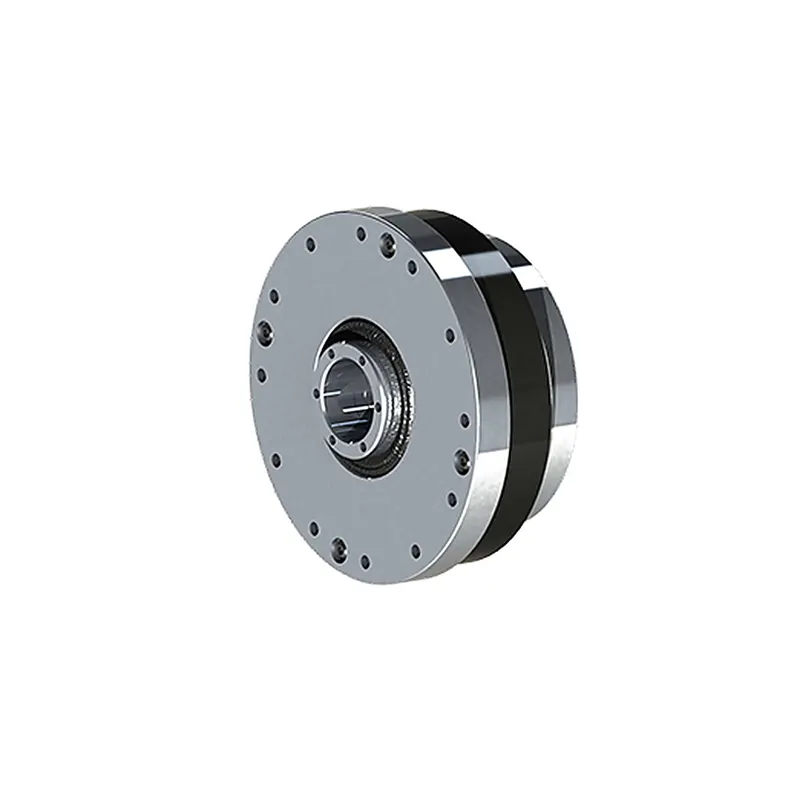
Haozhi DHSG-H standard hat-type harmonic (strain-wave) reducer, sizes 14-32 (plus 40/45), ratios 50/80/100/120, hollow input for center wiring; rated torque 5.4-137 N.m, transmission accuracy ≤75″ (14-17) / ≤50″ (20-32) standard and ≤50″ / ≤25″ special, 5 arc-sec repeatability, L10 ≥10,000 h / L50 ≥50,000 h life; proprietary SP tooth profile with ≥30% mesh engagement and +10% stiffness over industry standard, custom low-noise lubricant, 50% fewer parts and 1/3 less volume/weight; for light-payload 6-axis robots and press manipulators.
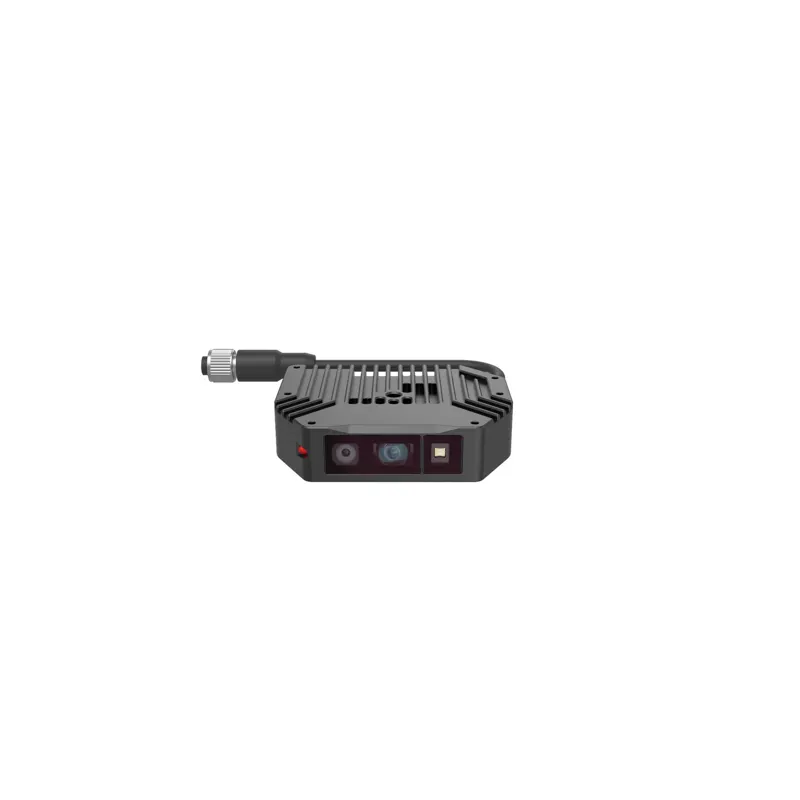
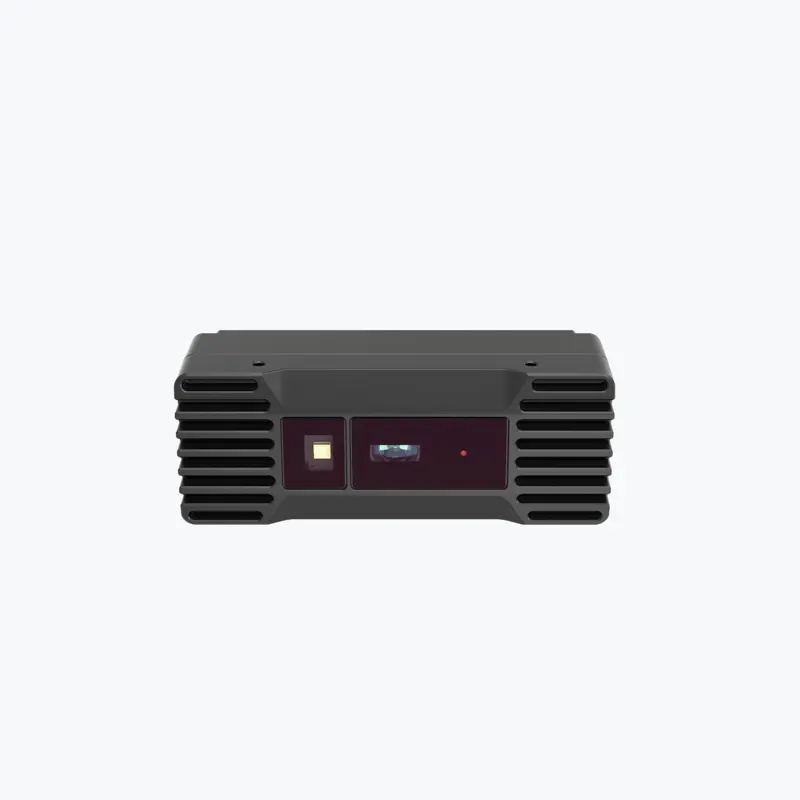
Percipio TM265-E1 3D dToF RGB-D camera: 940 nm IR laser, 120°/50° ultra-wide FOV, 0.05-5 m range, 240x96 @25 fps depth plus 1920x1080 @30 fps color with RGB-D alignment, Z accuracy 6 mm @1 m, 76 ms latency, 100 Mbps Ethernet over M12 connector, IP65, 85x68x20 mm / 174 g, <5 W; millimeter-level depth accuracy and strong-light resistance for mobile-robot navigation, obstacle avoidance and traffic counting.
Percipio TM262-E1 industrial dToF ranging depth camera: 940 nm IR laser, 120°/50° ultra-wide FOV, 0.05-8 m working range, up to 240x96 @25 fps depth, Z accuracy 6 mm @1 m / 15 mm @2.5 m, 55 ms latency, 100 Mbps Ethernet over M12 aviation connector, IP65, aluminum passive cooling, 90x34x30 mm / 130 g, <4 W, DC 24V, Linux/Windows/ROS with Vcamera/Camport4 SDK; sunlight-resistant for indoor/outdoor AMR navigation, obstacle avoidance and ranging.
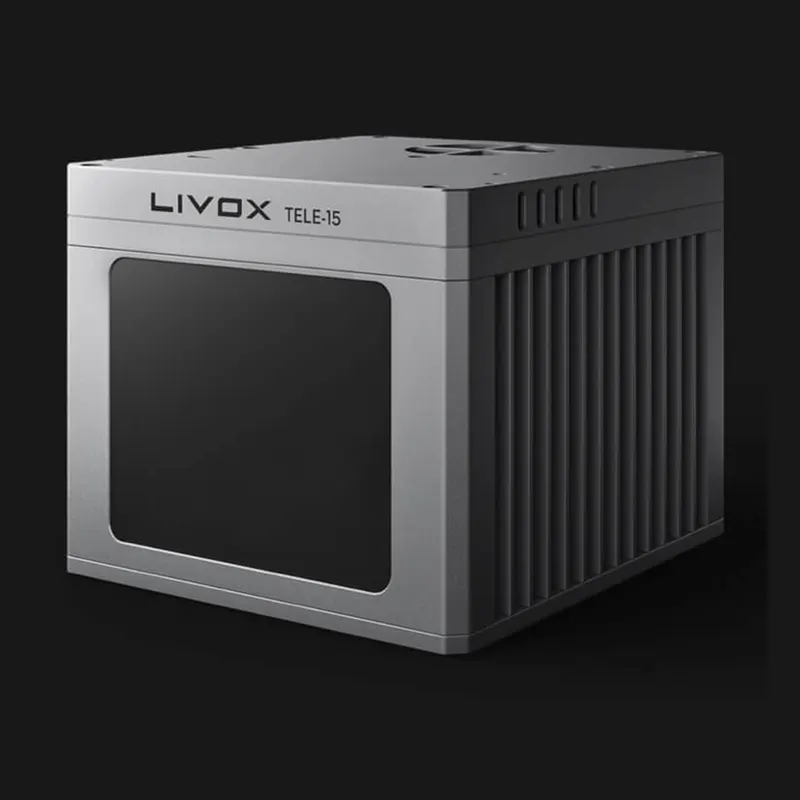
Livox Tele-15 long-range hybrid solid-state LiDAR: 320 m @10% / 500 m @50% reflectivity range, 14.5°×16.2° FOV with 99.8% coverage in 0.1 s, 2 cm @20 m precision, <0.03° angular precision, 240k/480k (dual return) pts/s, ≤2 ms latency, built-in BMI088 IMU, IP67, -40 to 85°C operating range, 12 W typical; for high-speed platforms and long-range inspection perception.
Livox Avia 2 long-range hybrid solid-state LiDAR with a 1535 nm eye-safe laser: normal mode 400 m @5% reflectivity with 80°×80° FOV; focus mode ≥800 m @10% (max 1000 m) with 15°×15° FOV; ≤5 cm range accuracy, ≤0.02° angular precision, 350k/100k pts/s, IP66, 50 W steady-state, 9-27 V DC, ≤1.8 kg; for long-range, high-precision perception and fixed-point observation.
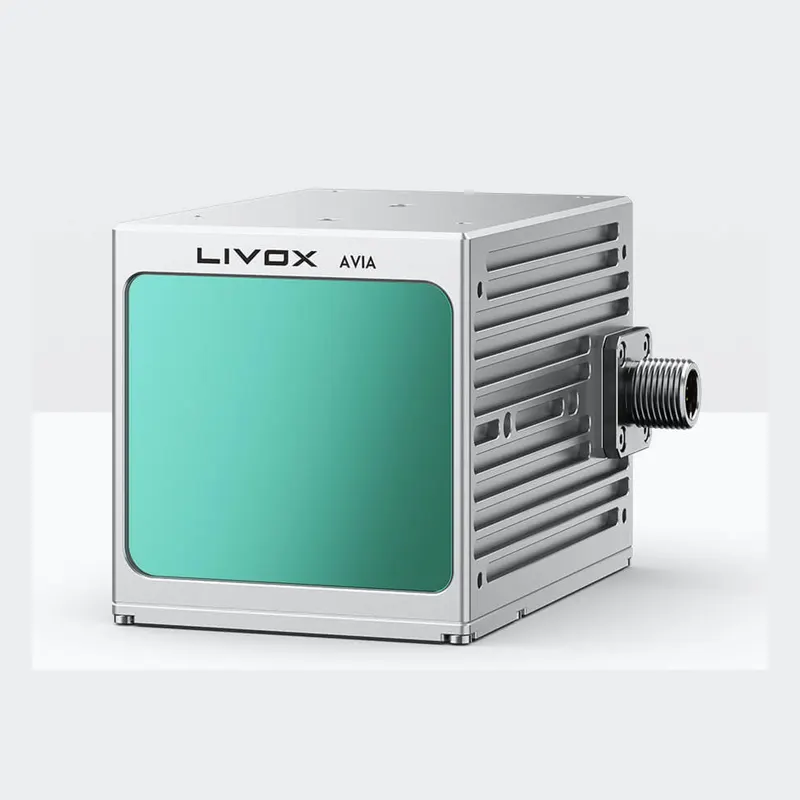
Livox Avia non-repetitive scanning hybrid solid-state LiDAR: 190 m @10% reflectivity (100 klx) and 450 m @80% (0 klx) range, 70.4°×77.2° FOV, 2 cm @20 m precision, <0.05° angular precision, up to 720k pts/s (triple return), ≤2 ms latency, built-in BMI088 IMU, IP67, 8-9 W, 91×61.2×64.8 mm / 498 g; balances long range with high precision for mapping, inspection and autonomous driving.
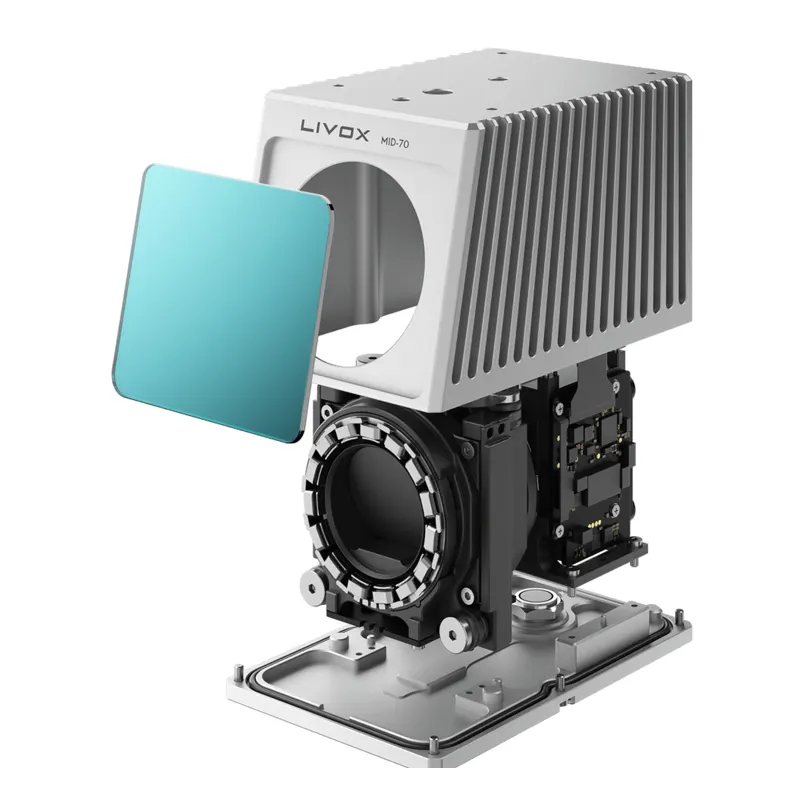
Livox Mid-70 non-repetitive scanning hybrid solid-state LiDAR: 70.4° circular FOV, 90 m @10% / 130 m @20% / 260 m @80% reflectivity range, ≤2 cm @20 m precision, <0.1° angular precision, 100k (single) / 200k (dual return) pts/s, ≤2 ms latency, IP67, 8 W average, 97×64×62.7 mm / 580 g, -20 to 65°C; angular resolution improves with integration time, suited to mid-range 3D perception on autonomous and inspection vehicles.
Livox Mid-360S, the cost-optimized next-generation 360° hybrid solid-state LiDAR for mobile robots: same 65×65×60 mm / 265 g form factor as Mid-360, 905 nm Class 1, 360° H x (-7° to 52°) V FOV, range upgraded from 40-70 m to 38-100 m @10% reflectivity at WRC 2026, with sharper mapping edges, 0.1 m blind zone, ≤2 cm @10 m / ≤4 cm @0.2 m precision, <0.15° angular precision, 200k pts/s, IP67, 6.5 W, built-in ICM40609 IMU and active anti-interference; for indoor/outdoor service robots, autonomous forklifts and inspection platforms.
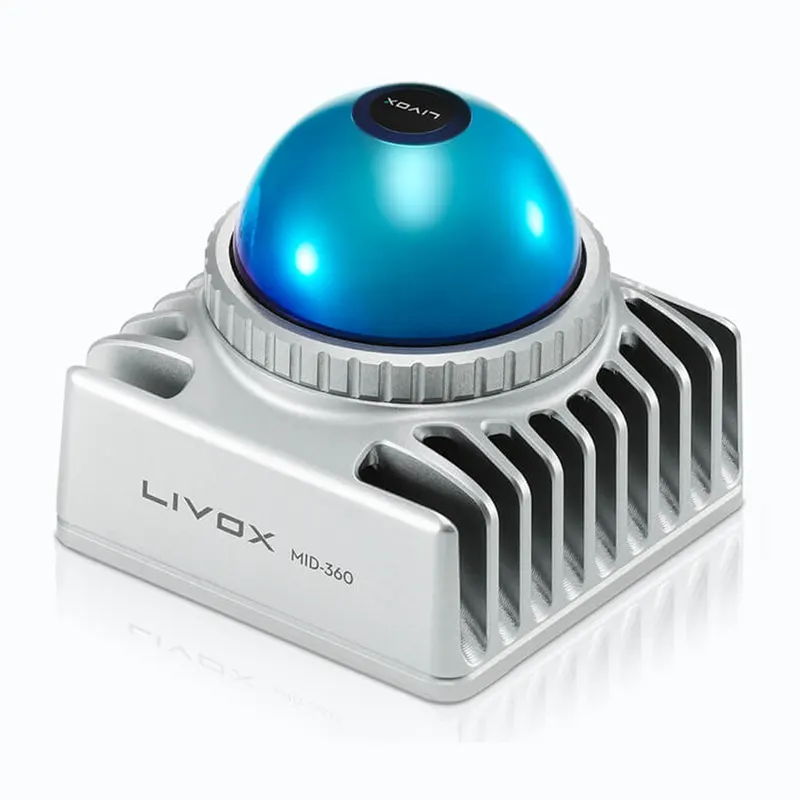
Livox Mid-360 hybrid solid-state 3D LiDAR for omnidirectional robot perception: 905 nm Class 1 laser, 360° H x (-7° to 52°) V FOV, 40 m @10% / 70 m @80% reflectivity range (100 klx), 0.1 m blind zone, ≤2 cm range precision @10 m, <0.15° angular precision, 200k pts/s @10 Hz, built-in ICM40609 IMU, IP67, 6.5 W, 9-27 V DC, 65×65×60 mm / 265 g; widely used for navigation and obstacle avoidance on AGVs, inspection and service robots.