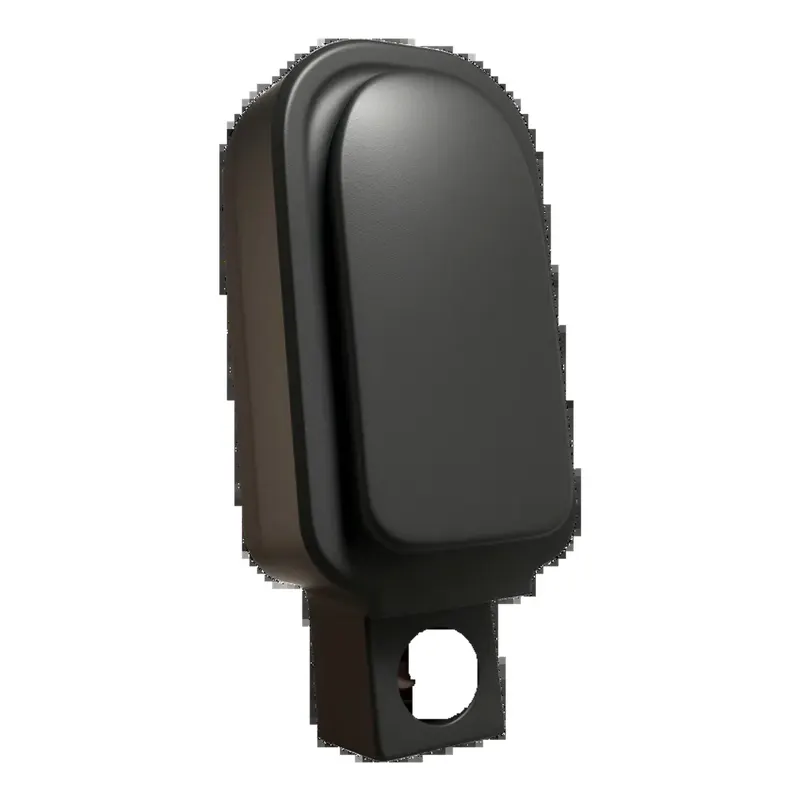
Tashan Tech TS-F-A general-purpose tactile fingertip with integrated 3-axis force tactile sensing and proximity sensing (independent sensing unit): 0.01 N normal-force resolution, 0.25 N tangential-force resolution, 2-10 cm proximity range, 1000 N safe overload, 3M-cycle life, on-board R-SpiNNaker neuromorphic chip recognizing 30+ materials, I2C interface; for humanoid dexterous-hand grasping and tactile perception.
Hanwei (Winsensor) stretch strain sensor ESSA-01/ESSB-01, 0.36/1 mm thick, 0-50% stretch range, 0.05% resolution, 99.9% linearity, >150k/300k cycles, 10-60 C, machine-washable >30/60 times; for flexible deformation and joint bending monitoring.
Hanwei (Winsensor) pressure-strain sensor ESPB-01/B1, 2.3/2 mm thick, range 0-850 N / 0-1800 N, resolution 0.5/1.5 N, >300k cycles, 10-60 C, machine-washable; for large-range flexible force measurement.
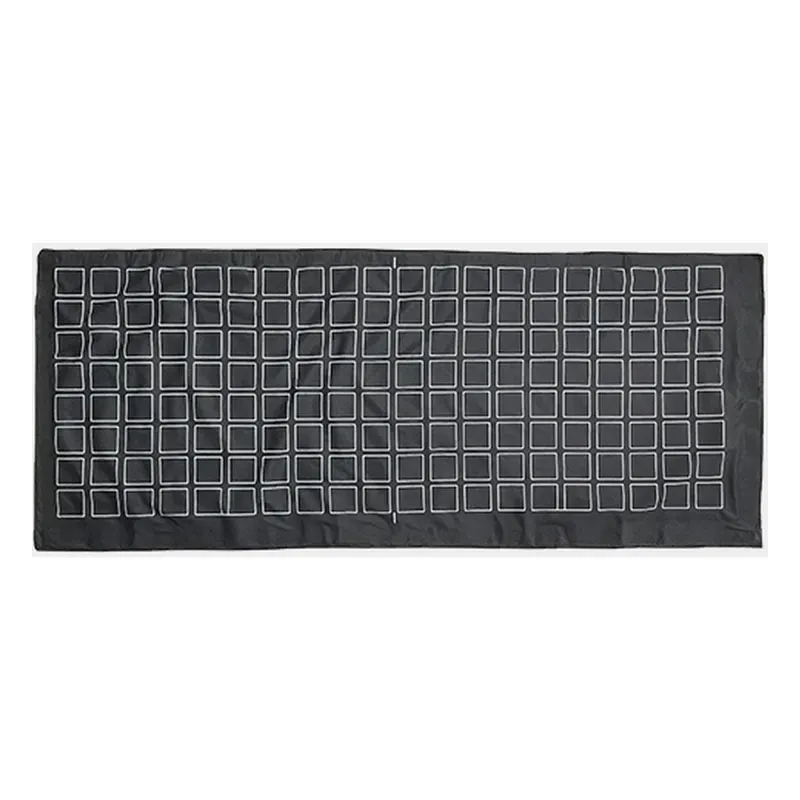
Hanwei (Winsensor) flexible pressure array sensor on fabric/TPU substrate, freely bendable; range 5-50 N, accuracy ±15%, 50 Hz refresh, 100 ms response, 0-40 C; for robot tactile skin and pressure distribution mapping.
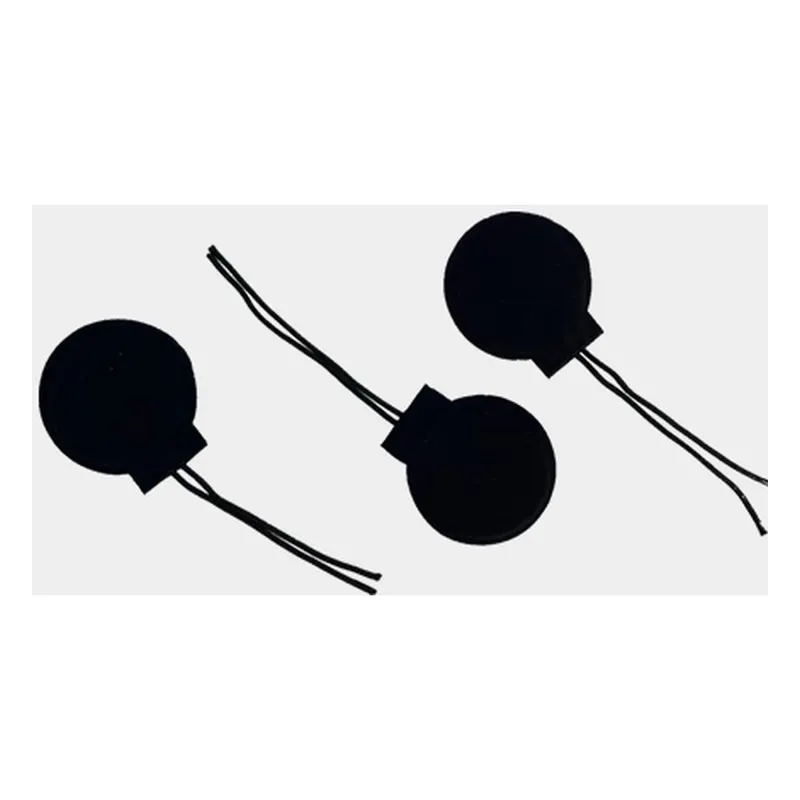
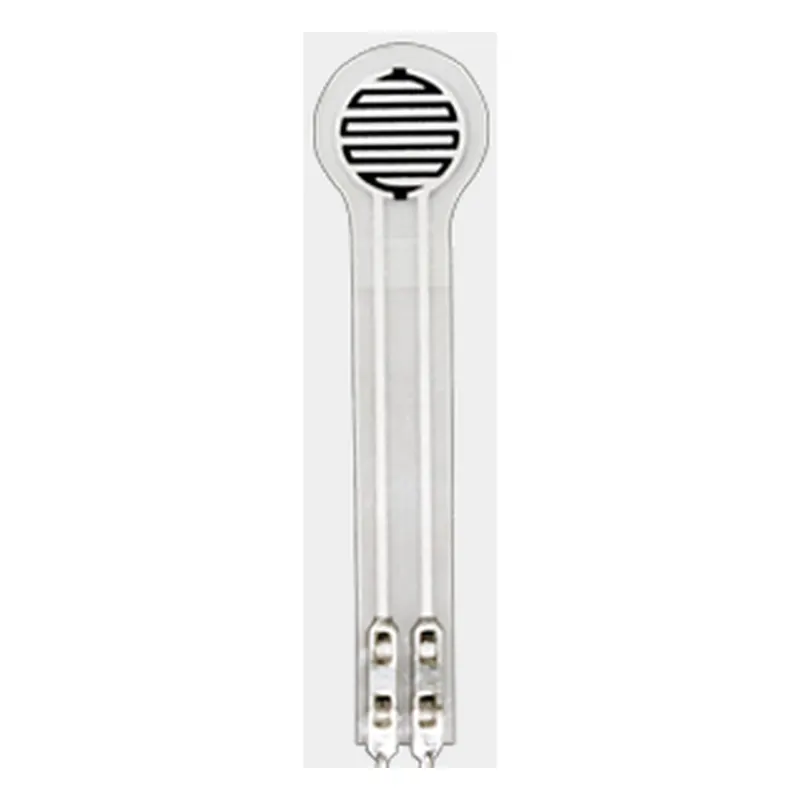
Hanwei (Winsensor) DF9 resistive flexible thin-film force sensor, <0.3 mm thick, ranges 0-500 g to 0-20 kg (DF9-40/DF9-16), accuracy ±2.5%, response <1 ms, recovery <15 ms, >1M cycles life, >10 MOhm initial resistance, 3.3 VDC, -20 to 60 C; for robot grip force, foot pressure and contact sensing.
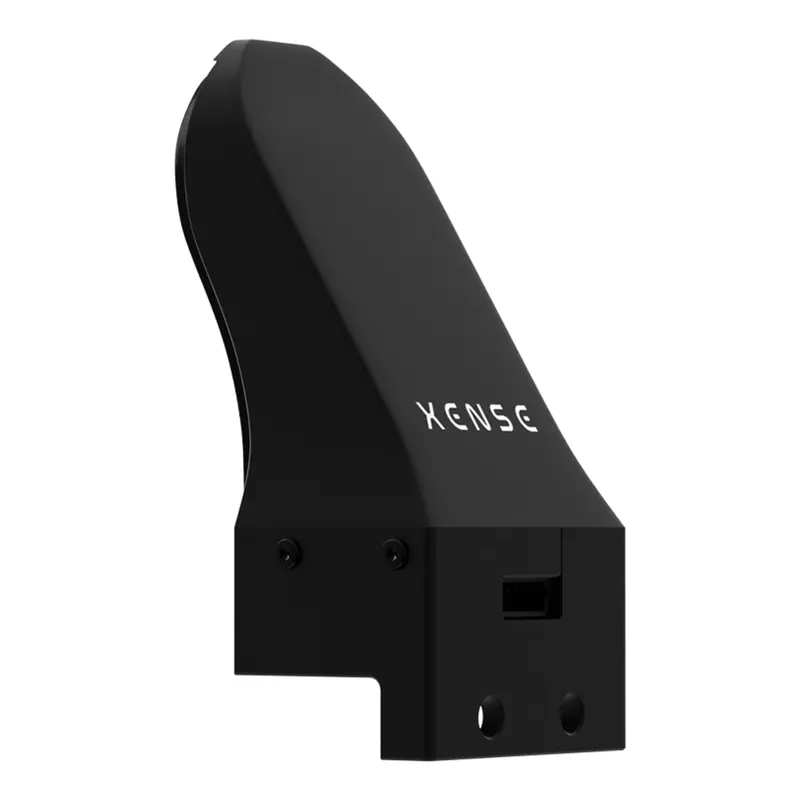
Xense Elf fingertip optical tactile sensor: 15x18 mm sensing area, 22.2x15.4x14.2 mm body, 125 markers/cm2, 0.04 mm spatial resolution, 30-150 Hz, UVC, 0.3 W; deformation 0.08 mm, force 0.03 N; six modalities, designed for dexterous-hand fingertips.
Xense Photon wedge-type optical tactile sensor: 17.5x29.5 mm sensing area, 52.8x27x22 mm body, 120 markers/cm2, 0.03 mm spatial resolution, 30-150 Hz, UVC, 0.6 W; deformation 0.06 mm, force 0.02 N; six modalities for compact gripper integration.
Xense Quark W1 optical tactile sensor: 25x35 mm sensing area, 61.5x60x27 mm body, 100 markers/cm2, 0.03 mm spatial resolution, 30-150 Hz, UVC, 5 V, 1 W; deformation 0.06 mm, force 0.02 N; six sensing modalities for larger gripper contact surfaces.
Xense Quark N1 optical vision-based tactile sensor: 18x33 mm sensing area, 0.03 mm spatial resolution, 100 markers/cm2, 2-5 mm flexible layer, 30-150 Hz sampling, UVC, 5 V, 0.6 W; deformation accuracy 0.06 mm, force accuracy 0.02 N; modalities: 3D topography, texture, 6-axis force, distributed force, slip, motion tracking.
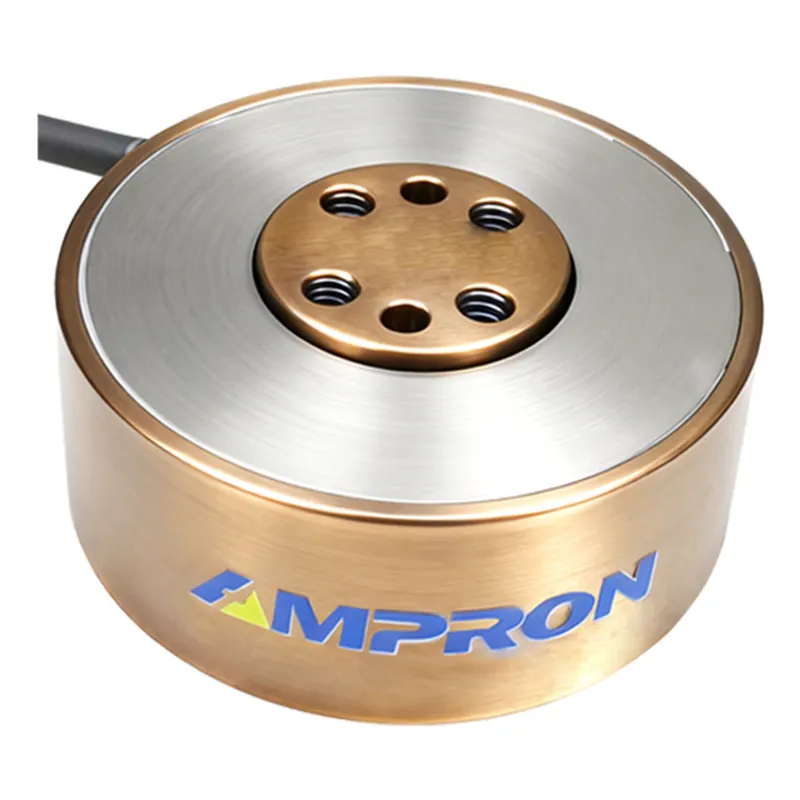
Ampron FSM6-E50 low-profile stainless 6-axis F/T sensor, Ø50x19.5 mm; non-linearity ±0.2% F.S., 1/1000 resolution, repeatability ±0.1% F.S., crosstalk ±2% F.S.; ranges Fx/Fy 100-500 N, Fz 100-700 N, M 4-18 N·m; 1000 Hz, RS485/CAN/EtherCAT, IP65, -30~80°C, 500% F.S. safe overload; ultra-thin for dexterous hands and humanoid wrists.
Ampron FSM6G-D75 stainless-steel 6-axis F/T sensor, Ø75x42.5 mm; non-linearity ±0.2% F.S., 1/1000 resolution, repeatability ±0.1% F.S., crosstalk ±2% F.S.; ranges Fx/Fy 100-500 N, Fz 100-700 N, M 4-18 N·m; 1000 Hz, RS485/CAN/EtherCAT, IP65, -30~80°C, 500% F.S. safe overload; for high-protection and medical/food-grade use.
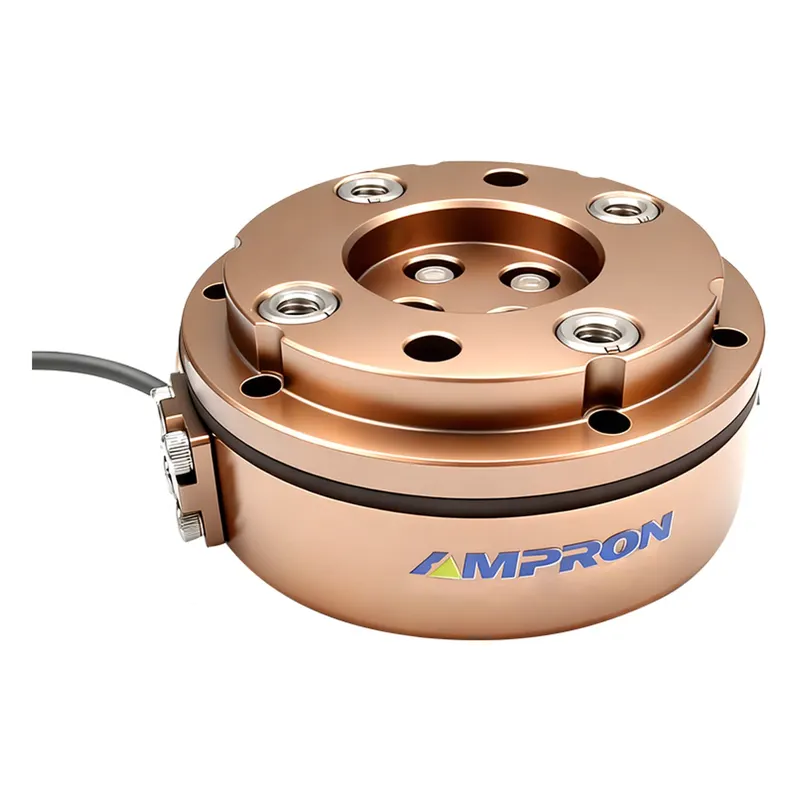
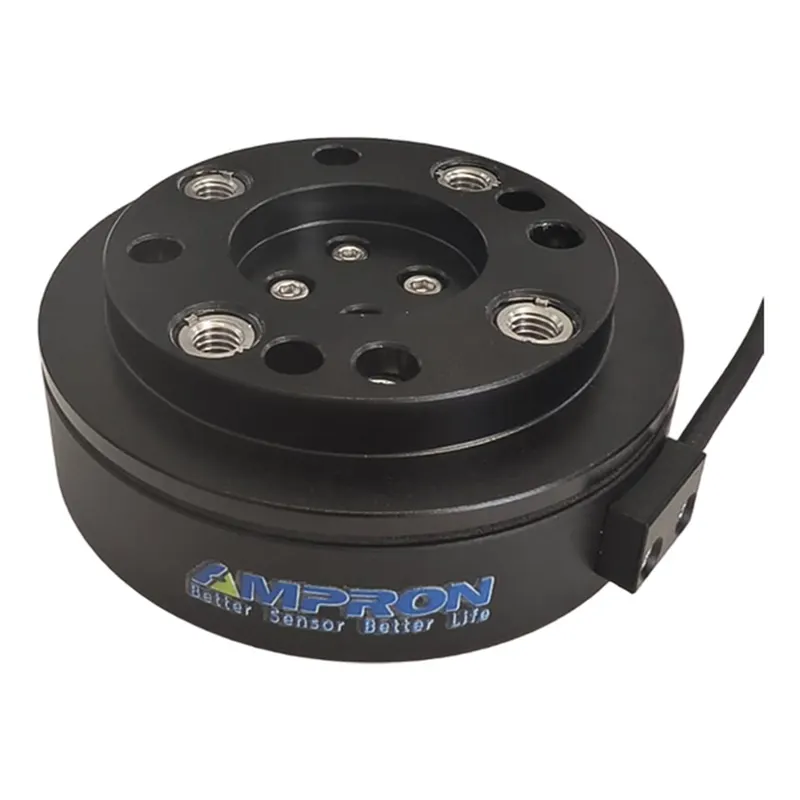
Ampron FSM6-D80 low-profile strain-gauge 6-axis F/T sensor, Ø80x28 mm, aluminum; ranges Fx/Fy 100-500 N, Fz 100-700 N, M 4-18 N·m; non-linearity ±0.3% F.S., repeatability ±0.1% F.S., crosstalk ±2% F.S.; 1000 Hz, RS485/CAN/EtherCAT, IP65, 300% F.S. safe overload; ultra-thin for space-constrained wrist/flange integration.