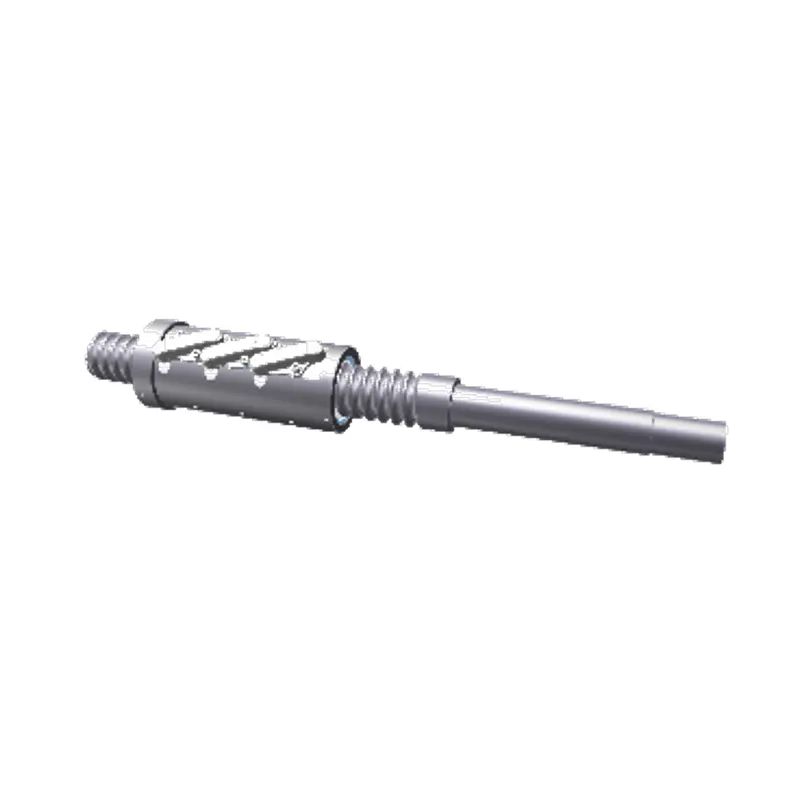
Hengli ball screw assemblies span BHSK/KHSK heavy-load, BRP/BRS external-circulation, DWP/DWS internal-circulation and KRP end-cap series; shaft 16-140 mm, lead 4-80 mm, accuracy C0-C10, DN up to 160,000, for robotics, machine tools and injection molding linear drives.
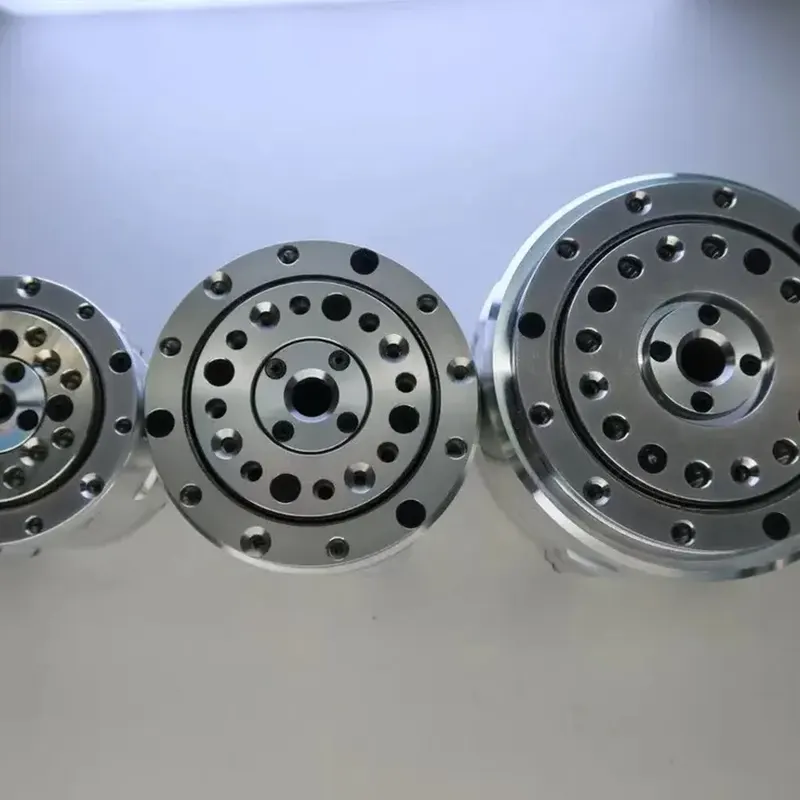
Hollow-shaft planetary integrated joint motor with dual absolute encoders, cross-roller bearing and CAN/CANFD MIT-protocol control.
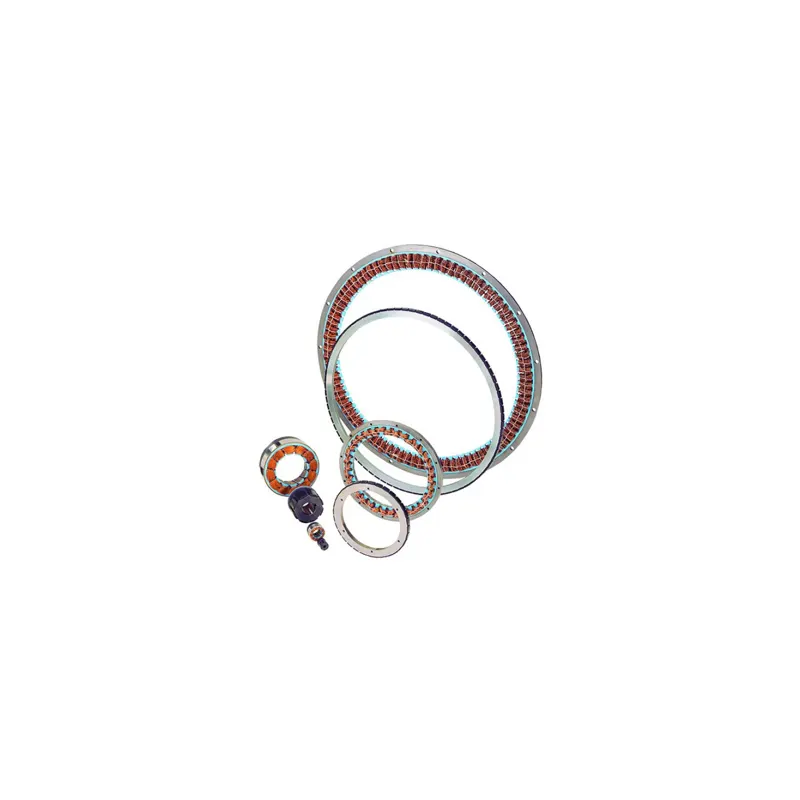
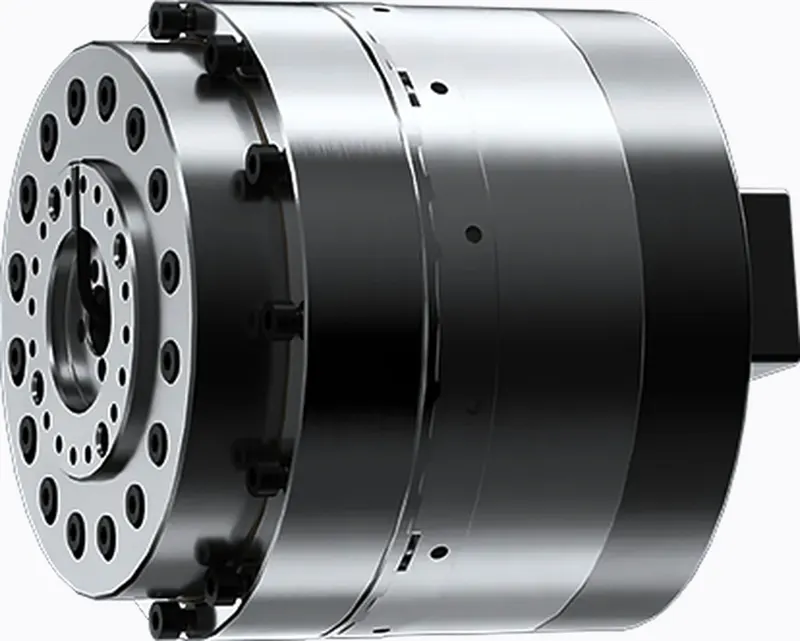
Megaflux is a high-torque-density family of frameless brushless direct-drive torque motors with 12 stator frame diameters from 60 to 792 mm and five stack lengths each; continuous stall torque spans 0.29-1,875 N·m with 48/150/300 VDC WYE windings; computer-optimized for maximum torque density and minimal cogging, the large through-bore passes cabling, piping or optical beams and the motors integrate directly into mechanisms, eliminating couplings and gear backlash for robot joints, gimbals and precision rotary tables.
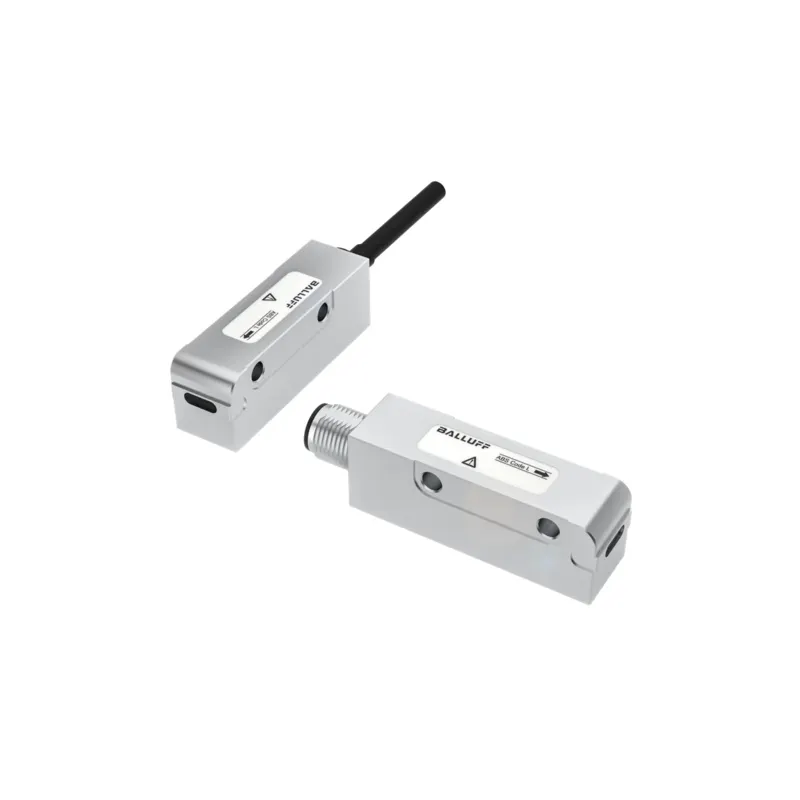
The BML SL1 is a magnetically coded absolute linear measuring system delivering absolute position immediately at power-on with no reference run; up to 8.19 m measuring length, 1 µm resolution and ±15-100 µm system accuracy with a generous 1.3 mm read distance; IO-Link 1.1 with parameterization, diagnostics and condition monitoring, optional analog sin/cos real-time output plus BiSS C / SSI variants; IP67 in zinc die-cast/stainless housing for absolute position feedback in robot linear actuators and rotary tables.
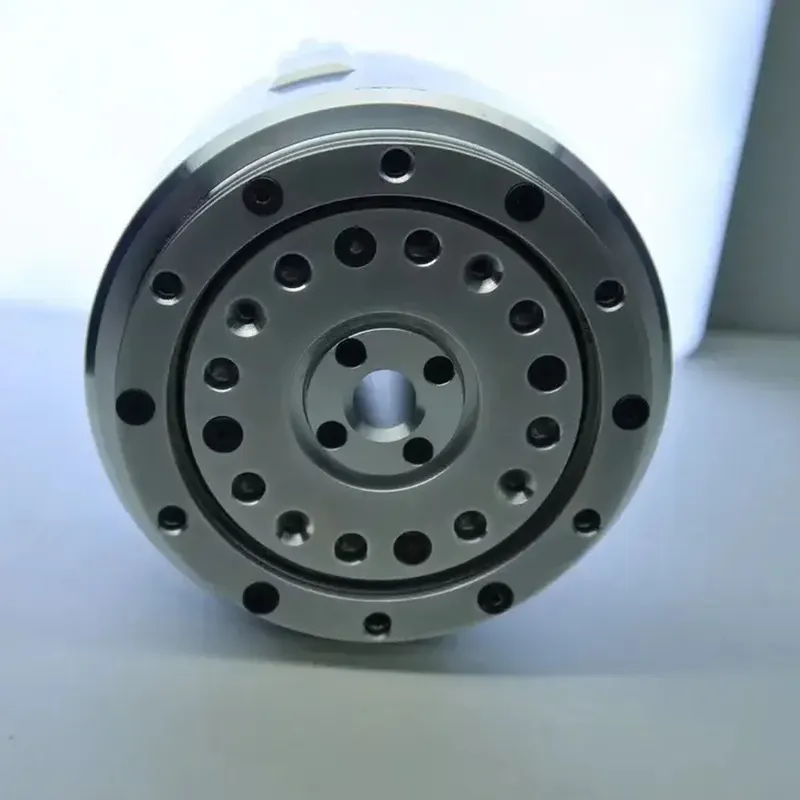
Harmonic Drive (Japan/US) invented strain wave gearing and leads the market. The CSG-2A is its second-generation cup-type component set: 10 sizes (14-65), ratios 50:1-160:1, repeated peak torque 23-3419 Nm and momentary peaks to 6175 Nm, zero backlash with high accuracy and a high-load output bearing, the de-facto standard reducer for robot joints; LW lightweight versions available.
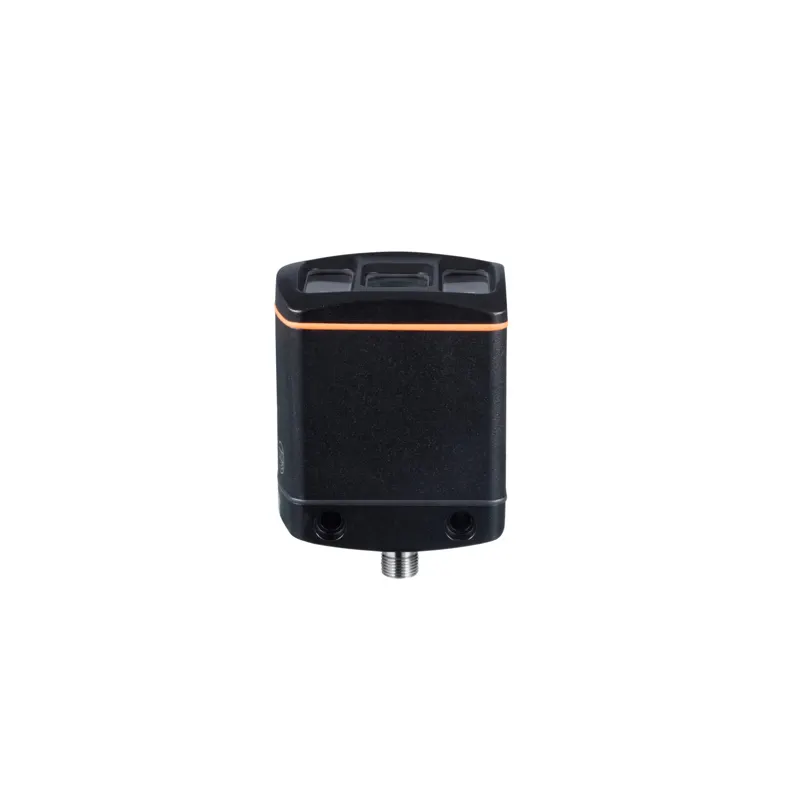
ifm (Germany) is a global leader in industrial sensors and IO-Link. The O3D300 is a 3D time-of-flight vision sensor (PMD chip, 176x132 px, 850 nm infrared) with a 0.3-10 m operating range and up to 25 Hz frame rate, featuring built-in volume, dimensioning, completeness and level monitoring plus robot gripper navigation and depalletizing, with switching outputs and an Ethernet process data interface for mobile robot and logistics automation.
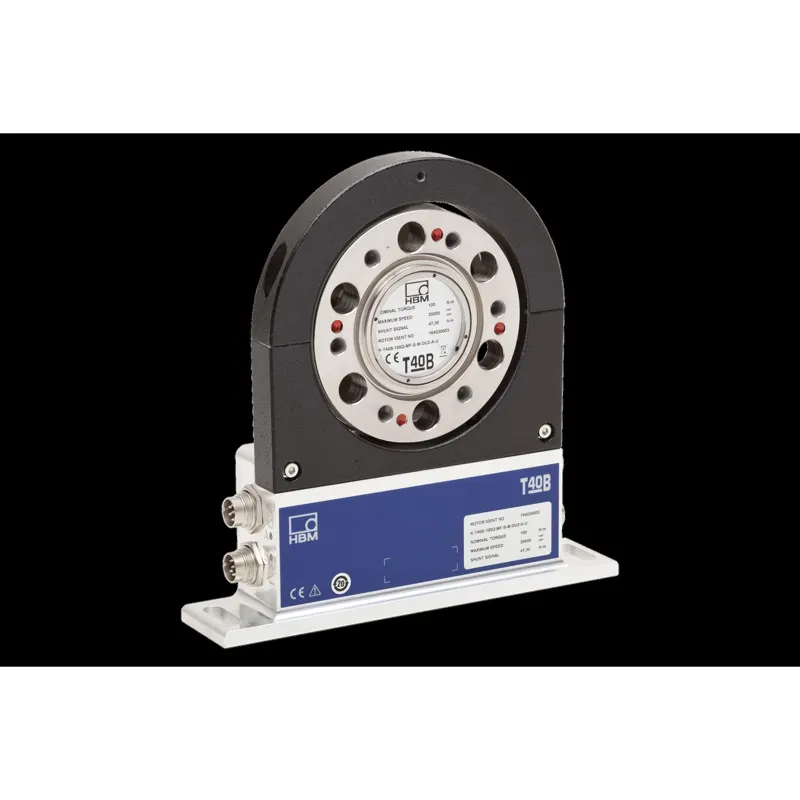
HBK (formerly HBM, Germany) is the benchmark in test & measurement and torque sensing. The T40B is a low-inertia torque flange with 0.05% accuracy class (linearity incl. hysteresis), nominal torques from 50 N·m to 10 kN·m and speeds up to 24,000 rpm. Non-contact power supply and digital transmission make it maintenance-free; TIM-EC (EtherCAT) and TIM-PN (PROFINET) interface modules plus optional magnetic speed measurement with reference pulse suit e-drivetrain, driveline R&D and end-of-line test benches.
CX Robotics (Beijing Changxing Power Robot Technology Co., Ltd.) self-developed CXR force-controlled rotary actuator series integrating frameless torque motor, harmonic reducer, dual encoders and driver for precise force/position/velocity control; four sizes CXR-14/17/20/25 (the site's table mislabels the latter two as CXL-20/25) with rated torque 9.6/30/50/84 N.m, start-stop permissible torque 34/66/102/194 N.m, 29.7-34.6 rpm max output speed, customizable 30-120 reduction ratio, 0.86-2.7 kg mass, phi70-phi110 mm OD and phi6-phi12.5 mm hollow shaft; 17-bit magnetic dual-encoder closed loop with 20 arcsec repeatability, optional torque sensor (0.2% F.S. force control) and brake, 48 VDC, rated/max power 49/103 W up to 483/785 W. Suited to variable-load, variable-inertia humanoid robot joints.
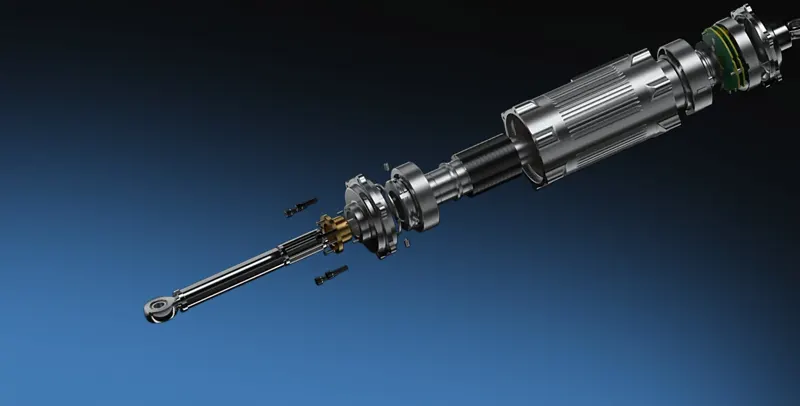
CX Robotics (Beijing Changxing Power Robot Technology Co., Ltd., Beijing, military-grade integrated linear joint module specialist) self-developed CXL force-controlled linear actuator series with a proprietary mechatronic-control trinity design: in-house frameless torque motor, driver and high-precision planetary roller screw deeply integrated in one joint module for plug-and-play precise force control; three sizes CXL60/CXL200/CXL400 with rated/peak thrust 600/1500 N, 2000/5400 N, 4000/12000 N, max speed 83/120/180 mm/s, 0.02 mm repeatability, 40/60/80 mm stroke, 40/57/75 mm OD, 135/200/246 mm length, 0.6/1.4/3.1 kg mass on a 48 V platform, rated/max power 48/78 W up to 635/1545 W; 17-bit magnetic encoder standard, optional force sensor (0.5% F.S.), EtherCAT/CANopen/Modbus. Targets humanoid leg/waist linear joints, wheeled lifting columns and high thrust-density applications.