ETH RSL: high-speed rough-terrain locomotion for ANYmal via automatic curriculum RL
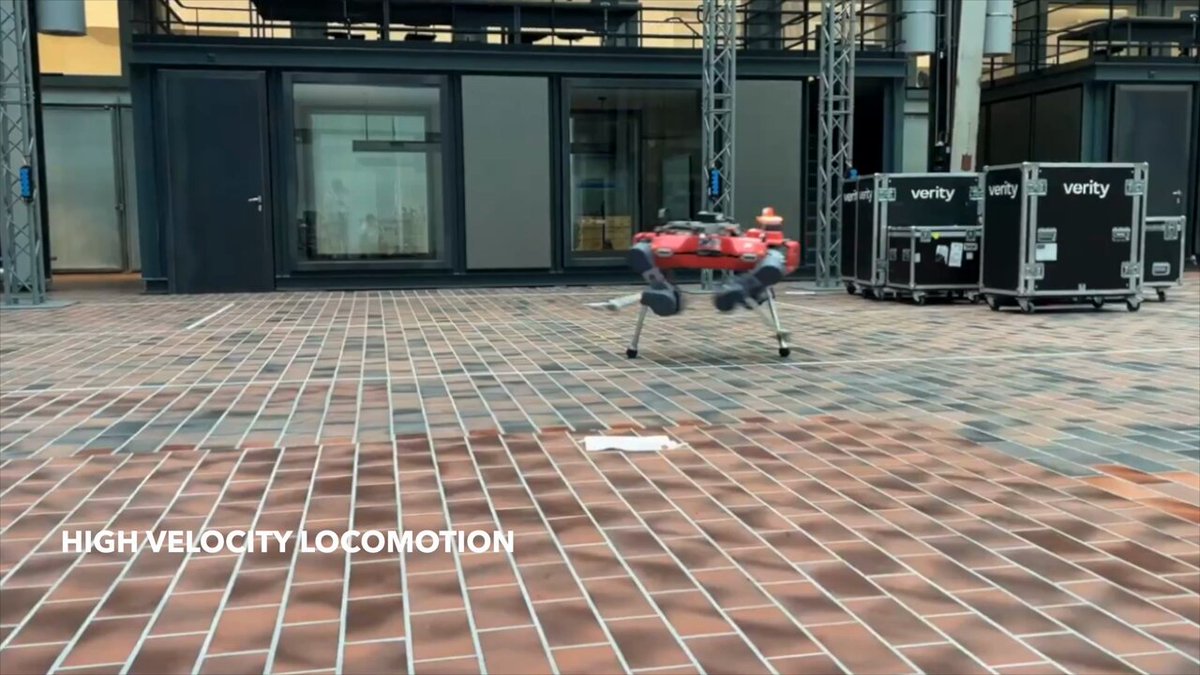
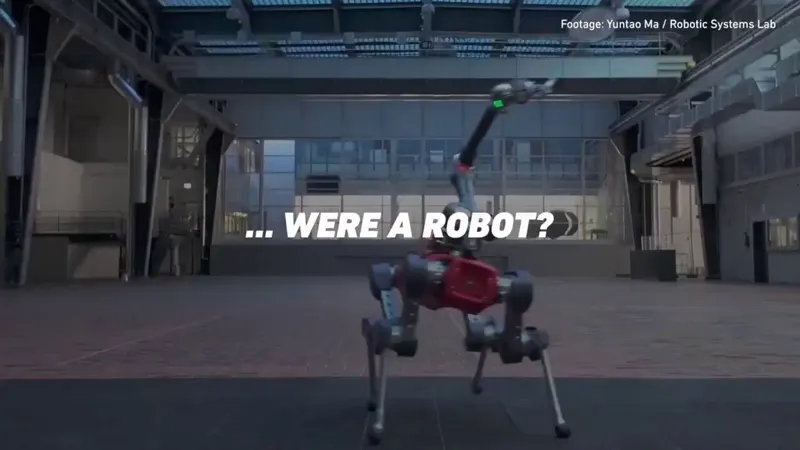
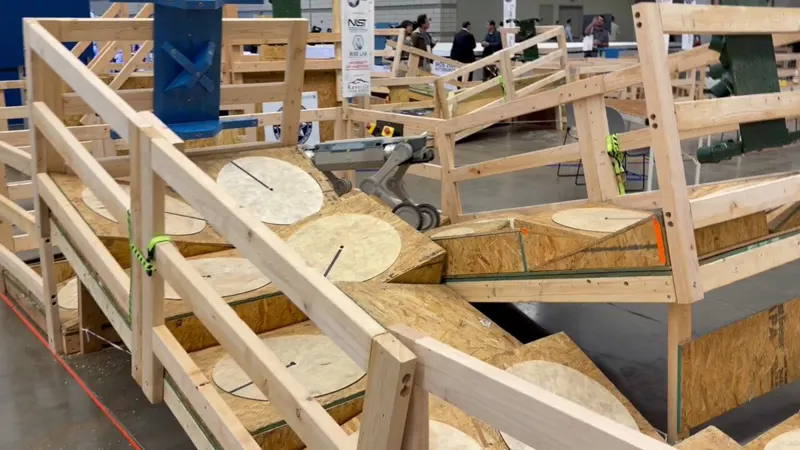
ETH Zurich Robotic Systems Lab (Marco Hutter group, RAL 2026) presents LP-ACRL: a Learning Progress-based Automatic Curriculum Reinforcement Learning framework. It estimates the agent learning progress online and adaptively adjusts the task-sampling distribution, requiring no prior knowledge of the difficulty structure over the task space - solving the long-standing problem that difficulty ordering is undefinable in complex, wide-ranging task spaces. Policies trained this way let the ANYmal D quadruped sustain 2.5 m/s linear velocity and 3.0 rad/s angular velocity across stairs, slopes, gravel and low-friction flat surfaces, where previous methods were limited to high speeds only on flat terrain or low speeds on complex terrain. The paper highlights scalability and real-world applicability, offering a robust baseline for curriculum generation in complex robotic learning task spaces.