Uni-VLaT: adding whole-body touch to pretrained VLAs lifts humanoid loco-manipulation from 32% to 75%
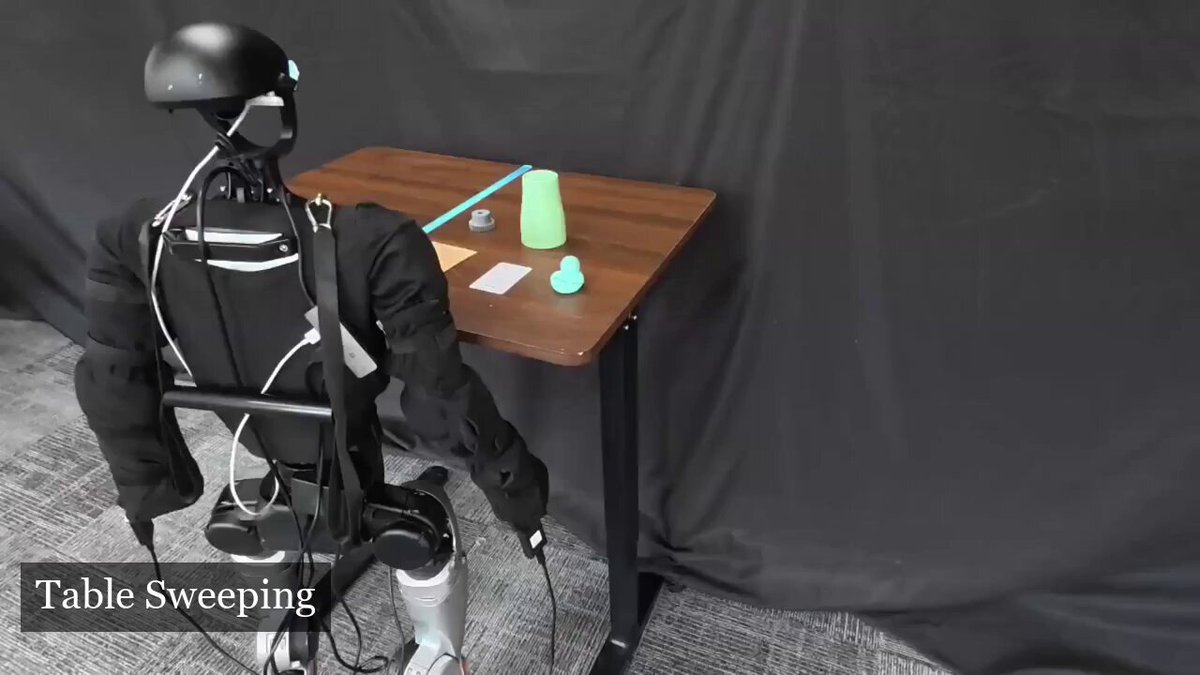
Uni-VLaT adds whole-body tactile sensing to pretrained VLA policies for humanoid loco-manipulation, raising average success across five real-robot tasks from 32% (no tactile) to 75%, seven points above tactile input alone (68%). The standout is Back-Tap Walking: tap the robot on the back and it walks, stop tapping and it stops - zero visual signal involved. Success goes from 0% without touch to 85% with it, which is not a touch-helps result but a this-task-does-not-exist-without-touch result. It also generalizes across GR00T and pi-0.5 backbones. Method: regional sensor readings become spatial tactile tokens with a short causal history capturing contact onset, support and release; training-only heads predict future tactile, proprioceptive and visual representations; the tactile pathway adapts pretrained VLA policies while retaining their visual and language priors.