X-WBC: A Cross-Embodiment Foundation Model for Humanoid Whole-Body Control
Loading video
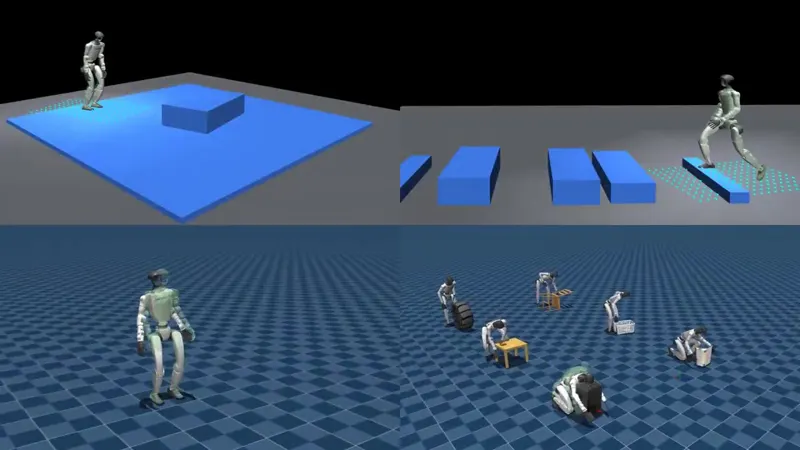
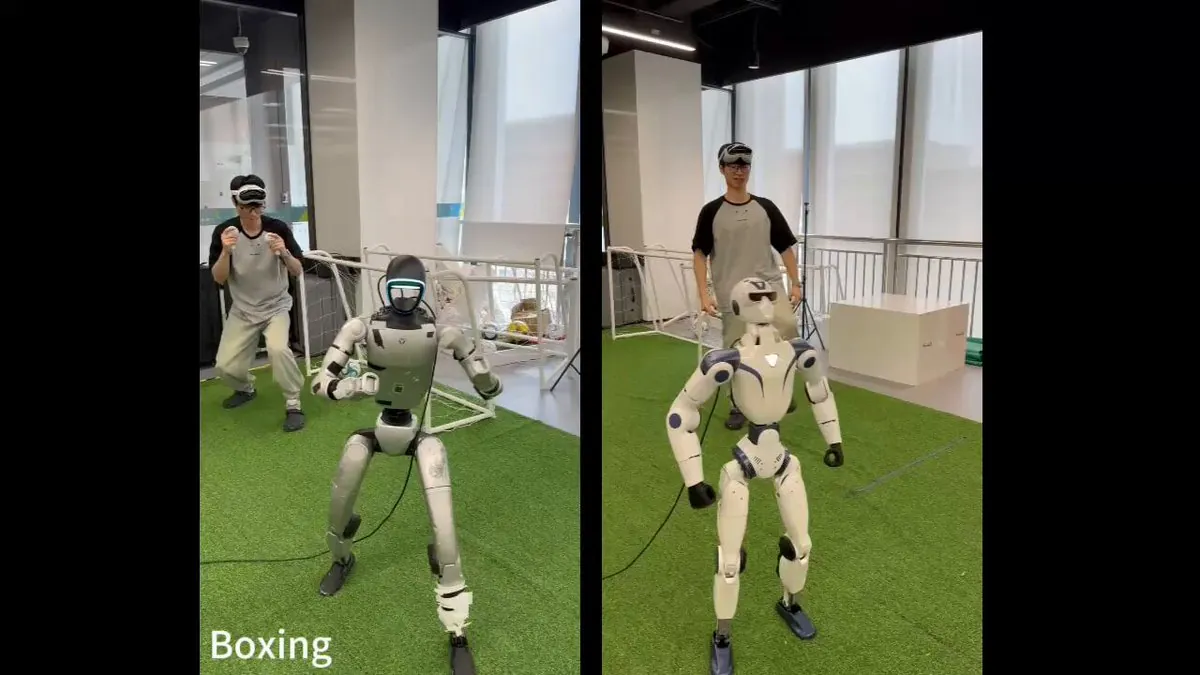
Loading videoX-WBC changes the training unit from one robot to one motion: human motion, 5-point VR tracking and robot-specific reference motion all map into a shared motion-token space, a causal Transformer learns the temporal structure, and lightweight per-robot encoders/decoders handle each body. Joint training across nine embodiments gives 94.2% same-motion Recall@1, and the same sparse VR command runs on G1, R1, H1-2 and H2.
Category: humanoid
Author: @vigram_void
Date: 2026-09-16T00:00:00
Duration: 29.833s
Reference: https://arxiv.org/abs/2609.15213