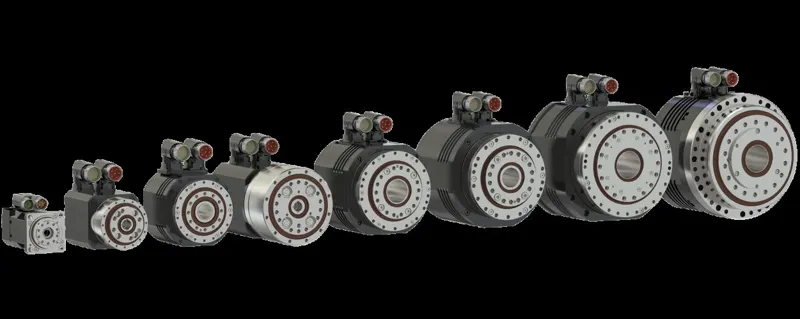
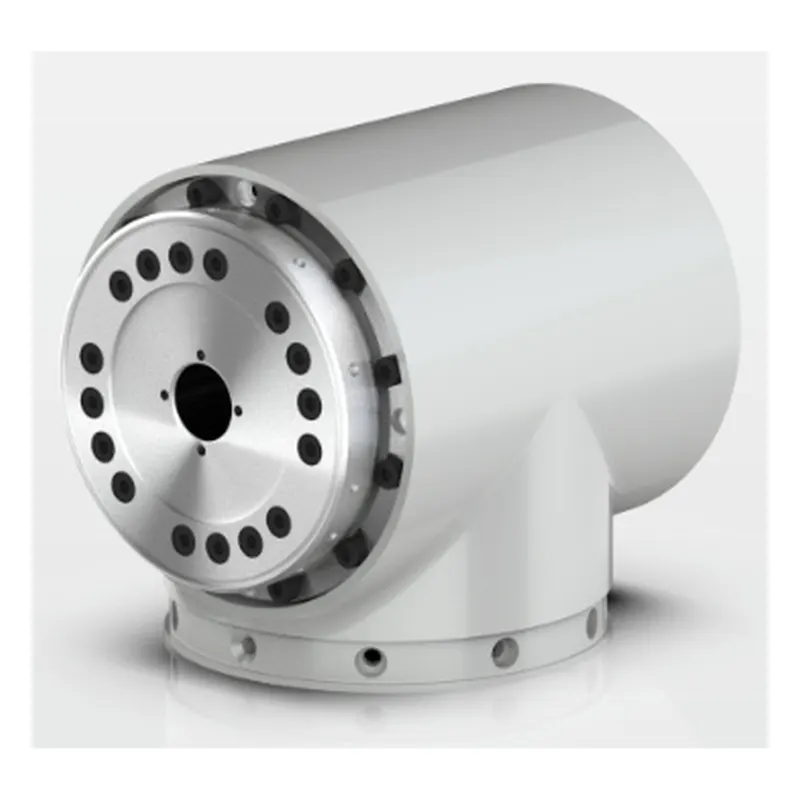
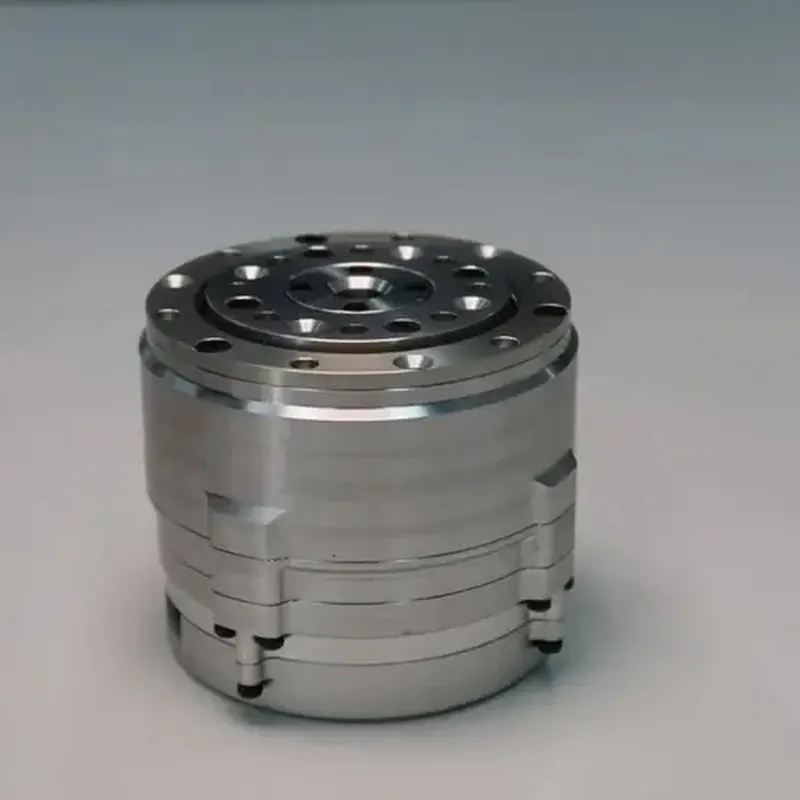
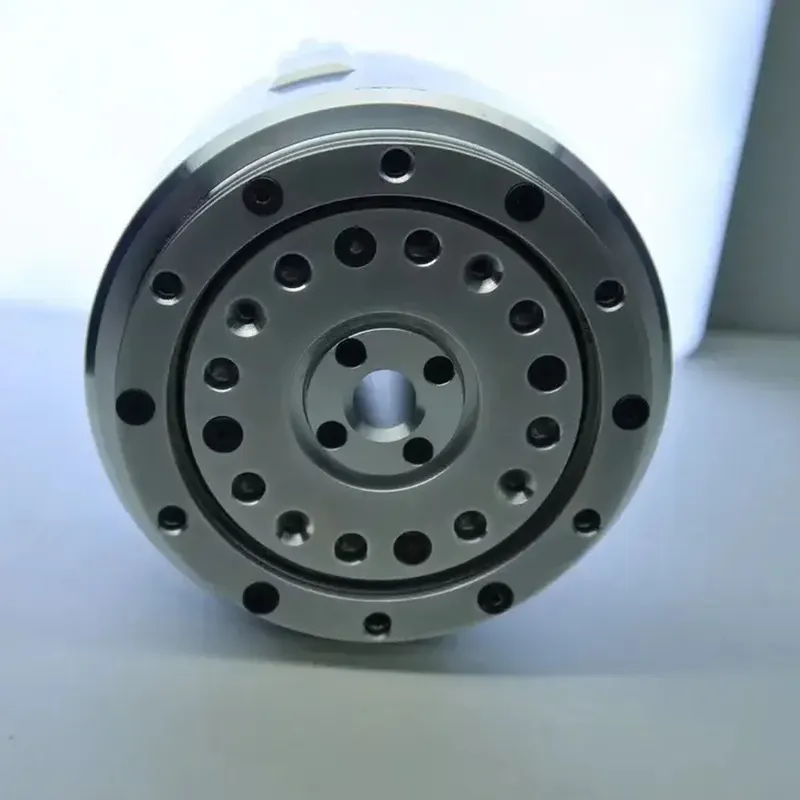
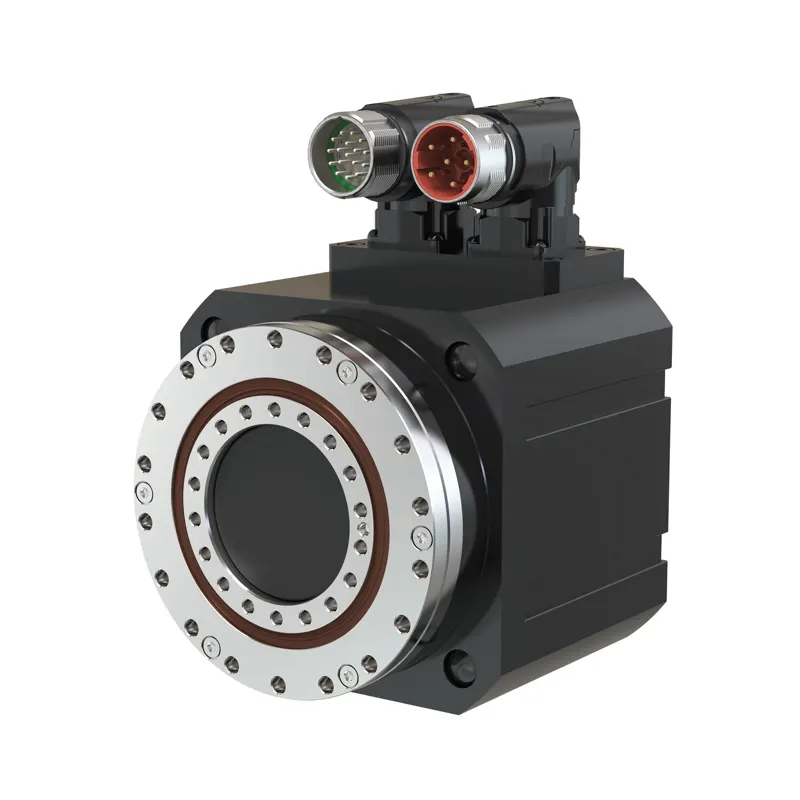
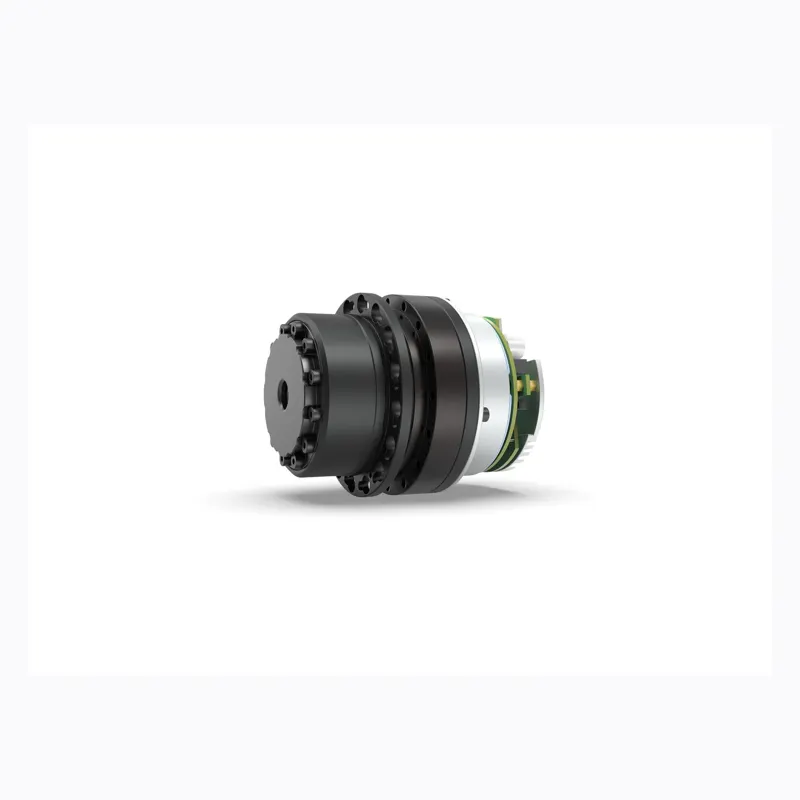
SPINEA (Slovakia, a Timken company) DriveSpin DSH are fully sealed integrated electric actuators combining zero-backlash cycloidal reduction with a servo motor, short axial length and 8-40 mm through-hole for cables, pipes or shafts; ten frames DSH 050-170 with 18-420 Nm rated torque, peak about 2x rated (DSH070: 50/100 Nm), ratios 57-125, 2,000 rpm rated input, high positioning and repeat accuracy for robot joints, AGVs and medical devices.
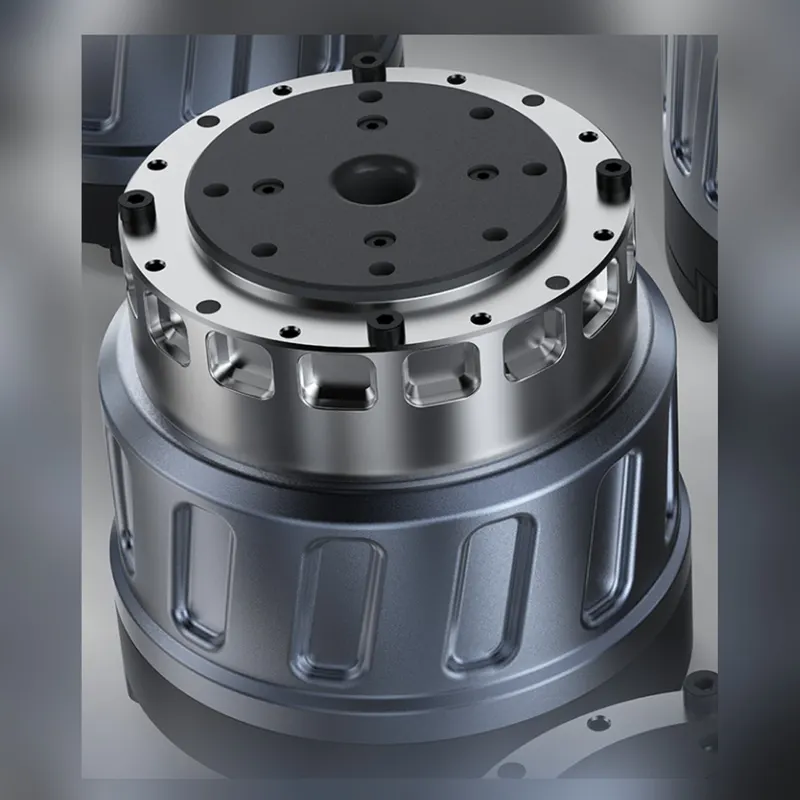
PHYBOT's new-generation PhyArc quasi-direct-drive integrated cycloidal joint modules come in six sizes (47/68/78/95/102/150) with in-house torque motors, cycloidal reduction and dual encoders in a hollow-shaft design; peak torque 12-590 N.m, peak torque density up to 244 N.m/kg, repeatability better than 1 arc-minute, and inertia+damping compensation surviving over 5x instantaneous overload impacts; shipped with SDK, interface board and dev kits for humanoid and other robotics scenarios.
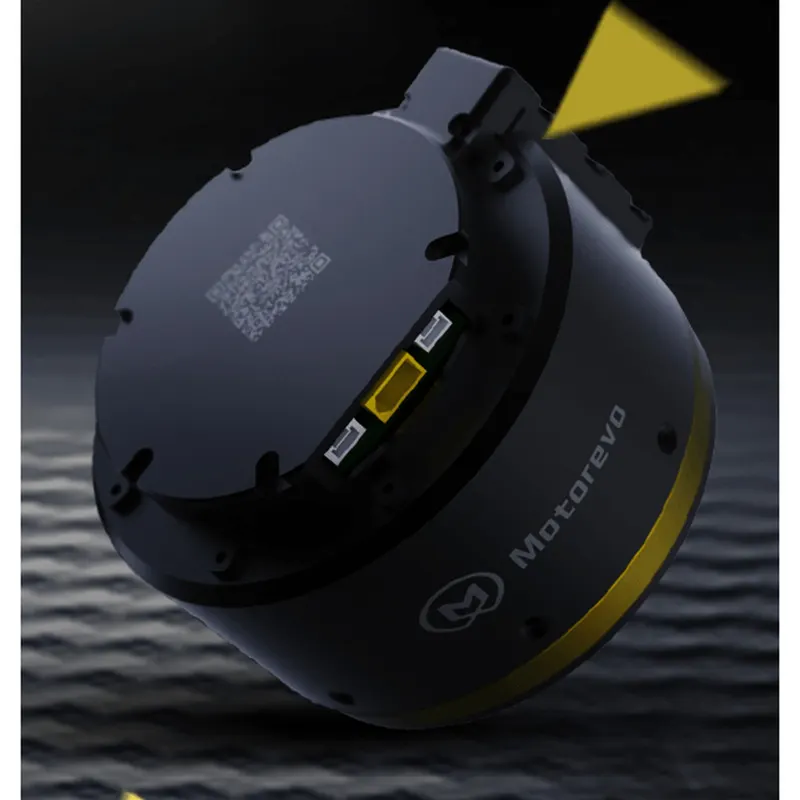
Motorevo (Wuxi, est. 2020) positions itself as a universal next-gen integrated robot joint platform. REVO PA planetary series (7 models, RR-PA-70-1015 to 100-2020): 89.9-119 mm OD, 650-1950 g, 10-80 N·m continuous / 39-250 N·m peak torque, ratio 10-35, <0.3° accuracy, 14-bit encoder, 24/48 V, CAN. REVO HA harmonic series (9 models, RR-HA-40-100 to 80-100): 56-95 mm OD, 350-1100 g, 5.4-67 N·m rated / 19-157 N·m peak, ratio 80-100, ≤10-20 arcsec accuracy, 14/15-bit encoder, 24/48 V, CAN+EtherCAT. Hollow-bore wiring and position/velocity/torque/force-position hybrid control for humanoid and cobot joints.
Haozhi integrated robot joint module in six sizes (14-40), combining a frameless torque motor, high-stiffness harmonic reducer, dual absolute multi-turn 18-bit BISS-C encoder and large-hollow low-voltage drive; ratios 50-160, peak torque 23-841 N.m with 3.5x overload, positioning <0.015° and repeatability 0.003°, EtherCAT/CANopen daisy-chain, 48 V supply with 24 V STO/SBC safety, friction brake, 12/18 mm through-bore, torsional stiffness 1.1-41 Nm/arc-min; for collaborative and humanoid robot arms.
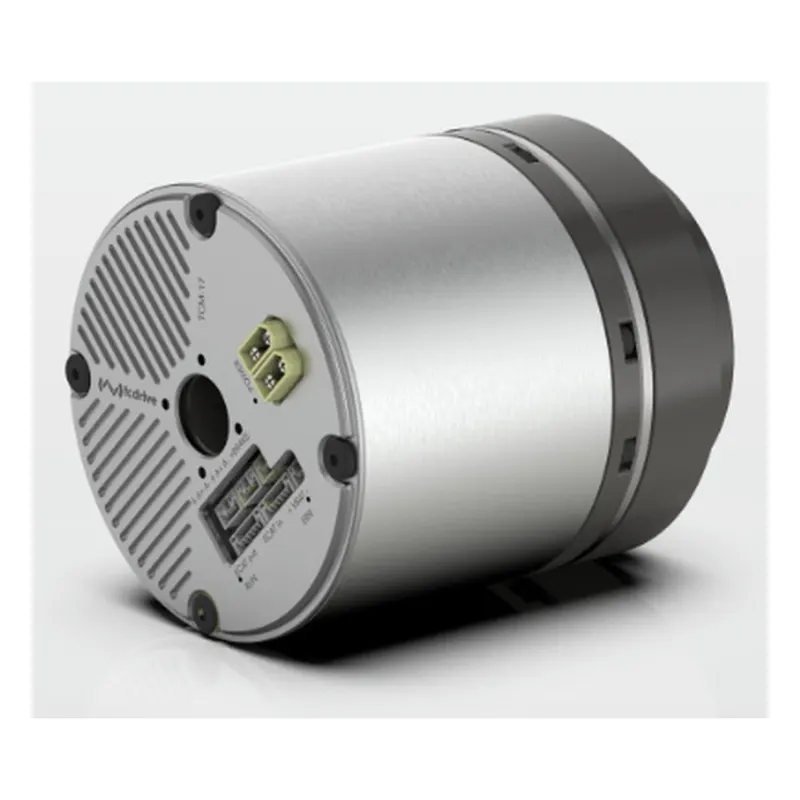
TCM14B/17B closed-loop joint modules, DC48V, dual magnetic encoders with built-in brake, full closed-loop control, backlash <=10 arcsec, 90 arcsec positioning, 0.95/1.4 kg, ratios 11-40, for lightweight joints and exoskeletons.
TRM14/17/25/32 integrated joint modules, peak torque 46-672 Nm, DC48V, built-in 17-bit absolute encoder, IP54, 1.6-8.2 kg, 15,000 h life, covering mainstream cobot and humanoid joint sizes.
Hollow-shaft planetary integrated joint motor with dual absolute encoders, cross-roller bearing and CAN/CANFD MIT-protocol control.
SPINEA (Slovakia, now part of Timken) is a European leader in precision cycloidal reduction and integrated actuators. DriveSpin combines an optimized servomotor with a TwinSpin cycloidal gear into a zero-backlash, high-dynamic actuator with high torsional/tilting stiffness and integrated output bearing: DS Standard covers 18-460 N·m rated torque with up to 1150 N·m acceleration/braking torque, ratios 47-133, 2000 rpm rated input; DSH hollow-shaft, DSM modular and DSF flat variants complete the line. Used in 6-axis robots, gantries and manipulators, CNC machines, bending machines, medical equipment, aerospace, flight simulators, semiconductor and radar systems.
The TSJA series (14/17/20/25) are TLIBOT's ultra-lightweight integrated joints combining motor, reducer, dual 19-bit encoders and a tooth-mesh electromagnetic brake at 48V with EtherCAT; 6.8-86 Nm rated and 24-229 Nm peak torque at only 0.38-1.6 kg, +/-180 deg output and 13 arcsec repeatability, providing high torque density for humanoids and lightweight arms.