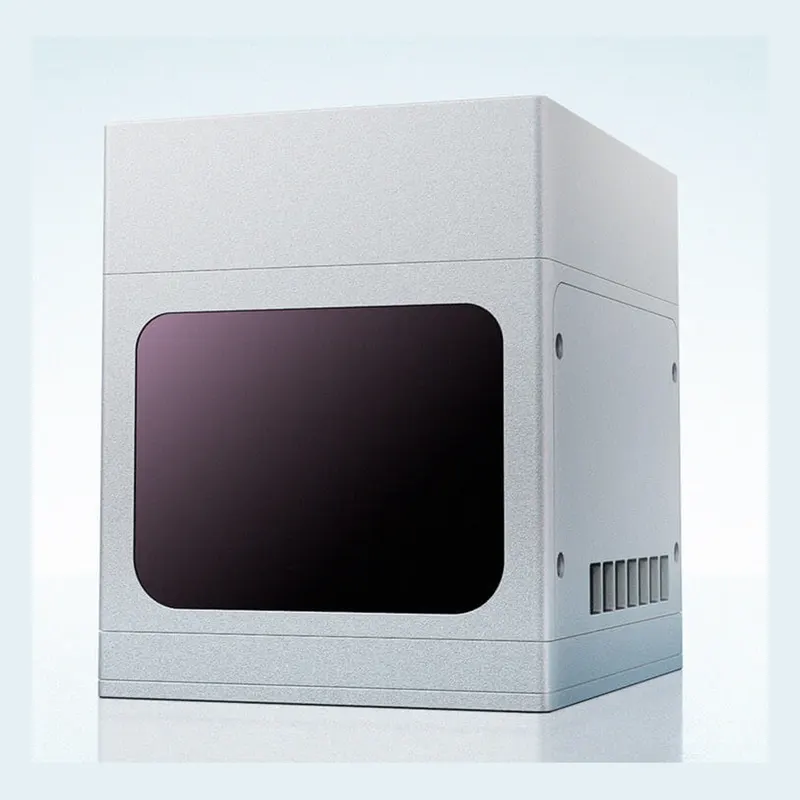
Livox Avia 2 long-range hybrid solid-state LiDAR with a 1535 nm eye-safe laser: normal mode 400 m @5% reflectivity with 80°×80° FOV; focus mode ≥800 m @10% (max 1000 m) with 15°×15° FOV; ≤5 cm range accuracy, ≤0.02° angular precision, 350k/100k pts/s, IP66, 50 W steady-state, 9-27 V DC, ≤1.8 kg; for long-range, high-precision perception and fixed-point observation.
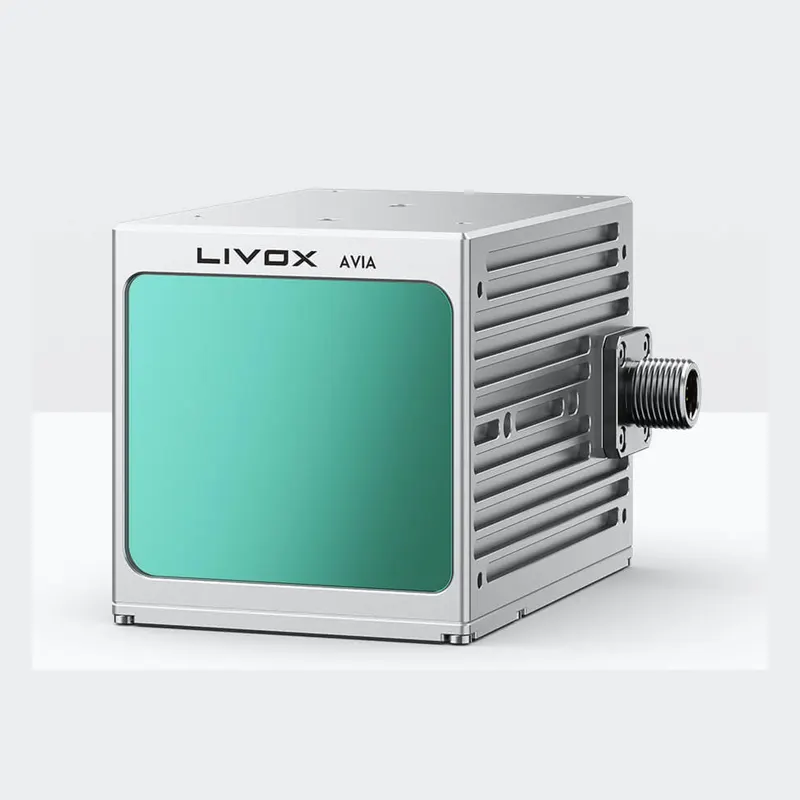
Livox Avia non-repetitive scanning hybrid solid-state LiDAR: 190 m @10% reflectivity (100 klx) and 450 m @80% (0 klx) range, 70.4°×77.2° FOV, 2 cm @20 m precision, <0.05° angular precision, up to 720k pts/s (triple return), ≤2 ms latency, built-in BMI088 IMU, IP67, 8-9 W, 91×61.2×64.8 mm / 498 g; balances long range with high precision for mapping, inspection and autonomous driving.
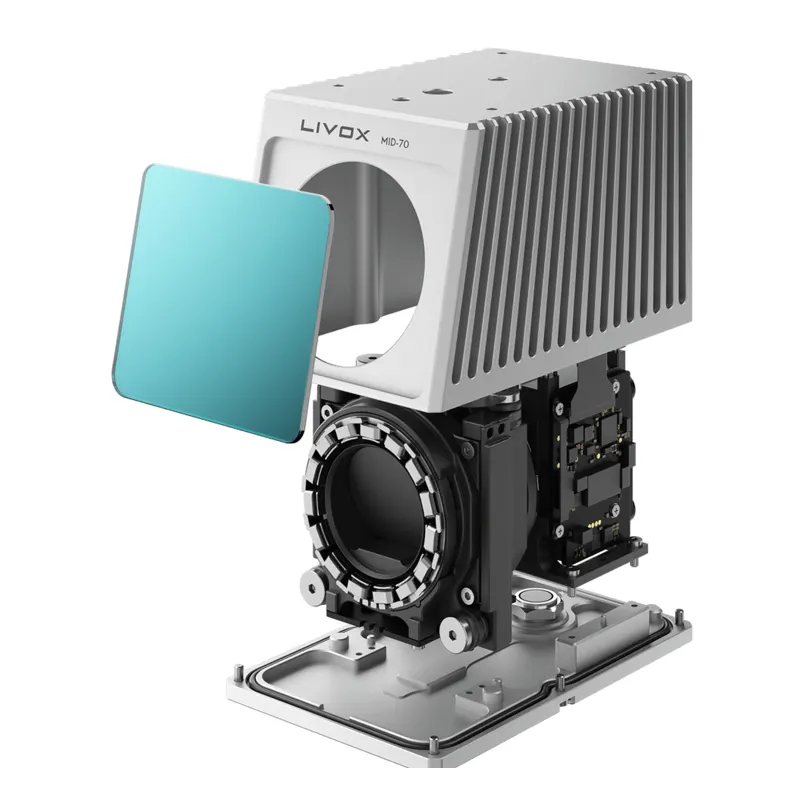
Livox Mid-70 non-repetitive scanning hybrid solid-state LiDAR: 70.4° circular FOV, 90 m @10% / 130 m @20% / 260 m @80% reflectivity range, ≤2 cm @20 m precision, <0.1° angular precision, 100k (single) / 200k (dual return) pts/s, ≤2 ms latency, IP67, 8 W average, 97×64×62.7 mm / 580 g, -20 to 65°C; angular resolution improves with integration time, suited to mid-range 3D perception on autonomous and inspection vehicles.
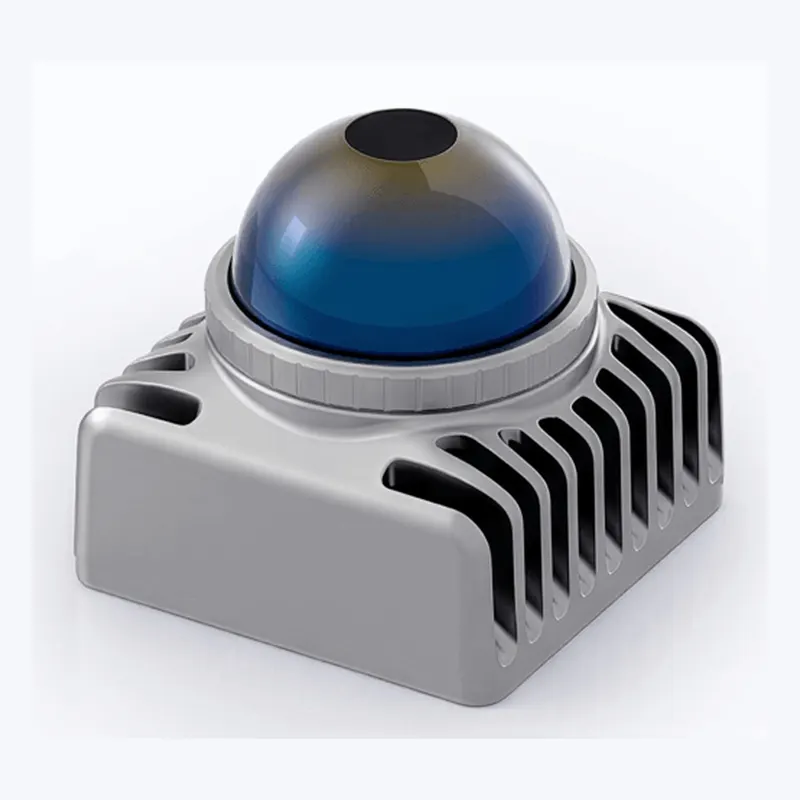
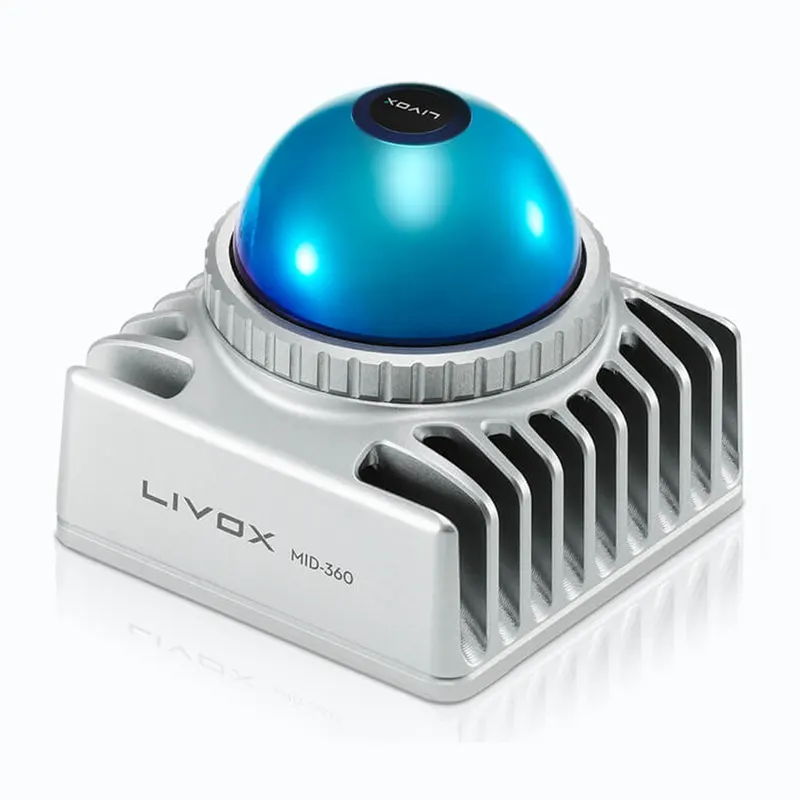
Livox Mid-360S, the cost-optimized next-generation 360° hybrid solid-state LiDAR for mobile robots: same 65×65×60 mm / 265 g form factor as Mid-360, 905 nm Class 1, 360° H x (-7° to 52°) V FOV, range upgraded from 40-70 m to 38-100 m @10% reflectivity at WRC 2026, with sharper mapping edges, 0.1 m blind zone, ≤2 cm @10 m / ≤4 cm @0.2 m precision, <0.15° angular precision, 200k pts/s, IP67, 6.5 W, built-in ICM40609 IMU and active anti-interference; for indoor/outdoor service robots, autonomous forklifts and inspection platforms.
Livox Mid-360 hybrid solid-state 3D LiDAR for omnidirectional robot perception: 905 nm Class 1 laser, 360° H x (-7° to 52°) V FOV, 40 m @10% / 70 m @80% reflectivity range (100 klx), 0.1 m blind zone, ≤2 cm range precision @10 m, <0.15° angular precision, 200k pts/s @10 Hz, built-in ICM40609 IMU, IP67, 6.5 W, 9-27 V DC, 65×65×60 mm / 265 g; widely used for navigation and obstacle avoidance on AGVs, inspection and service robots.
Tashan Tech TS-F-A general-purpose tactile fingertip with integrated 3-axis force tactile sensing and proximity sensing (independent sensing unit): 0.01 N normal-force resolution, 0.25 N tangential-force resolution, 2-10 cm proximity range, 1000 N safe overload, 3M-cycle life, on-board R-SpiNNaker neuromorphic chip recognizing 30+ materials, I2C interface; for humanoid dexterous-hand grasping and tactile perception.
Hanwei (Winsensor) stretch strain sensor ESSA-01/ESSB-01, 0.36/1 mm thick, 0-50% stretch range, 0.05% resolution, 99.9% linearity, >150k/300k cycles, 10-60 C, machine-washable >30/60 times; for flexible deformation and joint bending monitoring.
Hanwei (Winsensor) pressure-strain sensor ESPB-01/B1, 2.3/2 mm thick, range 0-850 N / 0-1800 N, resolution 0.5/1.5 N, >300k cycles, 10-60 C, machine-washable; for large-range flexible force measurement.
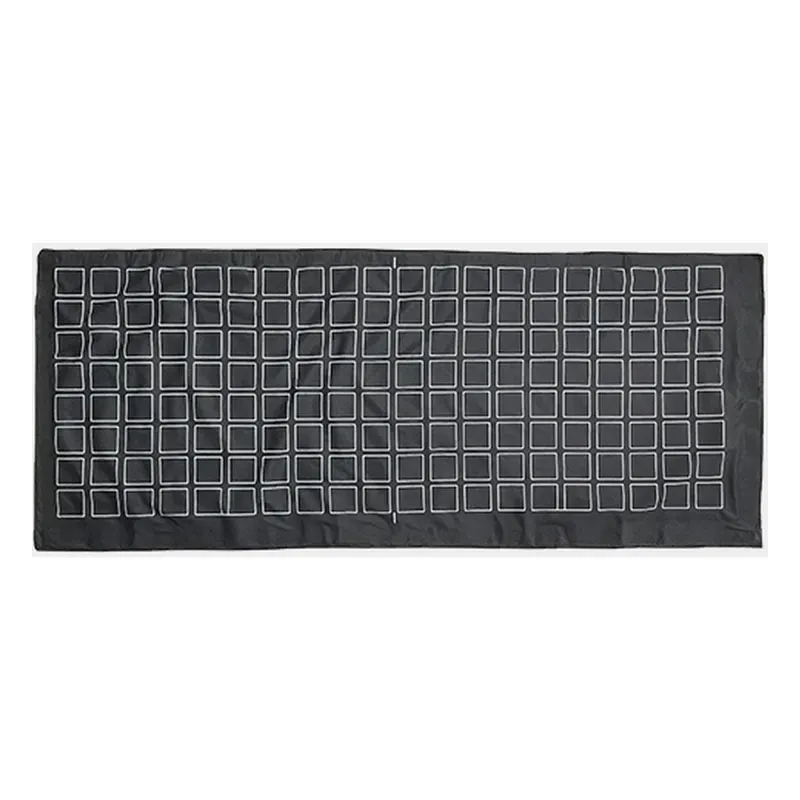
Hanwei (Winsensor) flexible pressure array sensor on fabric/TPU substrate, freely bendable; range 5-50 N, accuracy ±15%, 50 Hz refresh, 100 ms response, 0-40 C; for robot tactile skin and pressure distribution mapping.
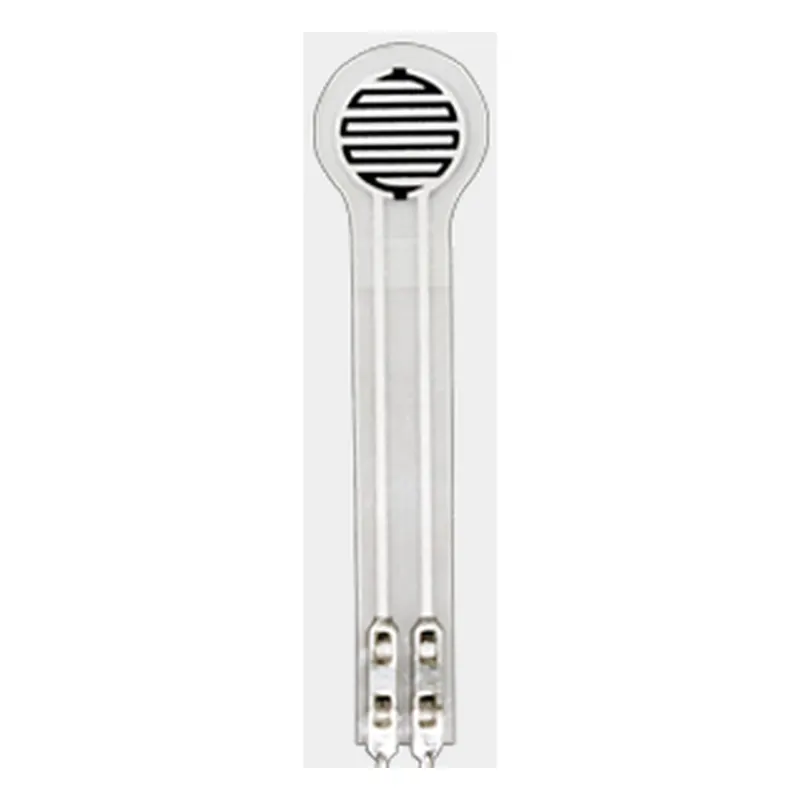
Hanwei (Winsensor) DF9 resistive flexible thin-film force sensor, <0.3 mm thick, ranges 0-500 g to 0-20 kg (DF9-40/DF9-16), accuracy ±2.5%, response <1 ms, recovery <15 ms, >1M cycles life, >10 MOhm initial resistance, 3.3 VDC, -20 to 60 C; for robot grip force, foot pressure and contact sensing.
Xense Elf fingertip optical tactile sensor: 15x18 mm sensing area, 22.2x15.4x14.2 mm body, 125 markers/cm2, 0.04 mm spatial resolution, 30-150 Hz, UVC, 0.3 W; deformation 0.08 mm, force 0.03 N; six modalities, designed for dexterous-hand fingertips.
Xense Photon wedge-type optical tactile sensor: 17.5x29.5 mm sensing area, 52.8x27x22 mm body, 120 markers/cm2, 0.03 mm spatial resolution, 30-150 Hz, UVC, 0.6 W; deformation 0.06 mm, force 0.02 N; six modalities for compact gripper integration.