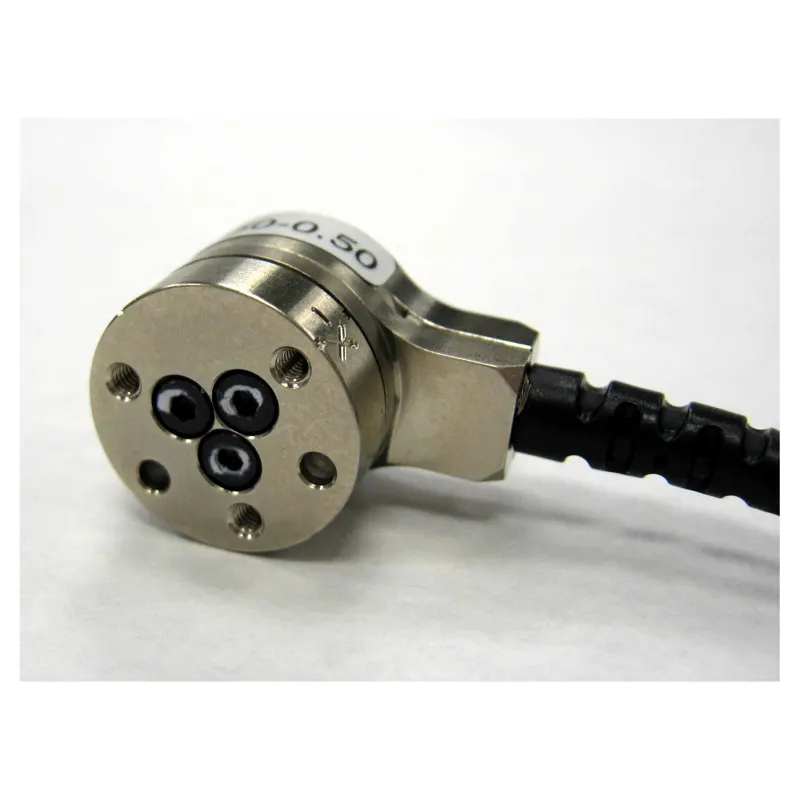
ATI Industrial Automation (USA, a Novanta company) leads the world in 6-axis force/torque sensing. The Nano17 is the smallest commercial 6-axis transducer available: 17 mm diameter, 14.5 mm height and just 9.07 g including interface plates; silicon strain gages deliver 75x the signal of foil gages with resolution down to 1/320 N (~0.32 gf); SI calibrations SI-12/25/50 span 12-50 N (Fxy), 17-70 N (Fz) and 120-500 N-mm torque; single-axis overload of +/-250 N (Fxy) and +/-480 N (Fz), 3.1-13.8x rated; 7200 Hz resonant frequency; IP65 and IP68 (10 m) versions; NIST-traceable calibration under ISO 9001. Used in robotic surgery, dexterous-hand and finger-force research and dental research.
Integrated force-control joints combining an inner-rotor frameless torque motor, reducer, dual absolute encoders and a torque sensor; six sizes HSA-11 to 32 with 11-459 Nm peak torque, 100 Hz force loop, 32 kHz sampling and EtherCAT, delivering high torque density for humanoid and wheeled dual-arm robots.
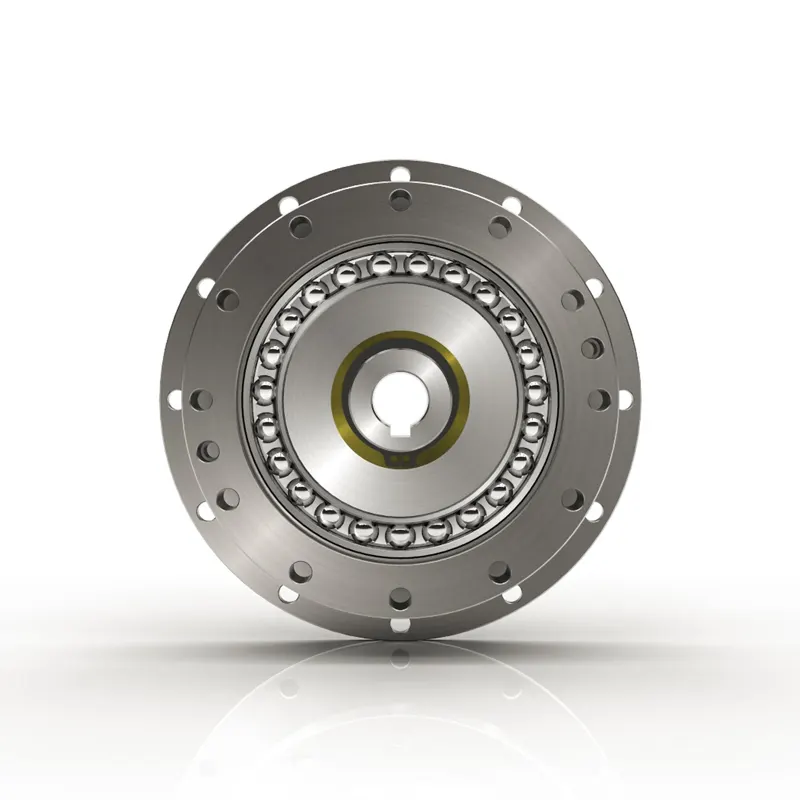
Harmonic Drive is the inventor and global leader of strain wave (harmonic) gearing. The SHG-2A silk-hat component set (wave generator, flexspline, circular spline, output flange) is axially shorter than the cup-type CSG, spanning 10 sizes 14-65 with ratios 50-160: rated torque (L10) 7-1,236 N·m, repeated peak 23-3,419 N·m, momentary peak 46-6,175 N·m, backdriving start torque only 2.2-180 N·m, standard accuracy 1 arcmin (1.5 for size 14), zero backlash, torsional stiffness K1 0.47-54 x10^4 N·m/rad at 0.11-7.04 kg - ideal for axially constrained precision joints in humanoid/cobot shoulders, elbows and wrists.
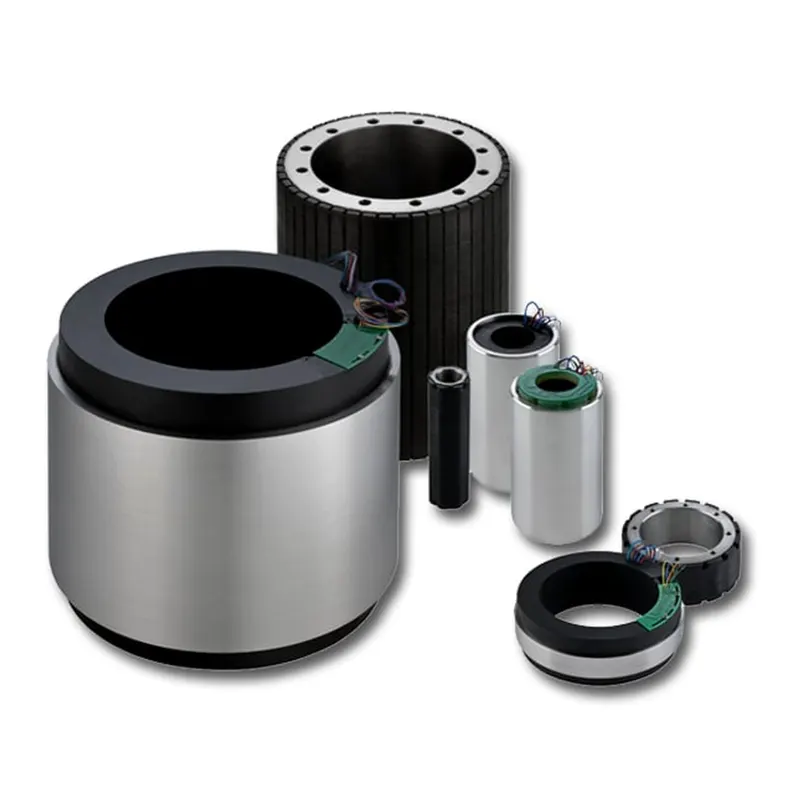
The KBM series embeds directly into the machine with fully encapsulated stators and a through-bore rotor supported by the machine's own bearings, eliminating couplings and gearboxes; 14 frames across servo (10-45) and torquer (43-260) form factors, 120-480 Vac, peak stall torque up to 12,812 N·m, widely used in humanoid/cobot joints, gimbals and precision rotary tables.
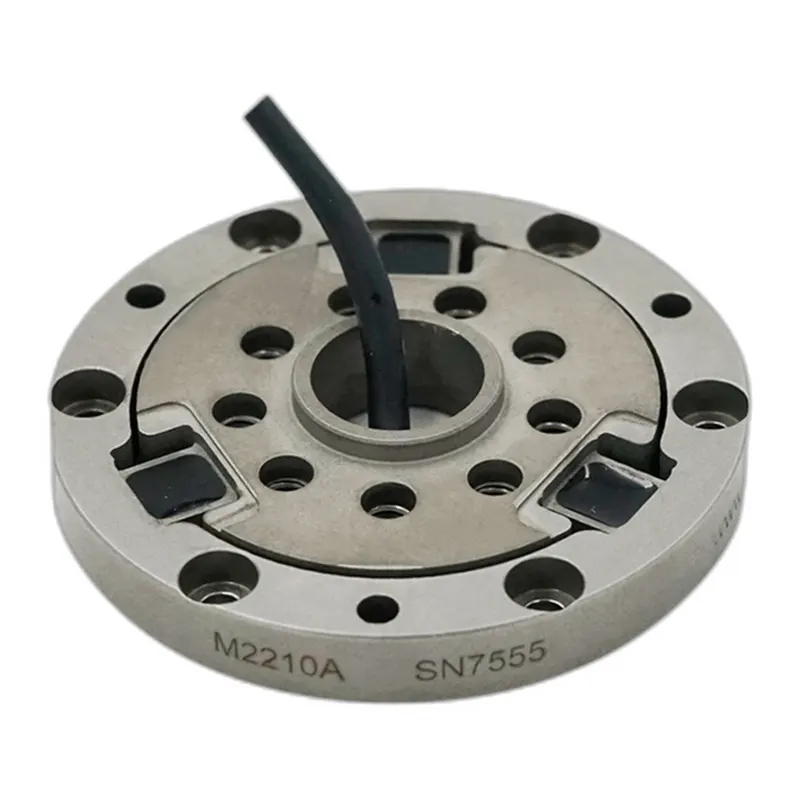
The SRI Instruments M2210 family (M2210–M2214, 257 models) measures motor/reducer output torque across 10–850 N·m with high precision, thin profile, light weight, high rigidity and strong bending resistance. Representative M2210A covers 50/100 N·m in a Φ53 OD x 7 mm, 0.09 kg body; M2210B covers 250 N·m at Φ100 x 8 mm, 0.37 kg; high-bending M2210B5 and RS485 digital variants (e.g. M2210A2A) are also offered. Applications include medical surgical robots, exoskeletons and collaborative robots.
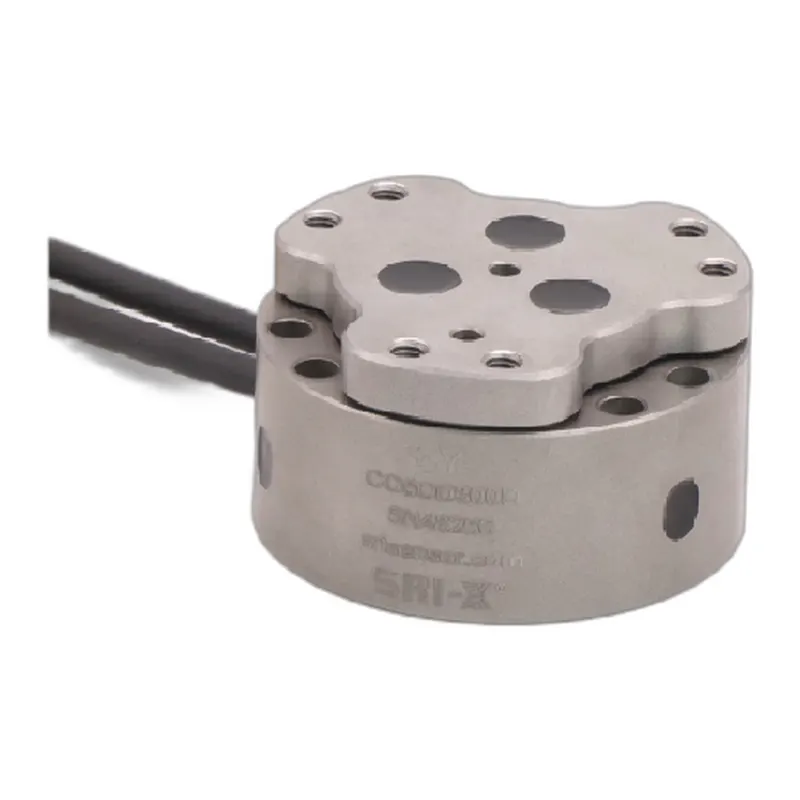
SRI Instruments (Qinhuangdao SRI, Yuli) is a leading Chinese six-axis force/torque sensor maker serving robotics, automotive safety, medical and general testing. The patented C25XX–C60XX series is purpose-built for humanoid-robot wrist mounting with low zero drift, high precision, isolated power supply, superior shock resistance and single-side mounting: accuracy better than 0.5% F.S. across the series, zero drift better than 0.1%/10 C on selected models, up to 3x overload with 100-cycle 3x-overload survival per axis. Ranges span Fx/Fy/Fz 50–600 N (extra-thin Fz up to 1000 N) and Mx/My/Mz 5–40 N·m in OD 45–60 mm bodies as thin as 9.2 mm and as light as 0.03 kg, with EtherCAT (IN & OUT), Ethernet TCP/IP, CAN, CAN FD, RS485, RS232 and USB interfaces for humanoid wrist/ankle six-axis perception and joint force control.
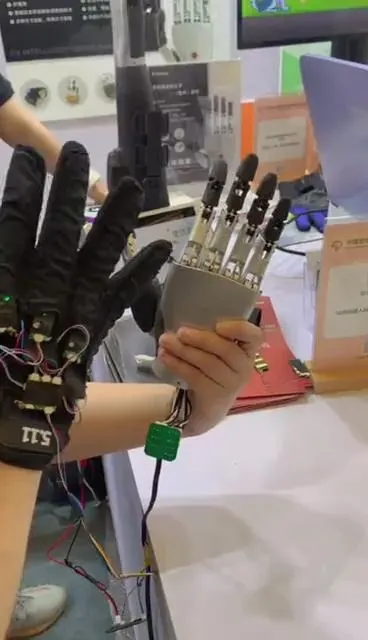
Ti5 Robot's Cool-Hand bionic hand combines bionics, mechatronics, materials, biomedicine and IT with proprietary somatosensory control and flexible-actuator torque algorithms for graded force and coordinated fine manipulation. Six actuator units drive each finger independently with a two-axis thumb: 6 DoF, 5 joints, only 480 g; 10 N per fingertip and 12 N thumb force; palm 80 mm, max width 132 mm, length 205 mm, finger 97 mm; DC 12V +/-10%, 200 mA idle / 3 A max, RS485 (plus Bluetooth on BT version), 90 deg thumb lateral rotation and 0-6000 steps/s finger swing (1024 steps per 90 deg).
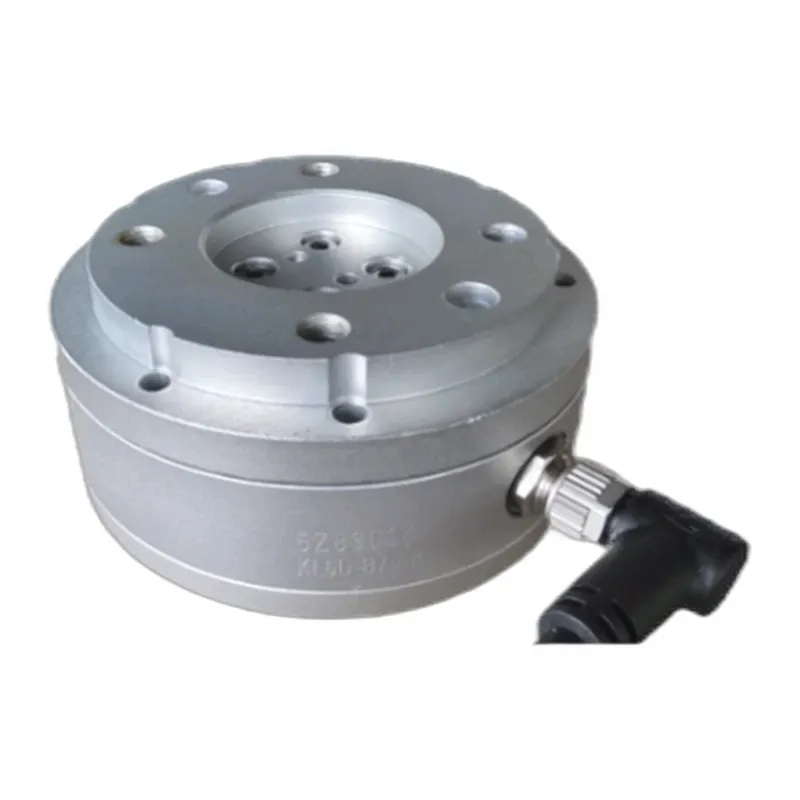
The Keli Sensing JTS/NJ-K joint torque sensors target robot-arm joint torque detection with strain-gauge precision: five ranges 50-250 N·m, sensitivity 1.3±0.2 mV/V, non-linearity ±0.5%FS, repeatability/creep ±0.1%FS, zero temp drift ±0.05%FS, IP65 sealing in alloy steel with a thin flange form (Φ72 OD, 7.2 mm thick), 300%FS safe / 500%FS ultimate overload and 5-10 V DC excitation - high torsional stiffness and strong overload resistance for cobot/industrial joint force control and test benches.
Keli Sensing (Ningbo Keli Sensing Technology, SSE 603662) is a leading Chinese force-sensor manufacturer. The KL6D/KL6F six-axis force/torque sensors use high-precision strain-gauge principle with four range tiers (Fx/Fy/Fz 100-700 N, Mx/My/Mz 4-18 N·m), RS485 digital output at 1000 Hz, non-linearity ±0.5%FS, crosstalk ±1%FS, repeatability/creep ±0.1%FS, IP65 sealing in aluminium alloy, 300%FS safe / 500%FS ultimate overload and 5-36 V DC excitation in a flange-mounted Φ75 x 42.5 mm body - suited to industrial arm force detection, automation and machine tools as well as humanoid wrist/ankle six-axis force perception.
Tamagawa Seiki (Japan) is the global leader in absolute encoders for servo and robot joints, its SmartAbs protocol being a de-facto industry standard. The SA-series multi-turn absolute encoders span five frame sizes SA35-SA135 (Φ35-Φ135) with 17-27 bit single-turn plus 16-bit multi-turn resolution, including battery-less self-generating models (TS5966N/TS5964N) and Oldham-coupling easy-install variants, up to 8,000 rpm, DC 5V line-driver output, sealing up to IP67, 10G vibration / 200G shock endurance and -10 to +105 C operation at only 0.03-1.5 kg, the mainstream position feedback for industrial, cobot and humanoid joint motors.
Yobotics' in-house hydraulic servo valve: 6 mm spool, 35/28 MPa working pressure, 4-40 L/min rated flow, <=10 ms step response, +/-0.1% control accuracy and >=130 Hz bandwidth - high-response, high-precision flow/pressure control for hydraulic arms and hydraulically actuated humanoid/quadruped joints.
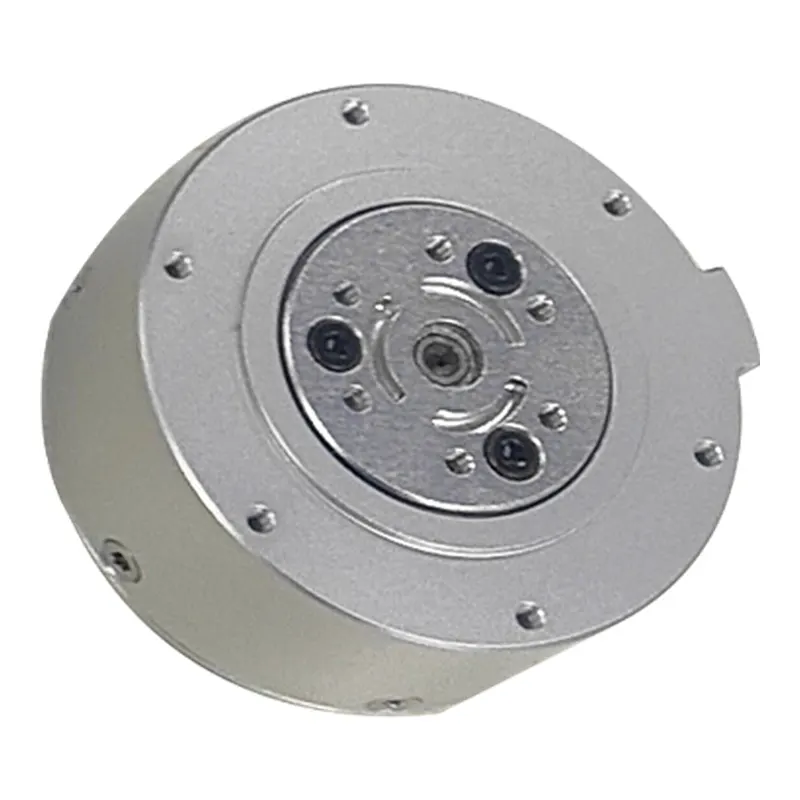
Yobotics' BM integrated joint module family spans M5/M24/M48/M144/M160/M200: 280 g-4700 g, 24/42/72 VDC, rated torque 5.5-60 N.m and peak 12-200 N.m, CAN 1 Mbps bus, dual absolute 14-bit encoders with power-off position memory - BLDC motor plus reducer in one unit for quadruped/humanoid robots, cobots and exoskeletons.