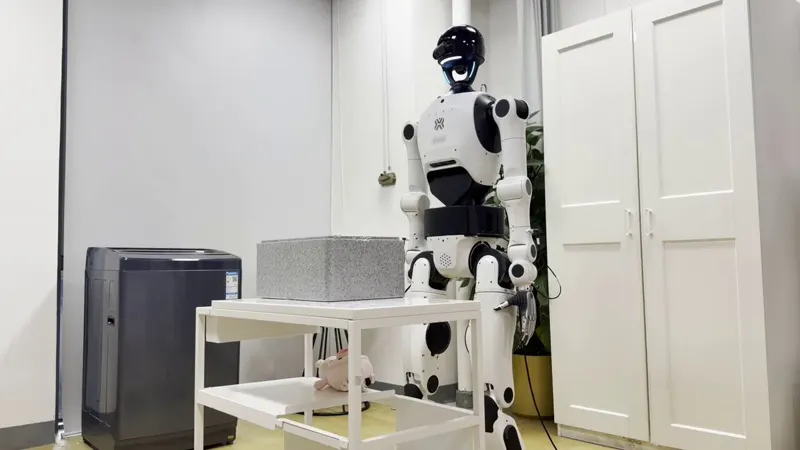
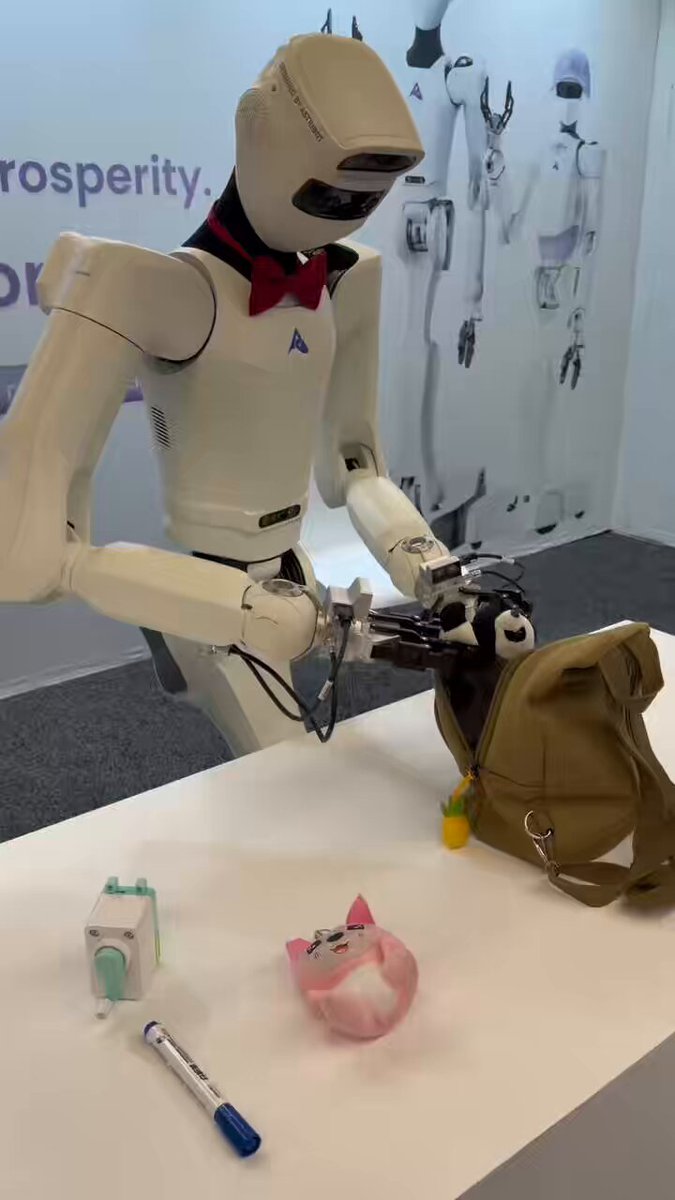
IROS 2026 floor demo: Astribot S1 repeatedly picks and places items from a soft bag
Loading video
Loading videoFilmed at IROS 2026 by Japanese ML researcher Rego (@FluffyHernia): an Astribot S1 humanoid endlessly takes items out of and puts them back into a soft fabric bag. Soft-bag pick-and-place is a classic manipulation stress test - fabric occlusion hides the target, its shape keeps shifting, and tactile feedback plus adaptive grasp strategies are required. Astribot’s approach is whole-body teleoperation data collection plus visuomotor policy learning (Astribot Suite, arXiv:2507.17141), and this seemingly boring task is a direct demonstration of that generalization.
Category: humanoid
Author: @FluffyHernia
Date: 2026-09-28T00:00:00
Duration: 6.666s
Reference: https://arxiv.org/abs/2507.17141