Whole-Body UMI: Humanoid Whole-Body Manipulation from UMI Data
Loading video
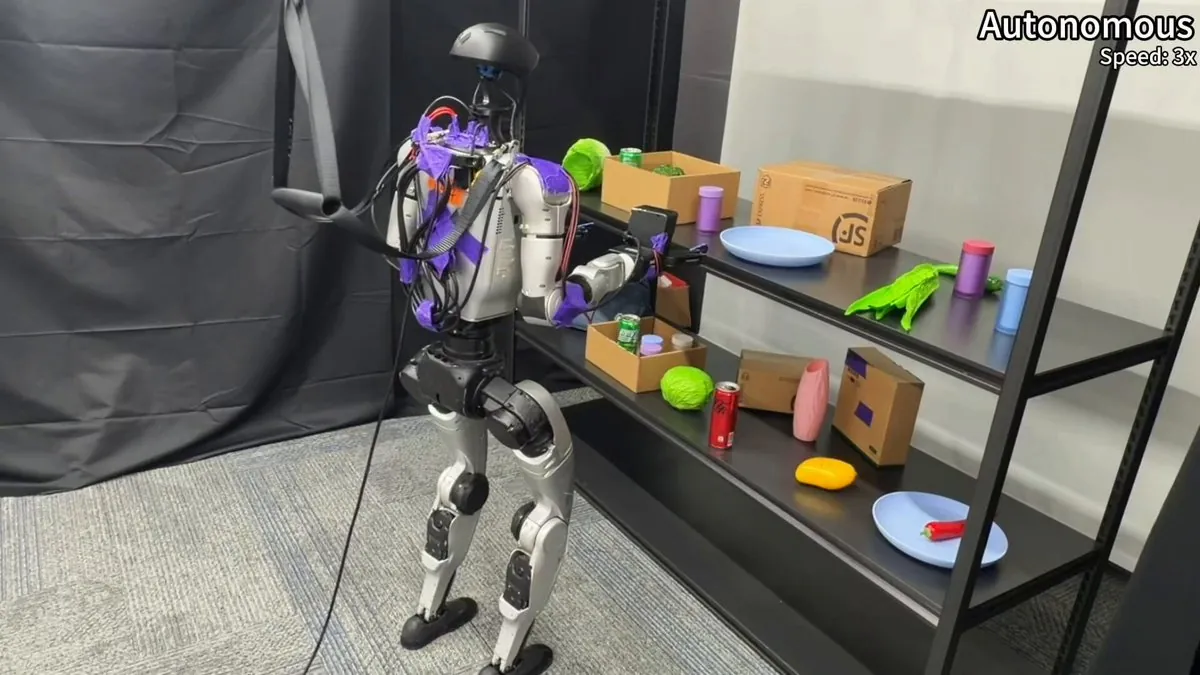
Loading videoWhole-Body UMI transfers UMI manipulation skills to humanoid whole-body control: a diffusion policy over native UMI demos plus a mocap-trained motion prior generates task-agnostic end-effector-conditioned motion, reaching 90% drawer-closing and 80% shelf pick-place on a real Unitree G1 without task-specific whole-body demos.
Category: humanoid
Author: @ZhongyuLi4
Date: 2026-10-10T00:00:00
Duration: 148.212s
Reference: https://wholebody-umi.github.io/