Heave-Ho: Decentralized Multi-Humanoid Long-Horizon Collaboration
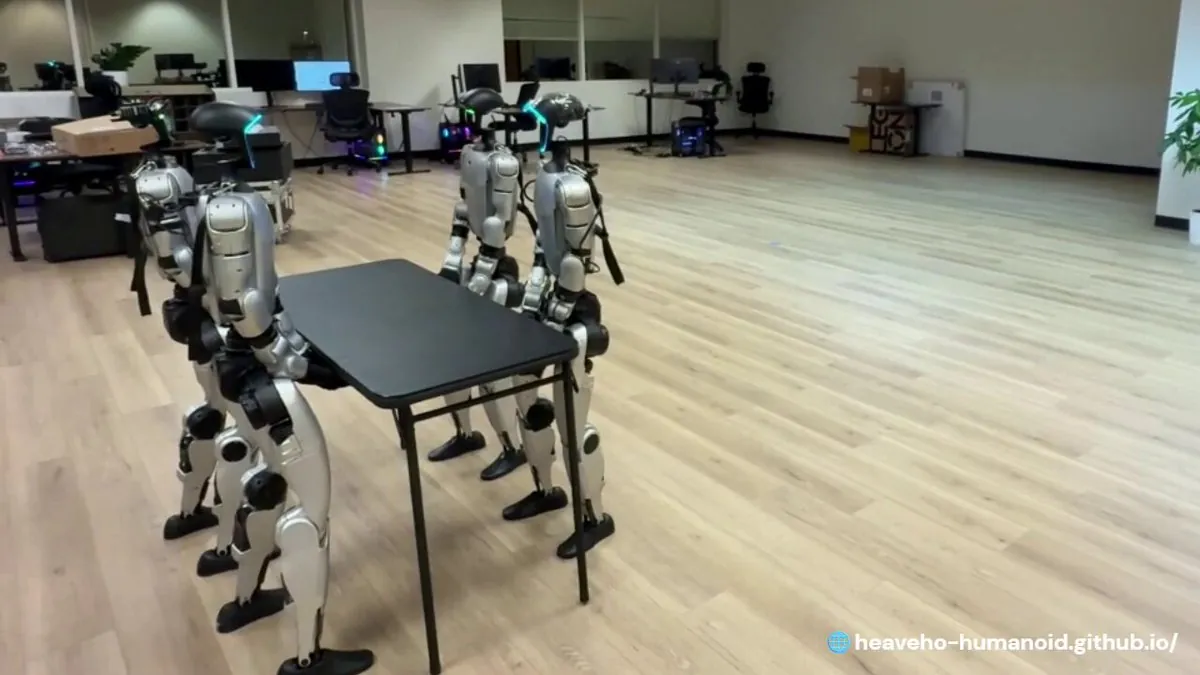
Loading video
Loading videoHeave-Ho combines two-robot whole-body post-training with speech-based leader-follower synchronization, scaling decentralized humanoid teams to ten robots for long-horizon loco-manipulation without inter-robot networking.
Humanoid robotsMulti-Robot CollaborationWhole-Body ControlDecentralized ControlSpeech CoordinationMobile ManipulationUSCVinMotionHeave-HoHumanoid
Category: humanoid
Author: @ZappyZappy7
Date: 2026-11-21T00:00:00
Duration: 112.2s
Reference: https://arxiv.org/abs/2611.22275