GeoFlow-SLAM: A Robust Tightly-Coupled RGBD-Inertial and Legged Odometry Fusion SLAM for Dynamic Legged Robotics
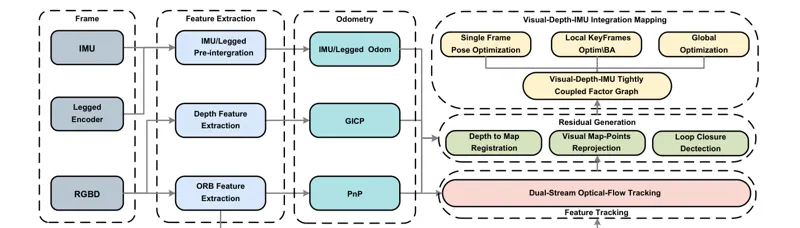
GeoFlow-SLAM (Horizon Robotics, IROS 2025) targets three stacked failure modes of quadruped localization: motion blur and IMU distortion from fast locomotion, and feature scarcity in texture-less scenes. Three interlocking contributions: dual-stream optical-flow tracking aided by prior map points and poses (a 3D-to-2D reprojection stream plus a 2D-to-2D fallback stream); a pose-initialization priority chain degrading from leg odometry to IMU, PnP, GICP, and finally a constant-velocity model; and a tightly-coupled optimization framework placing depth-to-map point-to-plane and GICP relative-pose residuals alongside visual reprojection and IMU pre-integration in one factor graph. On four real Go2 sequences (office, texture-less corridor, underground parking, open plaza) it is the only method that succeeds on Seq2-4, with 88% improvement over VINS-RGBD on Seq1. ScanNet mean ATE 0.0779 m (~70% better than ORB-SLAM3), TUM 0.0129 m; global plane-feature maps are still built in the structure-less texture-less TUM extremes. Code and data are open source (HorizonRobotics/GeoFlowSlam).
Xiao, Tingyang, Zhou, Xiaolin, Liu, Liu · 643 views · Mar 18, 2025
SLAMLocalization
Mar 18, 2025
 0:49