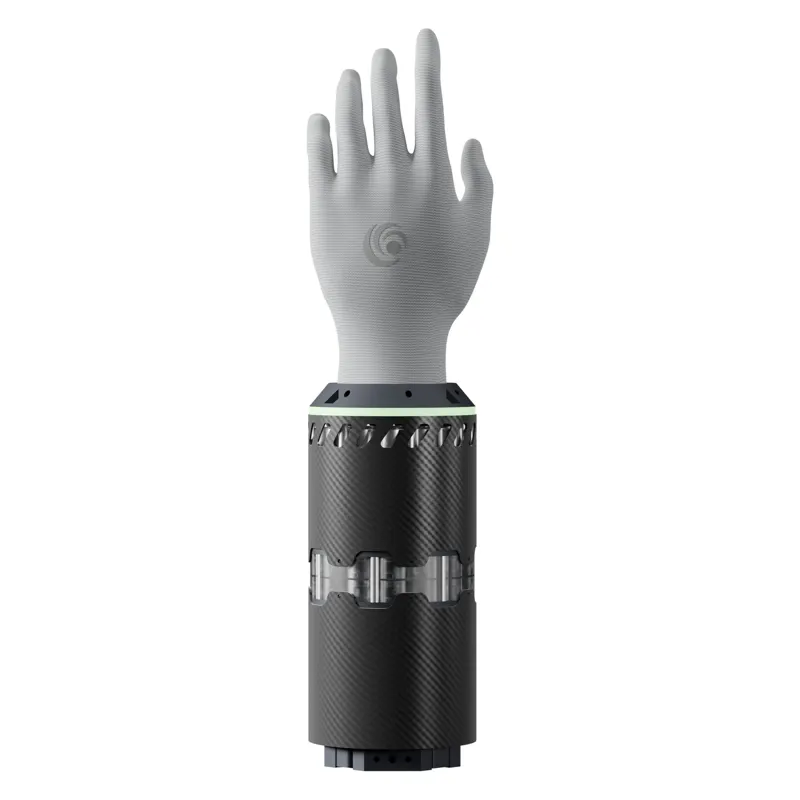
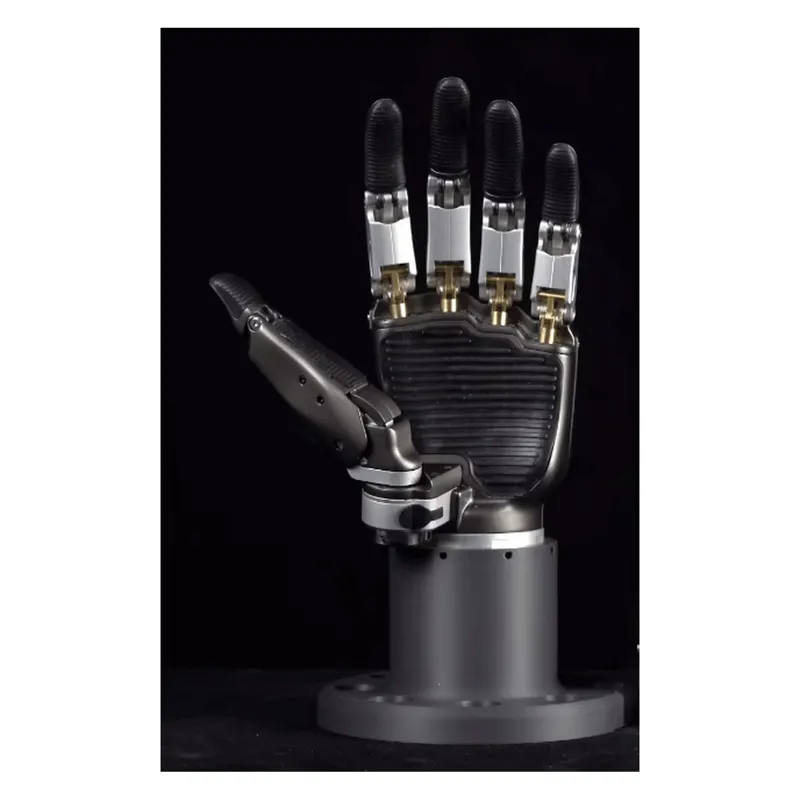
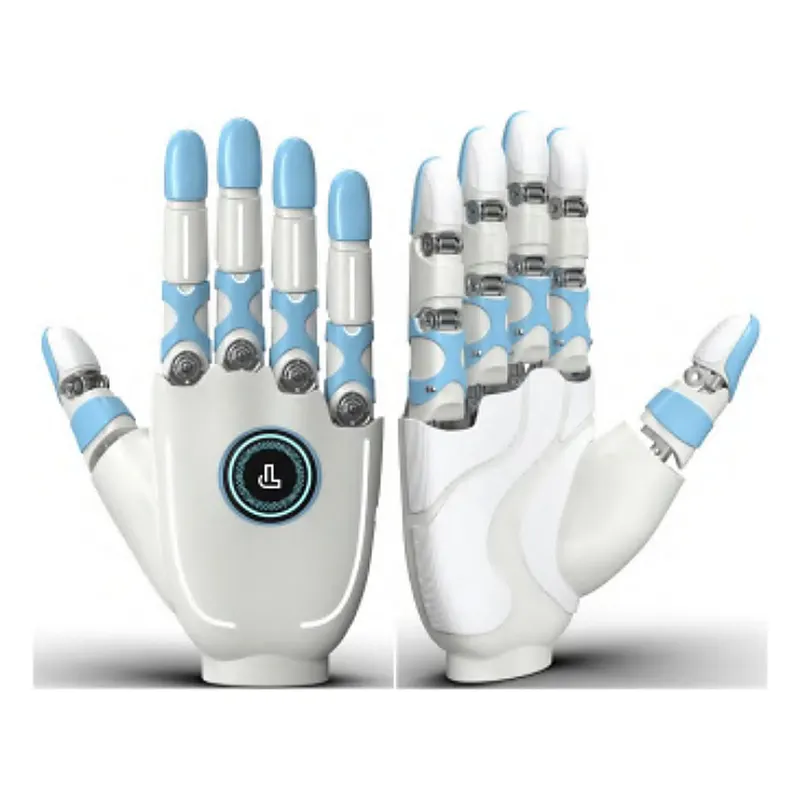
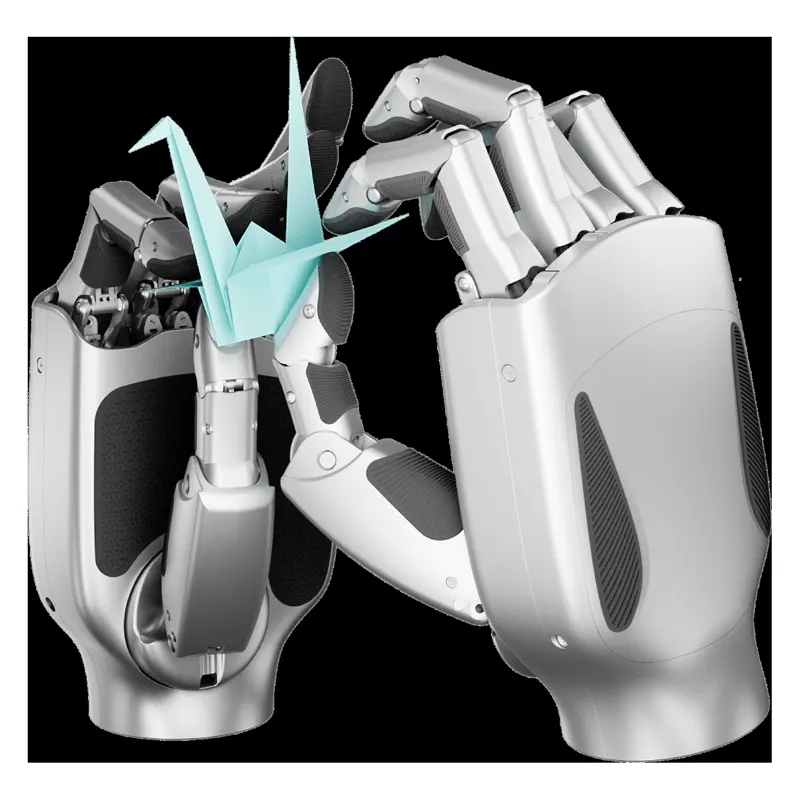
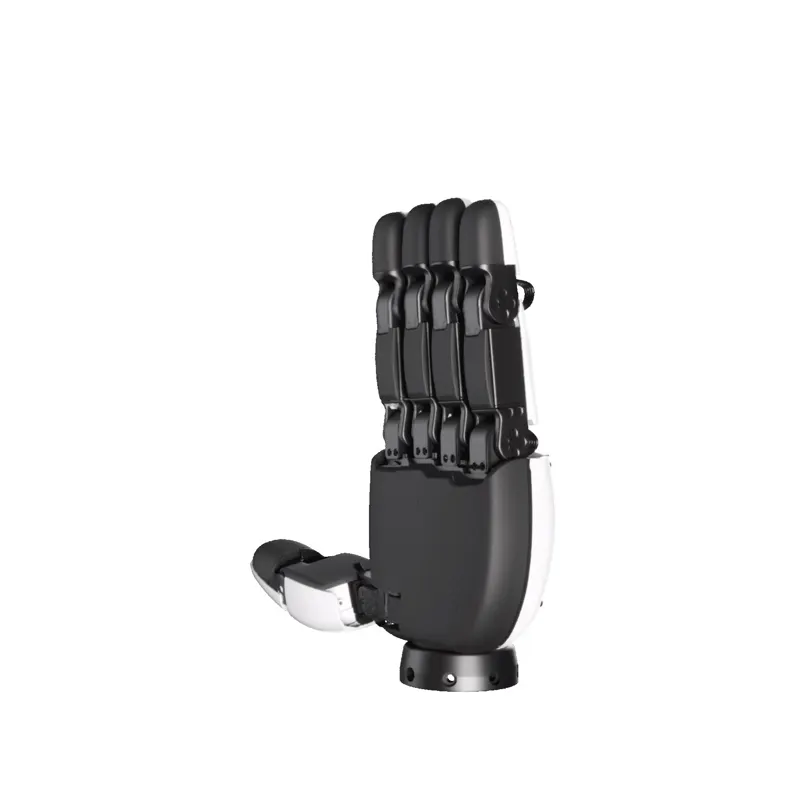
The Y-Hand M1 builds on Prof. Lei Ren's pioneering bionic tension-compression body robot theory: it replaces rigid hinges with joints capable of 3D 6-DOF motion, uses magnetic-collection electric-driven artificial muscles replicating human skeletal-muscle biomechanics, and a multi-layer rigid-flexible coupled design. With 38 whole-hand DOF it delivers 330 N grip (28.7 kg whole-hand grasp) and 180 N per-finger output; 0.2 s whole-hand close time; 0.04 mm fingertip positioning accuracy; and 59 mm/N finger compliance for safe, compliant physical interaction combining strength, speed, precision, dexterity and compliance.
The X-Hand M1 is Yuequan Bionic's rigid bionic dexterous hand: 11 joints with human-like hand size and segment proportions, a bionic palmar arch and ring-shaped oblique-axis design driven by a high power-density motor matrix. Strong and fast: 100 N five-finger grip and 30 N fingertip force, 40 kg whole-hand lift capacity at only 630 g; 0.4 s five-finger close time with ±0.1 mm fingertip repeatability. Sensitive perception via 472 tactile sensing units. Ethernet interface with CAN/RS485 customization; pairs with the X-Bot and W-Bot humanoids.
The Lumi-Dex-23 is the industrial-flagship dexterous hand from Zhejiang Shiyue Technology (Lumibot): 23 active DoF with a hybrid direct-drive + linkage actuation and integrated driver-controller, weighing only 850 g at 225 mm total length (98 mm four-finger palm width). The thumb yaws 90° to touch the little-fingertip; fingers bend MCP/PIP/DIP 90°/90°/70° with ±15° splay, thumb yaw speed up to 360°/s and bend 270°/s, four-finger bend 0.3 s/cycle. It delivers 20 N fingertip press, 40 N pinch and 80 N grip active force with a 25 kg passive load, stably grasping 10-50 mm cylindrical/spherical objects. Optional Lumi-Tac visuotactile fingertips (10 μm spatial resolution, 0.02 N force precision), DC12V power, RS485/CAN communication and replaceable four fingers target research, biopharma, 3C electronics, rail transit and automotive manipulation.
Ti5 Robot's Cool-Hand bionic hand combines bionics, mechatronics, materials, biomedicine and IT with proprietary somatosensory control and flexible-actuator torque algorithms for graded force and coordinated fine manipulation. Six actuator units drive each finger independently with a two-axis thumb: 6 DoF, 5 joints, only 480 g; 10 N per fingertip and 12 N thumb force; palm 80 mm, max width 132 mm, length 205 mm, finger 97 mm; DC 12V +/-10%, 200 mA idle / 3 A max, RS485 (plus Bluetooth on BT version), 90 deg thumb lateral rotation and 0-6000 steps/s finger swing (1024 steps per 90 deg).
LinkerHand L20 pairs 16 active + 5 passive DoF with a linkage drive in a ~1200 g hand rated for 20 kg; wide DC 24-48 V input at 0.3 A static / 1.8 A peak; ±0.20 mm repeatability, 15 N thumb and 20 N finger force with 100 N whole-hand grip and a 0.9 s closing cycle; CAN/RS485 control targets heavyweight grasping and industrial end-effectors on humanoids.
20-DoF / 15-actuator humanoid five-finger hand with 0.1-20 N (+/-0.1 N) fingertip force sensing, tendon drive, <1 s open-close, 3-5 kg payload, <1 kg weight, 1M-cycle life and ROS1/ROS2 SDK.
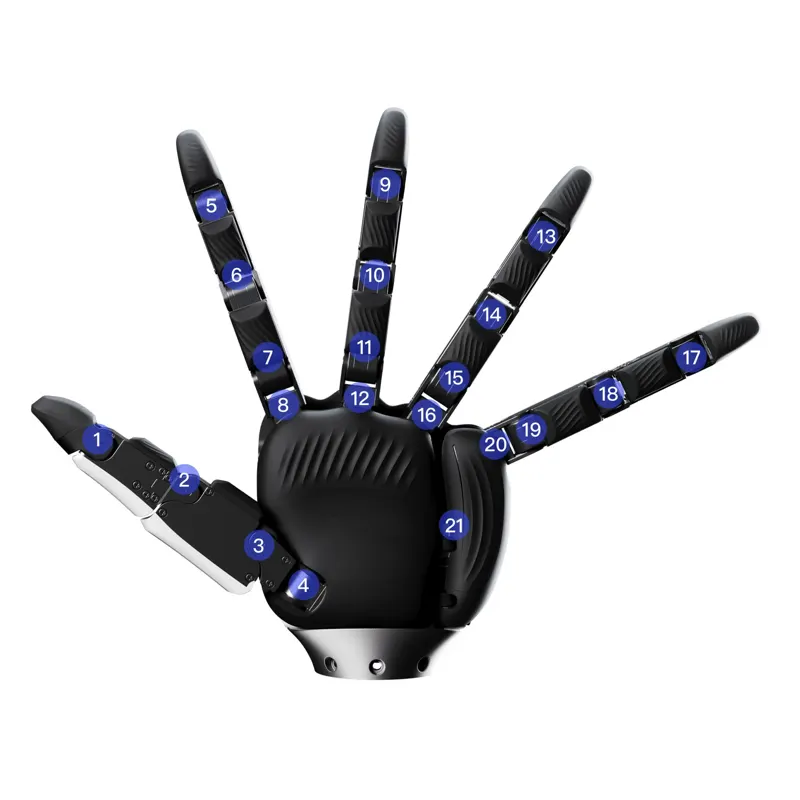
Flagship hand at 0.884 kg with 21 fully direct-driven and back-drivable active DoF, 160 mm maximum grasp diameter and 135° five-finger spread. 18 three-axis tactile sensors (5 fingertip, 10 finger-belly, 3 palm) cover 0.1-25 N at 0.01 N resolution with 10 mm proximity sensing; joint backlash under ±0.25 mm, ±0.1 mm repeatability, over 200k loaded cycles, above 5 Hz open-close and MIT, feedforward force, position and drag-teaching control modes.
Lightweight variant at 730 g with 6 active plus 5 passive DoF and linkage transmission, 12 N fingertip load, 12 mm minimum grasp diameter, ±0.20 mm repeatability, ≤0.1 N·s/m back-drivable damping, one million no-load cycles and EtherCAT 100 Mbps / RS485 3 Mbps links, aimed at teleoperation and data collection.
Fully direct-driven five-finger hand from RobotEra at 1100 g with 12 active DoF (thumb and index 3 each, others 2), ±0.20 mm fingertip repeatability, 5 kg+ per finger and 25 kg+ whole-hand lift. A 270° wrap-around tactile array with 120 points per finger at 0.05 N resolution returns three-axis force and temperature; 83 Hz whole-hand control rate, ≤0.1 N·s/m back-drivable damping and one million no-load cycles.
Lightweight five-finger dexterous hand from Agibot at ≤500 g with 10 active / 16 total DoF, 0.5 mm repeatability, 5 N typical fingertip force and 1 kg typical / 2 kg max palm-up load on a 5 cm rigid object; CANFD/RS485 interfaces, with 400+ tactile points on the tactile variant.
DexRobot hand for robotic manipulation and grasping research.
Sarcomere Dynamics high-DOF hand for teleoperation and research.