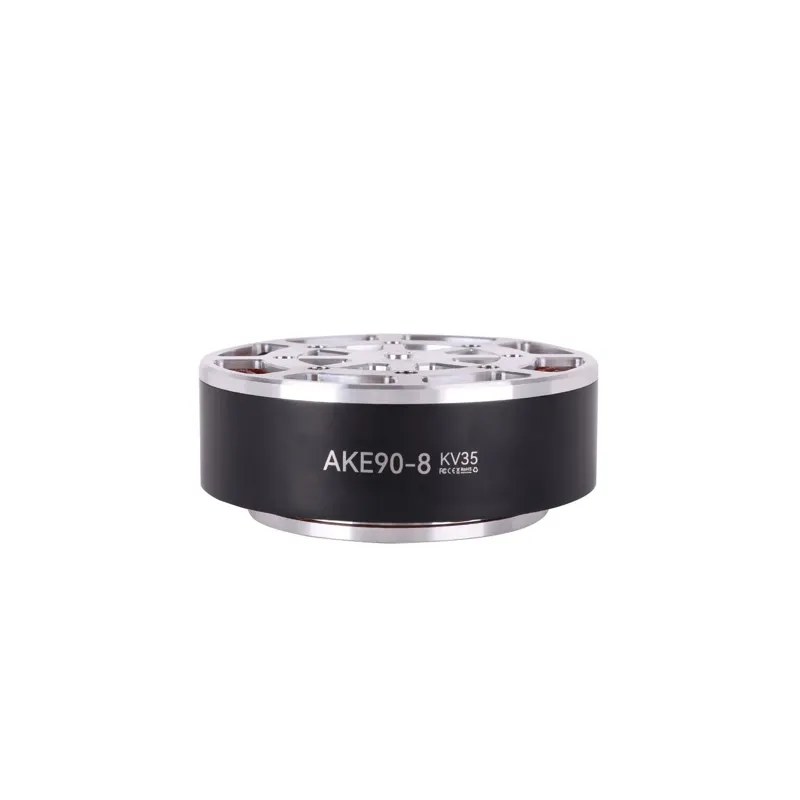
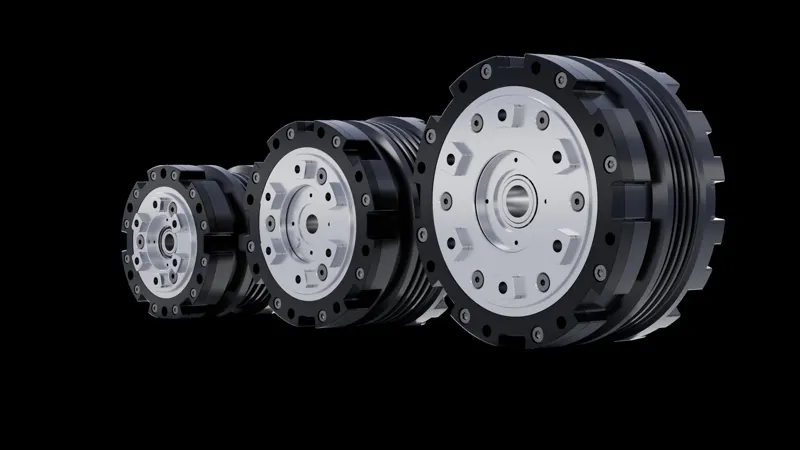
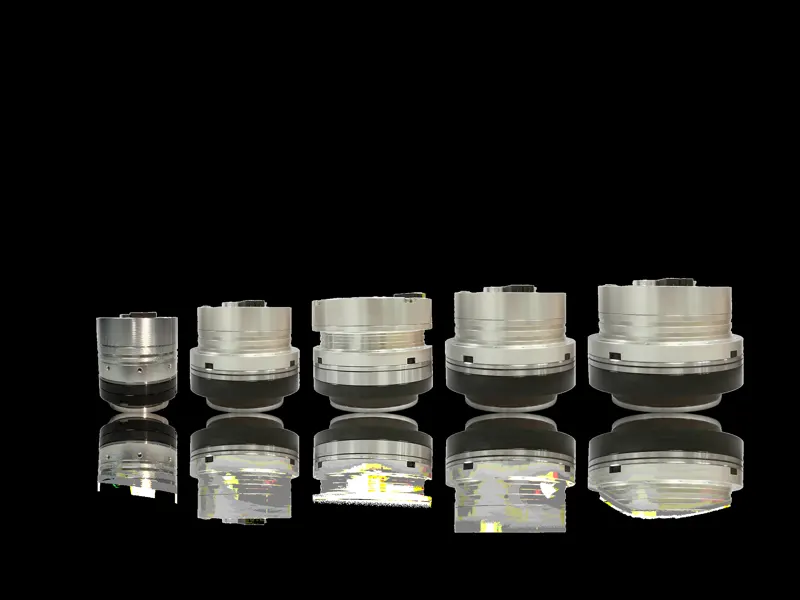
The AKE90-8 is a quasi-direct-drive (QDD) integrated joint actuator in the CubeMars AKE series: its low 8:1 ratio provides high back-drivability and impact tolerance, with 55 N·m rated and 170 N·m peak torque at 700 W rated power, 107.5 mm diameter and 1.4 kg. Dual-encoder closed loop, FOC and MIT mode, for humanoid large joints, quadruped robots and high-dynamic force-control scenarios.
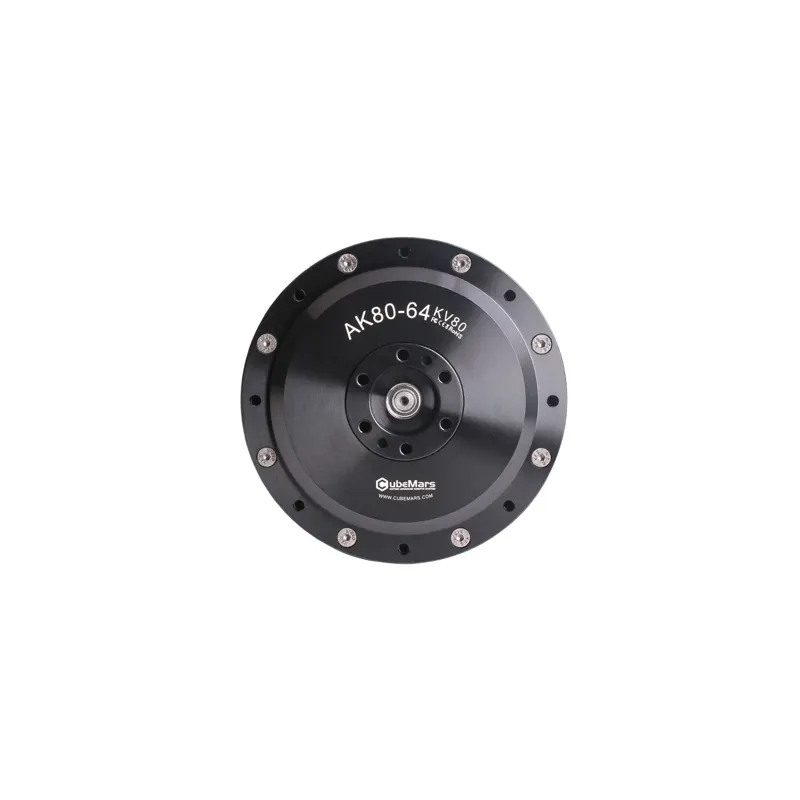
The AK80-64 delivers the highest peak torque in the CubeMars AK family: 64:1 high-ratio planetary transmission, 48 N·m rated and 120 N·m peak torque at 23/48 rpm rated speed, 98 mm diameter and 850 g. Brushless motor + driver integration, dual-encoder closed loop, FOC with MIT/servo dual modes, for heavy-load humanoid joints, legged-robot hips and base joints of heavy cobots.
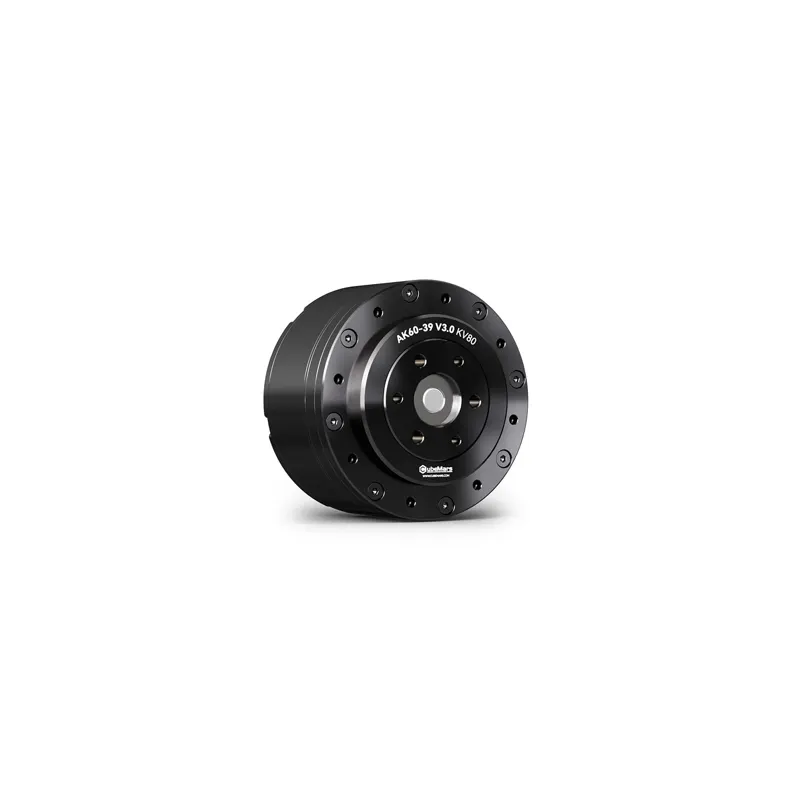
The AK60-39 V3.0 is a high-ratio integrated joint actuator from CubeMars: 39:1 planetary reduction, 24 N·m rated and 72 N·m peak torque at 70 rpm rated speed, 79 mm diameter and 750 g. Brushless motor + driver integration, dual-encoder closed loop, FOC with MIT/servo dual modes and over-current/voltage/temperature protection, targeting humanoid hip/knee/ankle joints needing high torque at low speed.
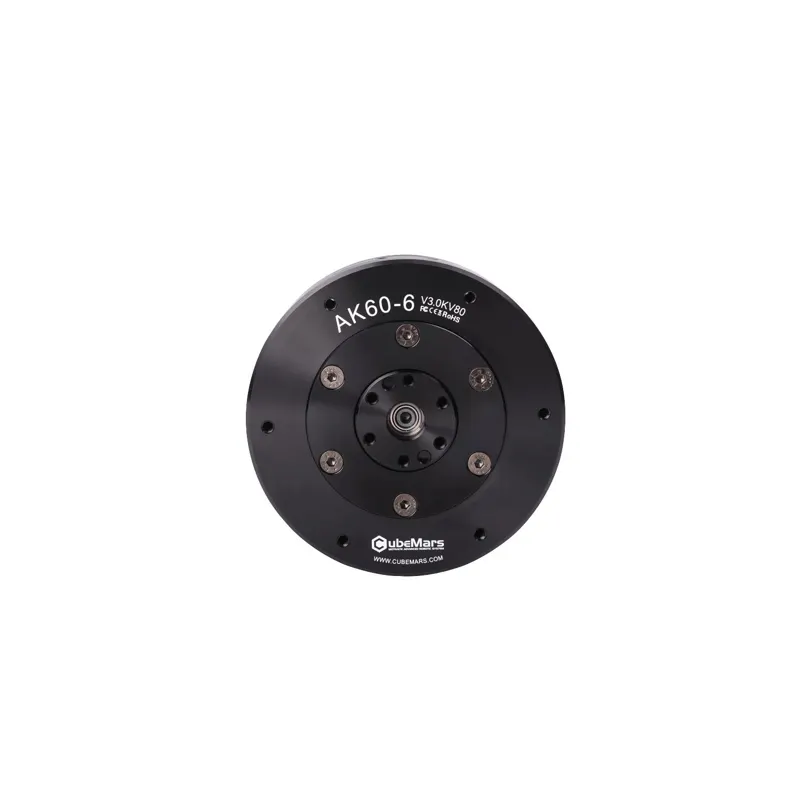
The AK60-6 V3.0 is a compact high-speed integrated joint actuator from CubeMars: only 79 mm in diameter and 380 g, with brushless motor + 6:1 planetary gearbox + driver, 3 N·m rated / 9 N·m peak torque at 24 V/48 V dual supply and 233/490 rpm rated speed. Dual-encoder closed loop, FOC and MIT/servo dual modes, for humanoid forearms/wrists, exoskeletons and light cobot joints.
The AK80-9 V3.0 is a high-speed integrated joint actuator from CubeMars: brushless motor + 9:1 planetary gearbox + driver in one, 9 N·m rated and 22 N·m peak torque with 390 rpm rated / 570 rpm no-load speed, weighing just 490 g. Dual-encoder closed loop, FOC, MIT/servo dual modes and multi-level electrical protection, for speed-sensitive light-load joints, wheeled robots and research actuators.
The AK70-9 V3.0 is a mid-size integrated joint actuator from CubeMars (a Sanrui Intelligent brand): brushless motor + 9:1 planetary gearbox + driver in one unit with dual-encoder closed loop, 8.5 N·m rated and 29.2 N·m peak torque at 260 rpm rated speed, weighing only 540 g with an 89 mm diameter. It supports MIT/servo dual modes and FOC control with over-current, over/under-voltage and over-temperature protection, for cobots, humanoid large joints and research platforms.
The AK10-9 V3.0 is an AK-series integrated joint actuator from CubeMars (Shenzhen), combining a brushless motor, 9:1 planetary gearbox and driver in one compact unit. It runs on 48 V with 18 N·m rated and 53 N·m peak torque, 235 rpm rated and 320 rpm no-load speed, 442 W rated power, weighing only 940 g at Φ98×61.7 mm. It supports speed/torque/position and MIT hybrid closed-loop modes with dual-encoder feedback, FOC control, built-in overcurrent, over/undervoltage and overheat protection, one-click parameter identification and servo/MIT mode switching, targeting collaborative arms, humanoid robot joints and research automation platforms.
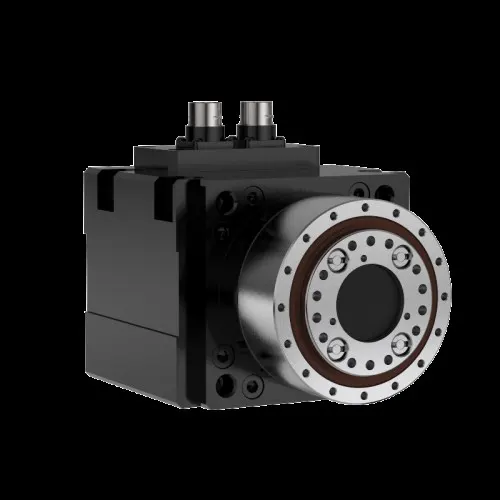
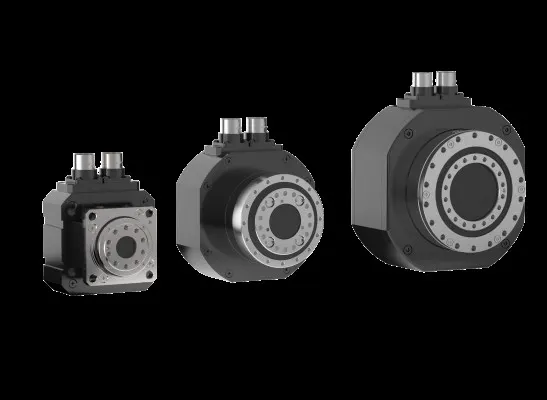
Integrated hollow-shaft rotary actuator with harmonic gear, servo motor and absolute encoder; sizes 14-40, peak torque 23-800 N·m, IP65.
PJ series planetary joint modules for humanoid locomotion joints: optimized reducer for high output and low noise. Example model: ratio 18, 90 N·m start/stop peak torque, 142 rpm rated, 10 arcsec backlash, 17-bit encoder, CAN bus, 105 mm OD with 50 mm through-hole, 0.83 kg.
HJ series harmonic joint modules: harmonic reducer plus fully hardware FOC on chip-level FPGA with 20 kHz triple-loop control. Top model delivers 194 N·m peak torque at ratio 101, 24-bit encoder, EtherCAT/CAN/CANFD, power-off brake and hollow wiring for humanoid joints.
SPINEA DriveSpin DSM is the modular variant of the DriveSpin family, combining a zero-backlash Twin Spin cycloidal gear with a servo motor in a modular package for flexible motor and interface configuration; four frames DSM 050/070/095/110 with 18-122 Nm rated output torque (DSM 070: 50 Nm rated, 100 Nm acceleration/braking), ratios 57/75, 2,000 rpm rated input. High positioning and repeat accuracy with strong torsional stiffness suit robot joints, precision turntables and industrial automation.
SPINEA (Slovakia, a Timken company) DriveSpin DSF is the flat low-profile variant of the DriveSpin family, integrating a zero-backlash Twin Spin cycloidal gear with a servo motor into a compact actuator with extremely short axial length; three frames DSF 050/070/095 with 12-85 Nm rated output torque (DSF 070: 50 Nm rated, 100 Nm acceleration/braking), ratios 57/75, 2,000 rpm rated input. The built-in bearing system gives high torsional stiffness and load capacity; low mass and small size suit robot joints, AGVs and medical devices with tight height constraints.