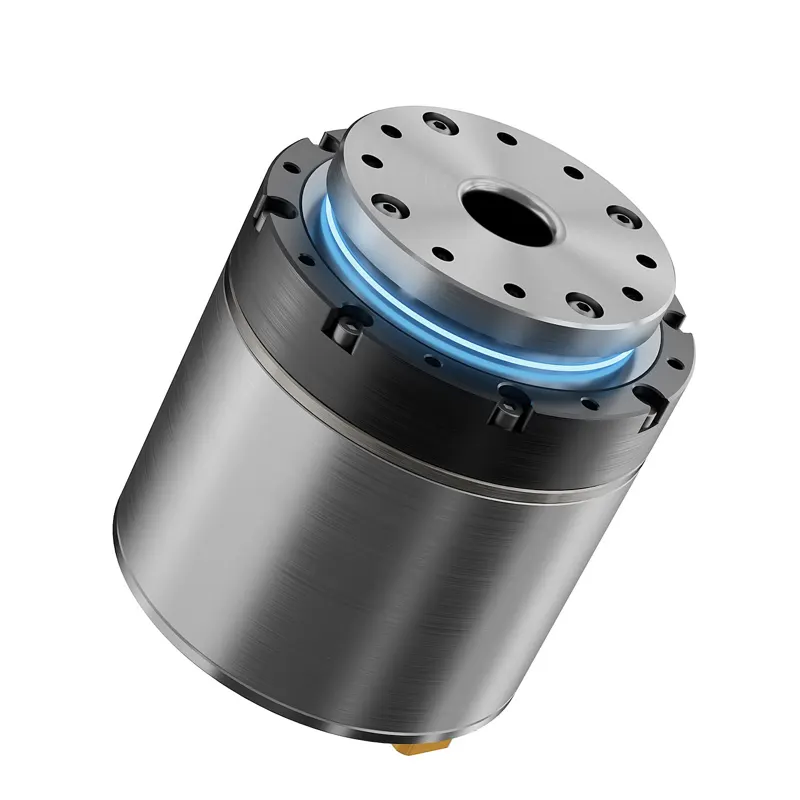
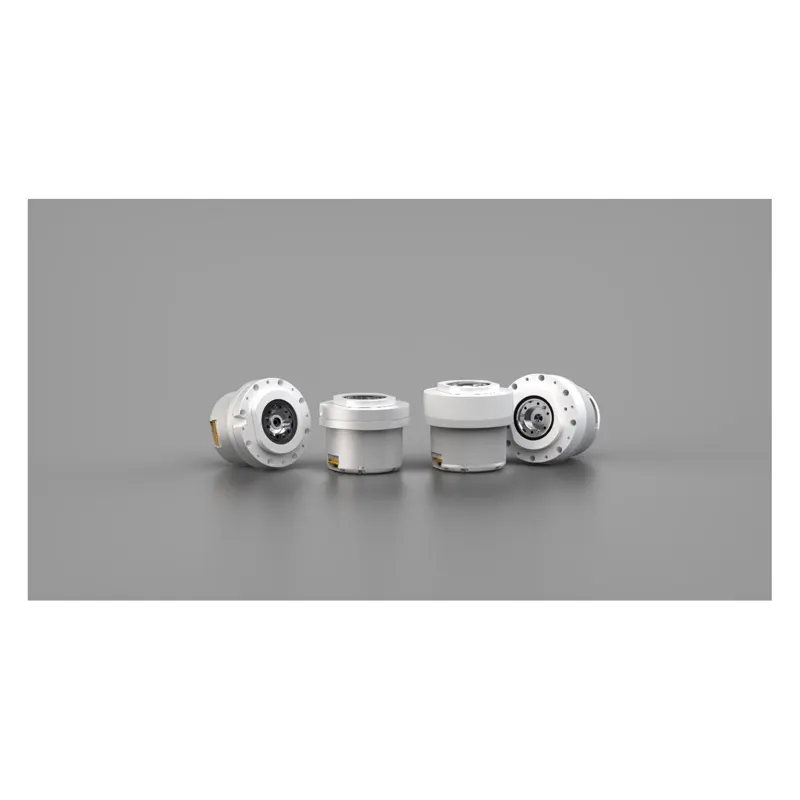
Integrated force-control joints combining an inner-rotor frameless torque motor, reducer, dual absolute encoders and a torque sensor; six sizes HSA-11 to 32 with 11-459 Nm peak torque, 100 Hz force loop, 32 kHz sampling and EtherCAT, delivering high torque density for humanoid and wheeled dual-arm robots.
Yobotics' BM integrated joint module family spans M5/M24/M48/M144/M160/M200: 280 g-4700 g, 24/42/72 VDC, rated torque 5.5-60 N.m and peak 12-200 N.m, CAN 1 Mbps bus, dual absolute 14-bit encoders with power-off position memory - BLDC motor plus reducer in one unit for quadruped/humanoid robots, cobots and exoskeletons.
RealMan's WHG high-performance joint modules span 10-360 N·m rated torque (WHG1410 to WHG32360) starting at only 800 g; each integrates an electromagnetic brake, dual encoders (16-bit incremental + 18-bit absolute) and a 9-18 mm hollow-bore through-wiring design, with CAN FD communication, 24/48 V supply, 100/160 reduction ratio and 0-50 °C operation for efficient integration into humanoid and other multi-axis systems.
MagicLab H70 harmonic integrated joint: φ70x96 mm at 900 g, 30 rpm rated at 48 V with 30 N.m rated / 96 N.m peak torque, 12 mm hollow bore, CAN / EtherCAT; built for humanoid and quadruped joints.
Laifual (03952.HK) DC low-voltage joint modules integrate a servo drive, frameless torque motor, dual absolute encoders (motor-side + output-side), precision harmonic reducer and safety brake in one unit; 48 VDC with CANopen / CAN FD / EtherCAT. Eight models L52I-L170I span 52-170 mm diameter and 0.55-9.48 kg, with 3.5-586 N·m rated and 11.5-1530 N·m peak torque at 51:1-161:1 ratios, targeting humanoid robots, cobots, medical devices and precision automation.
The HJ2 series from Shanghai Leadshine Robotics is a harmonic joint module family for humanoid robots with integrated motor, driver and encoder, a unified 101 reduction ratio and five frame sizes (52-110): 11-194 N·m start/stop peak torque and 8.9-133 N·m average load torque; the in-house FM2 frameless torque motor cuts heat by 25%, a 24-bit encoder and EtherCAT bus enable precise control, and the design is 65% lighter and 20% smaller for humanoid limbs, waist and neck joints.
The MJBX series from Techsoft Robots (Shenzhen Techsoft Intelligent Robot Co., Ltd.) is a force-controlled rotary joint module family for humanoid robots, integrating a harmonic reducer, optional 1-axis torque sensor, driver, dual encoders, motor and permanent-magnet brake; four frame sizes span 70/80/90/110 mm diameters at 0.84-2.3 kg, with 13.5-133 N·m average load torque, 376 N·m peak instantaneous torque, 80 rpm max speed and <60 arcsec repeatability; 48 V supply, 17-bit absolute encoder, EtherCAT/CANopen, IP40, 20,000 h reducer life, OEM/ODM available for rapid humanoid, bipedal and heavy bionic robot builds.
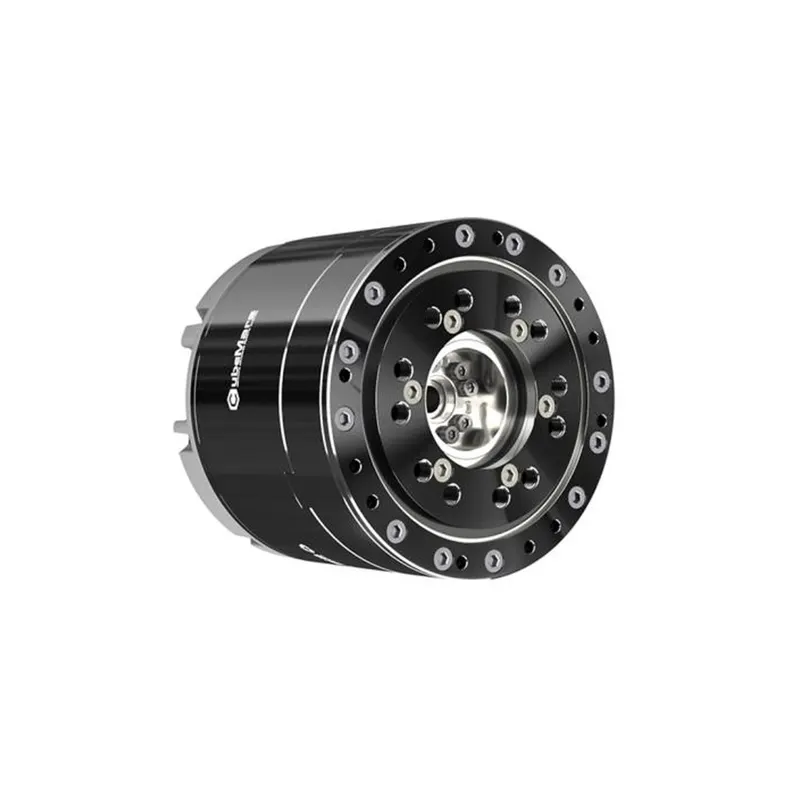
High torque-density integrated joint from CubeMars (Sanrui Intelligent) for humanoids and exoskeletons: 74 N·m rated / 222 N·m peak at only 1396 g (159 N·m/kg); 48:1 planetary reduction with 7 mm hollow bore, dual 21-bit magnetic encoders, integrated FOC driver, dual CAN, 48 V at 6 A rated / 18 A peak, 28 RPM rated, 12 arcmin backlash, listed at CNY 4888.
Integrated joint combining reducer, frameless torque motor, servo driver and 14-bit absolute encoder; mass-produced on the Lite3 quadruped and built for humanoid development. J60-10 reaches 56.48 Nm/kg torque-to-weight with temperature protection and CAN/serial tooling.
Integrated motor+reducer+encoder smart joint, plug-and-play.