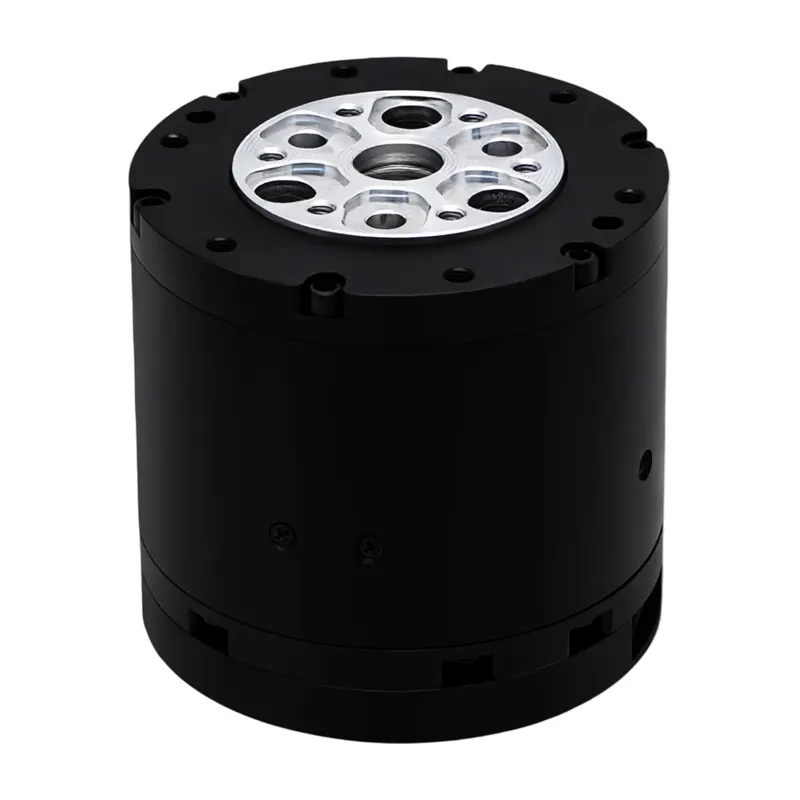
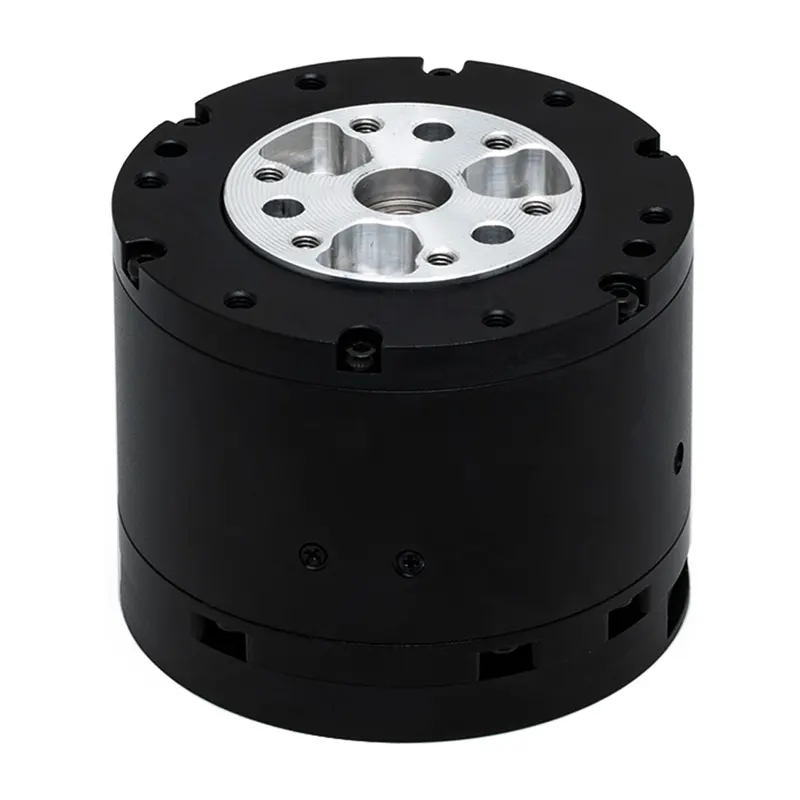
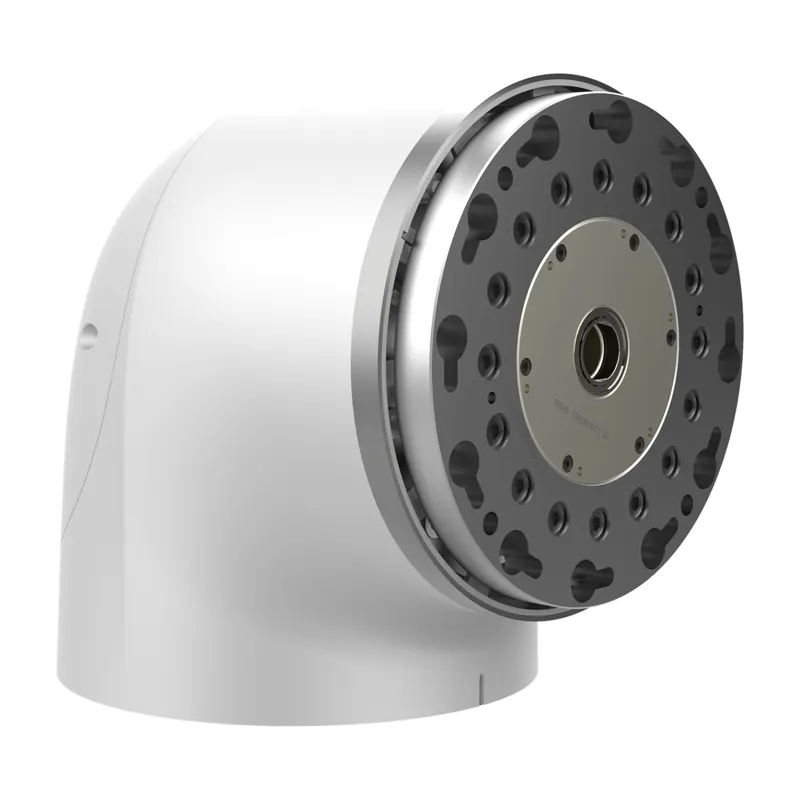
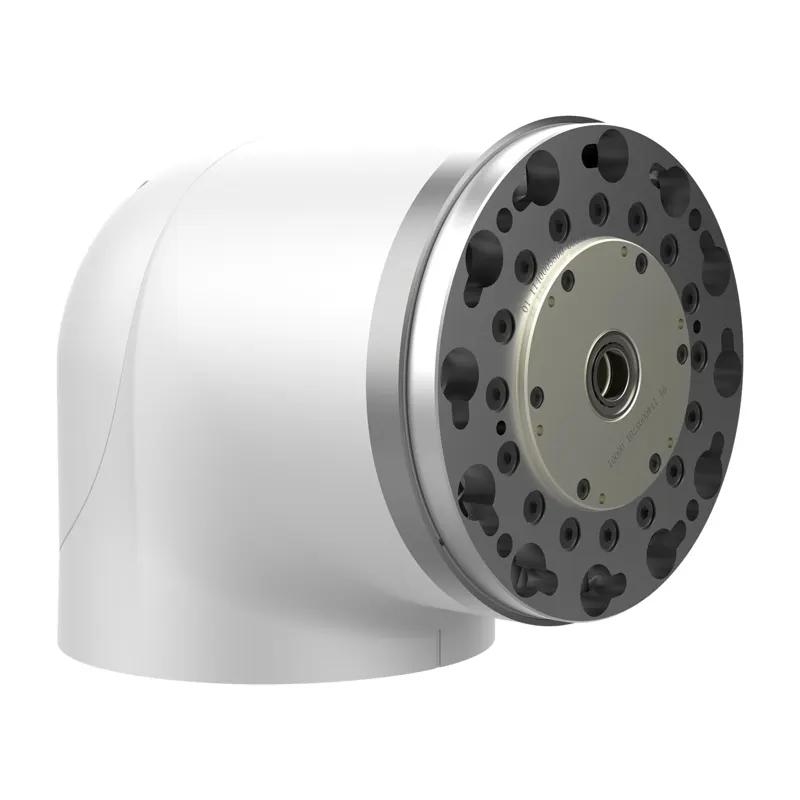
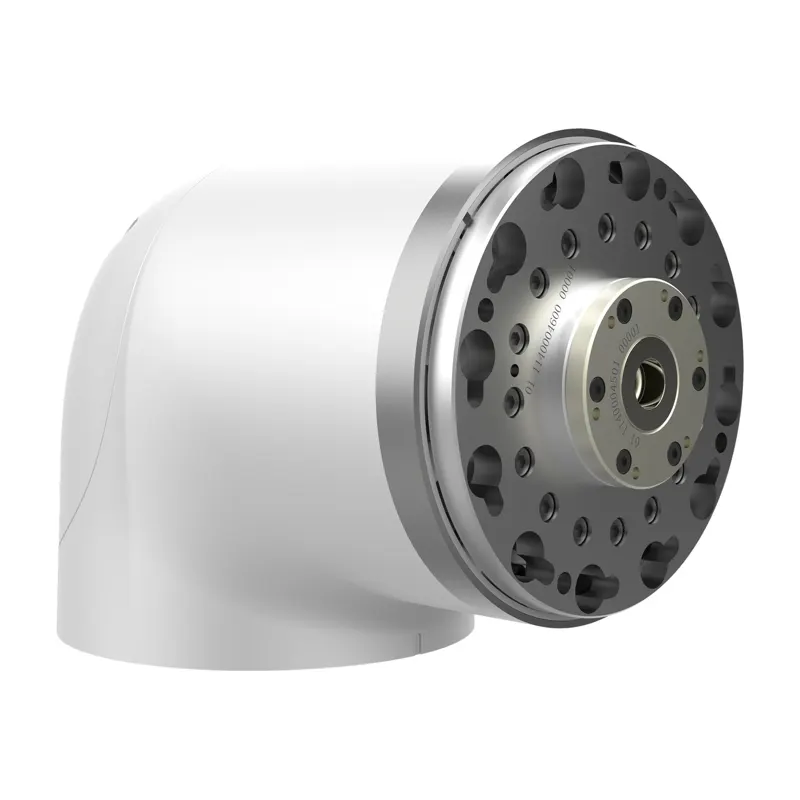
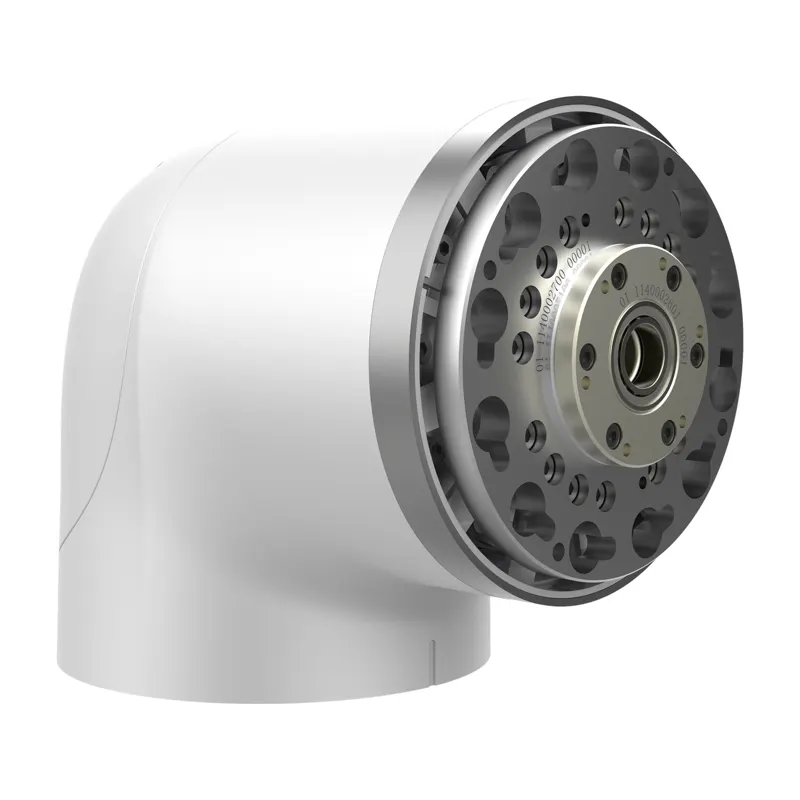
DaMiao DM-J4340-2EC V1.1 planetary joint module: rated torque 9 N·m, peak 27 N·m, rated speed 210 deg/s, max 500 deg/s, ratio 40:1. CAN @1Mbps, 16-bit mag encoder. 24V/48V dual voltage. Joint height 65mm, 850g, 12mm hollow shaft. For medium-load, high-dynamic-response robot joints.
DaMiao DM-J4310-2EC V1.2 lightweight planetary joint module: rated torque 3.5 N·m, peak 12.5 N·m, rated speed 200 deg/s, max 420 deg/s, ratio 10:1. 24V/48V dual voltage options. CAN @1Mbps, 16-bit mag encoder. Joint height 45mm, only 510g, 12mm hollow shaft. Featured in Huggingface Lerobot standard kit. For light robot arms, quadruped robots, and dexterous hands.
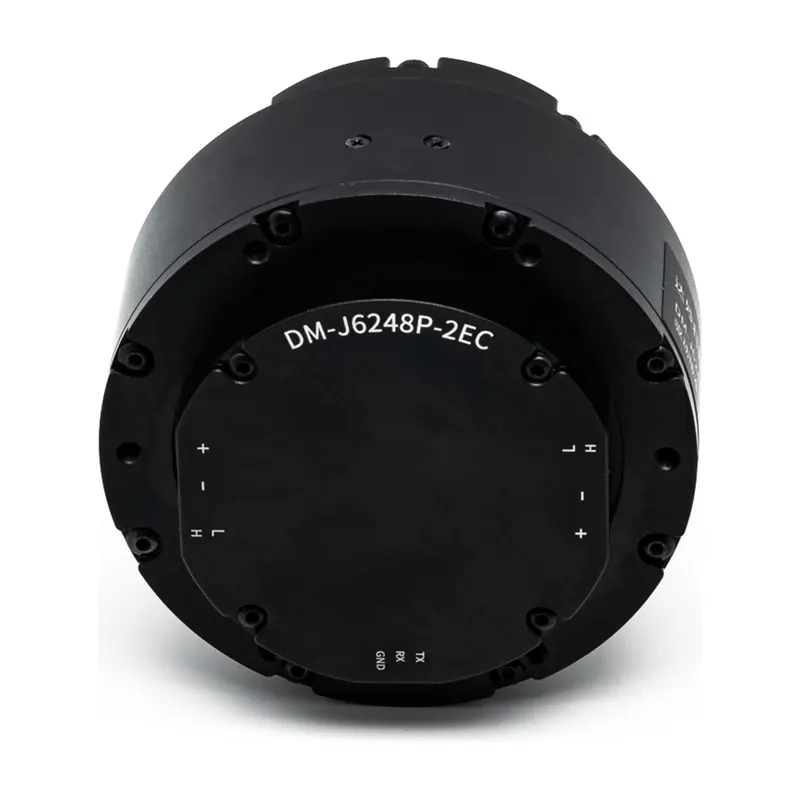
DaMiao DM-J6248P-2EC high-torque planetary joint module: rated torque 30 N·m, peak 97 N·m, rated speed 30 deg/s, max 75 deg/s, ratio 48:1. CAN @5Mbps, 16-bit mag encoder. 24V supply, joint height 82mm, 17mm hollow shaft, 2250g, radial 4000N / axial 2500N. For heavy-duty, low-speed robot joints.
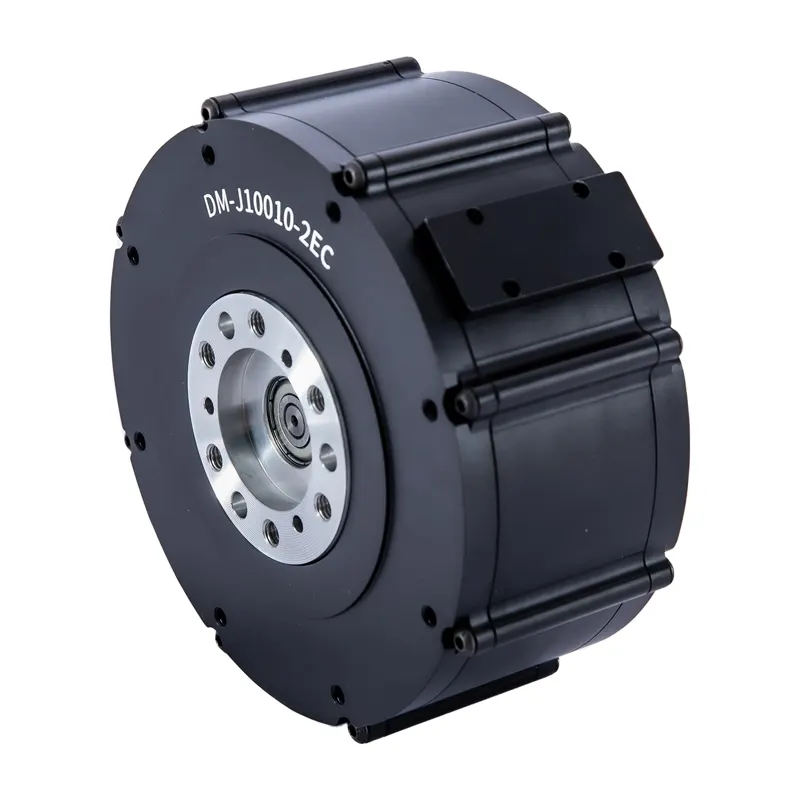
DaMiao DM-J10010-2EC planetary joint module: rated torque 40 N·m, peak 150 N·m, rated speed 150 deg/s, max 300 deg/s, ratio 10:1. CAN @1Mbps, 14-bit mag encoder. 48V supply, joint height 81mm, 14mm hollow shaft, 2650g, radial 4000N / axial 2500N load. For high-load humanoid robot joints.
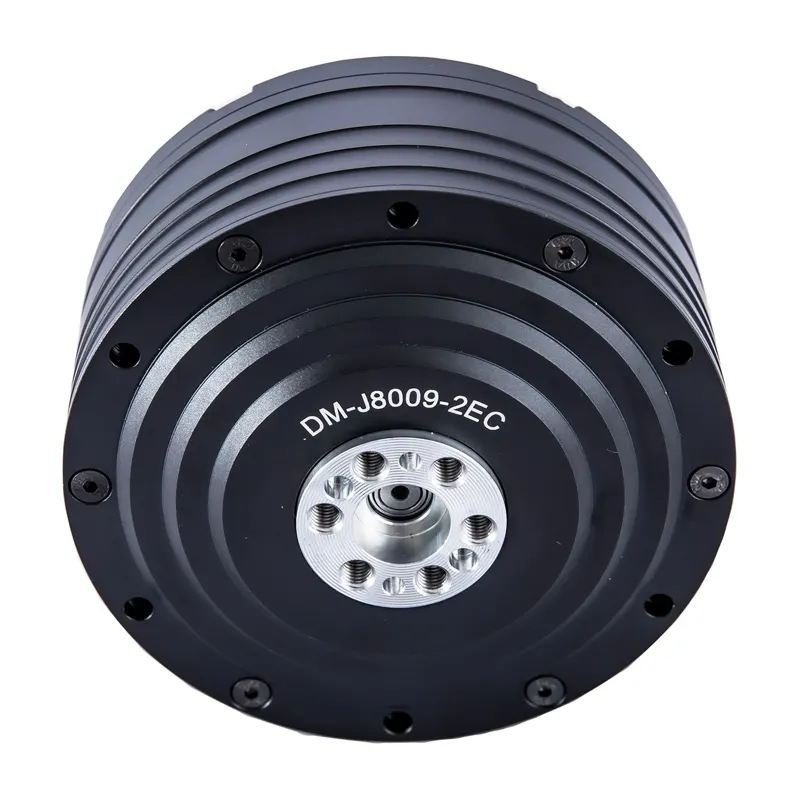
DaMiao DM-J8009-2EC planetary joint module: rated torque 20 N·m, peak 40 N·m, rated speed 150 deg/s, max 300 deg/s, ratio 9:1. CAN @1Mbps, 14-bit mag encoder. 24V supply, joint height 66mm, 14mm hollow shaft, 1600g, radial 2500N / axial 1500N load. For medium-high load robot joints.
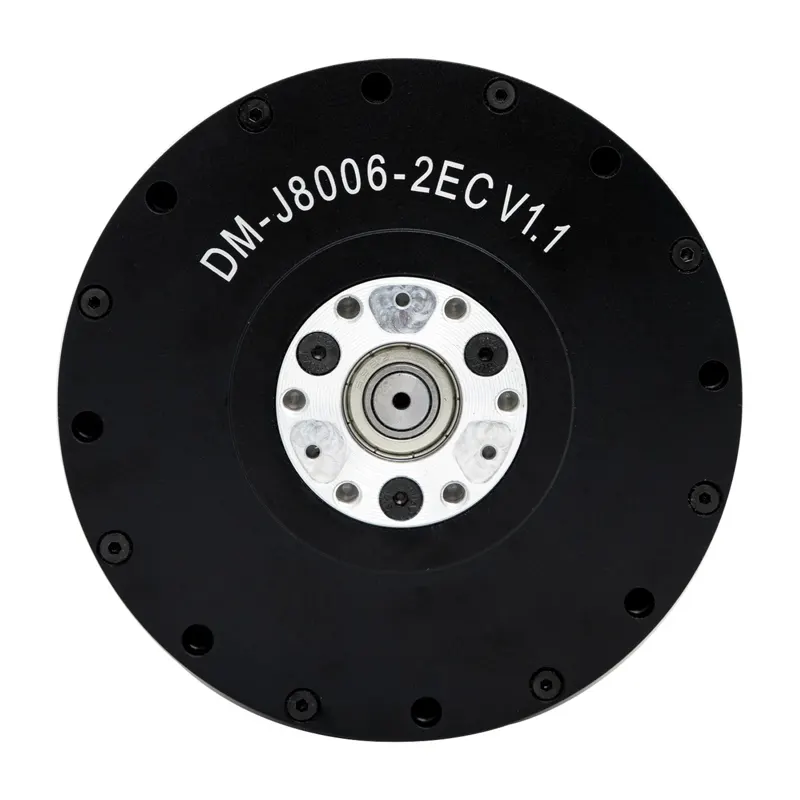
DaMiao DM-J8006-2EC V1.1 planetary joint module: rated torque 8 N·m, peak 20 N·m, rated speed 150 deg/s, max 360 deg/s, ratio ~6:1. CAN @1Mbps, 14-bit mag encoder. 24V supply, joint height 56.5mm, 14mm hollow shaft, 1150g, radial 2500N / axial 1500N load. For medium-duty robot joints.
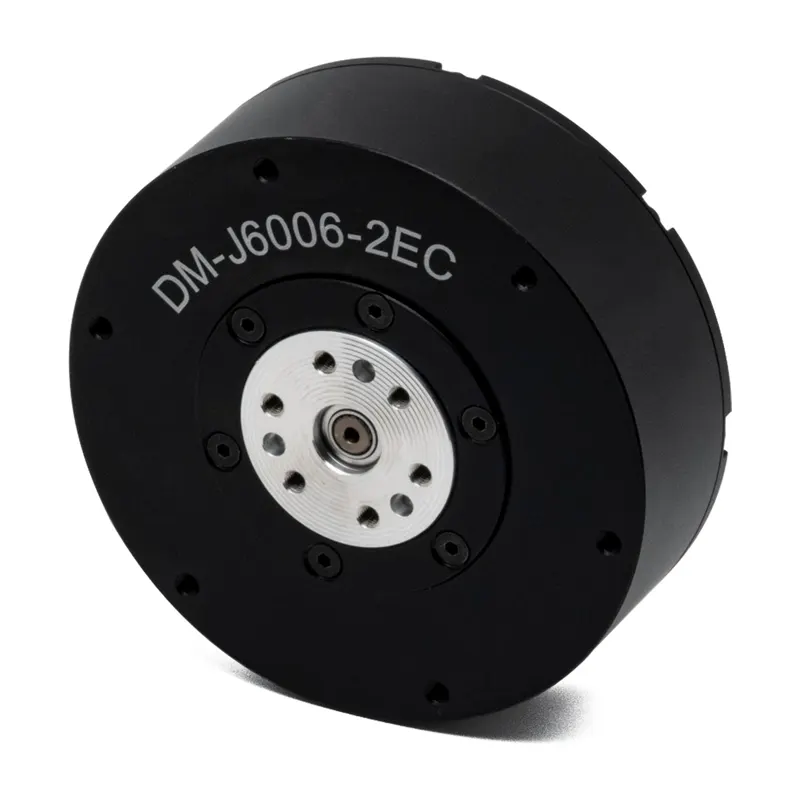
DaMiao Technology (DJI veterans team) DM-J6006-2EC planetary joint module: rated torque 4 N·m, peak 11 N·m, rated speed 210 deg/s, max 600 deg/s, ratio ~6:1. Integrated BLDC + planetary gearbox + driver + dual encoder. CAN @1Mbps, 14-bit mag encoder (single-turn). 24V supply (24-48V), joint height 43mm, 12mm hollow shaft, 580g weight, radial 1500N / axial 1000N load. For lightweight arms, biomimetic robots, and science competitions.
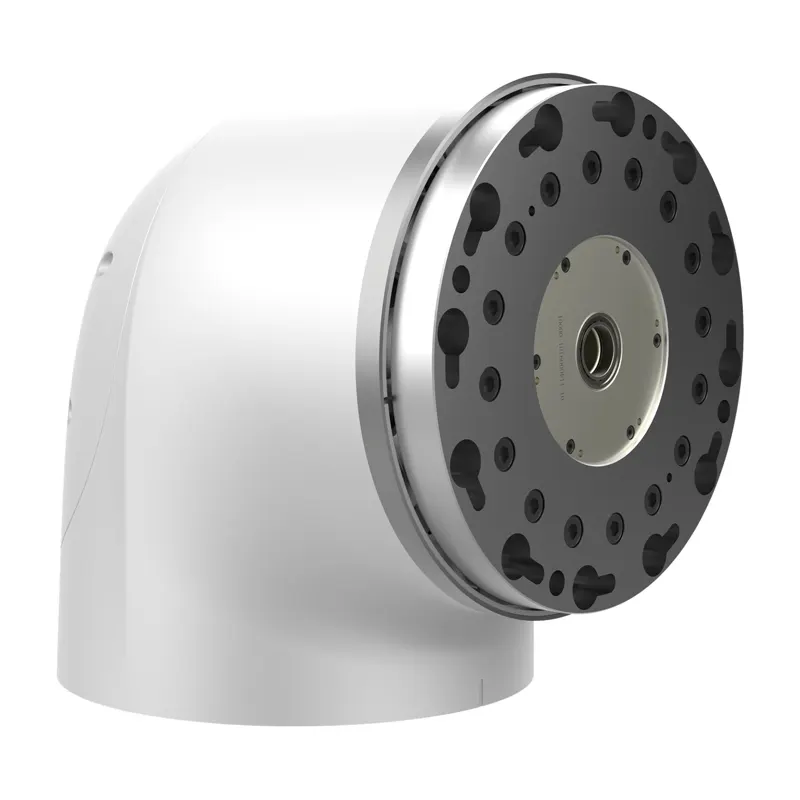
ESTUN Codroid (embodied-AI arm of ESTUN) SA-series rigid joint module SA40: rated torque 382 N·m, start/stop max 841 N·m, instantaneous peak 1530 N·m, rated speed 18.6 RPM. Integrates driver, dual encoders, harmonic reducer, torque sensor, motor and electromagnetic brake in one unit; ratio 161, 16mm hollow shaft, dual 19-bit absolute magnetic encoders, EtherCAT/CiA402, 48VDC, IP54, ±0.01° positioning. Built for collaborative and humanoid robots, suited for heavy-duty joints (hip/waist).
ESTUN Codroid (embodied-AI arm of ESTUN) SA-series rigid joint module SA32: rated torque 178 N·m, start/stop max 459 N·m, instantaneous peak 892 N·m, rated speed 24.7 RPM. Integrates driver, dual encoders, harmonic reducer, torque sensor, motor and electromagnetic brake in one unit; ratio 121, 16mm hollow shaft, dual 19-bit absolute magnetic encoders, EtherCAT/CiA402, 48VDC, IP54, ±0.01° positioning. Built for collaborative and humanoid robots, suited for large joints (hip/shoulder).
ESTUN Codroid (embodied-AI arm of ESTUN) SA-series rigid joint module SA25: rated torque 87 N·m, start/stop max 217 N·m, instantaneous peak 395 N·m, rated speed 28.9 RPM. Integrates driver, dual encoders, harmonic reducer, torque sensor, motor and electromagnetic brake in one unit; ratio 121, 12mm hollow shaft, dual 19-bit absolute magnetic encoders, EtherCAT/CiA402, 48VDC, IP54, ±0.01° positioning. Built for collaborative and humanoid robots, suited for medium-large joints (elbow/knee).
ESTUN Codroid (embodied-AI arm of ESTUN) SA-series rigid joint module SA20: rated torque 52 N·m, start/stop max 107 N·m, instantaneous peak 191 N·m, rated speed 34.6 RPM. Integrates driver, dual encoders, harmonic reducer, torque sensor, motor and electromagnetic brake in one unit; ratio 101, 8mm hollow shaft, dual 19-bit absolute magnetic encoders, EtherCAT/CiA402, 48VDC, IP54, ±0.01° positioning. Built for collaborative and humanoid robots, suited for medium joints.
ESTUN Codroid (embodied-AI arm of ESTUN) SA-series rigid joint module SA17: rated torque 31 N·m, start/stop max 70 N·m, instantaneous peak 143 N·m, rated speed 34.6 RPM. Integrates driver, dual encoders, harmonic reducer, torque sensor, motor and electromagnetic brake in one unit; ratio 101, 11mm hollow shaft, dual 19-bit absolute magnetic encoders, EtherCAT/CiA402, 48VDC, IP54, ±0.01° positioning. Built for collaborative and humanoid robots, suited for small-to-medium joints.