100 Unitree G1s in one MuJoCo world: kung-fu tracking on a real 360-scanned plaza
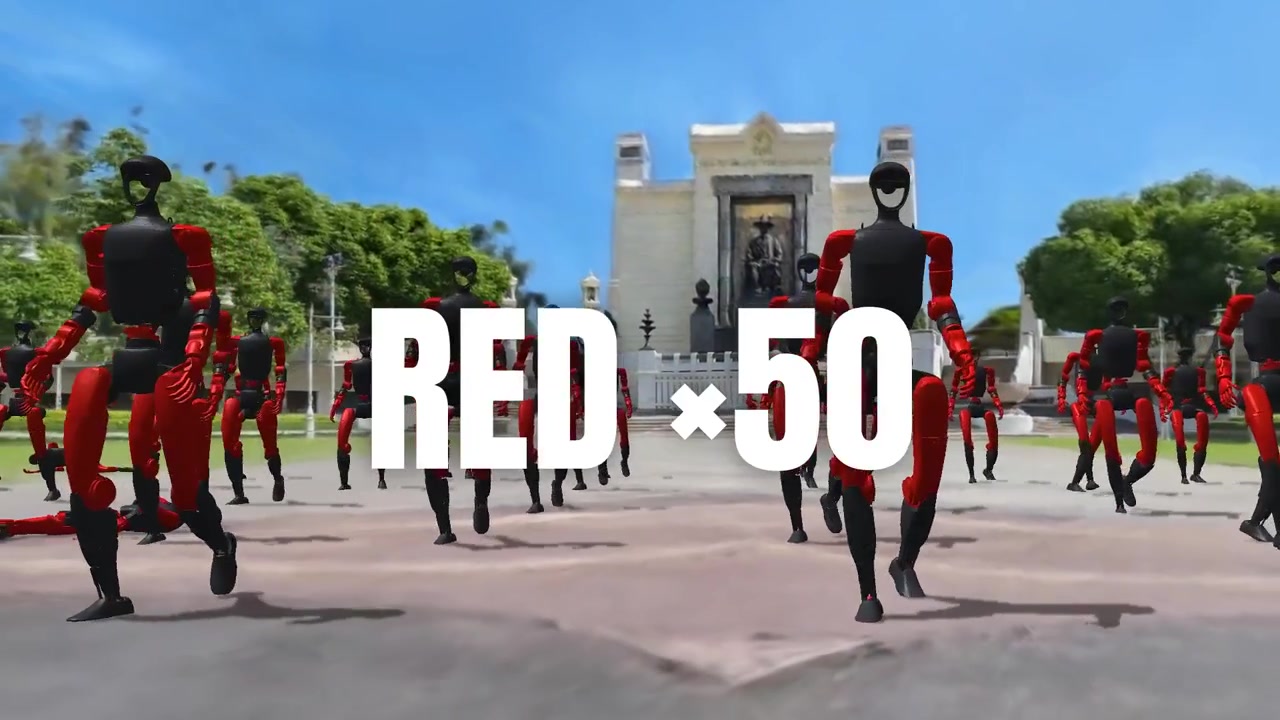
Davide Cuttini, CEO of Over The Reality, shows 100 Unitree G1 humanoids in a single MuJoCo world tracking kung-fu motions with a pretrained whole-body policy, on a plaza reconstructed from a real 360-degree scan. Contacts, knockdowns and pile-ups all come from real physics. The pitch: sim-to-real starts with real environments - OVER crowdscans locations via smartphones and 360 cameras (174k+ locations, 86.8M images) and exports USDZ assets pairing a photorealistic Gaussian splat (vision) with a collision-ready mesh (physics) at true metric scale, importable into Isaac Sim/MuJoCo, so pixels and physics are anchored to the same real place to close the sim-to-real gap. Relevant both to multi-robot policy validation and simulation data infrastructure.