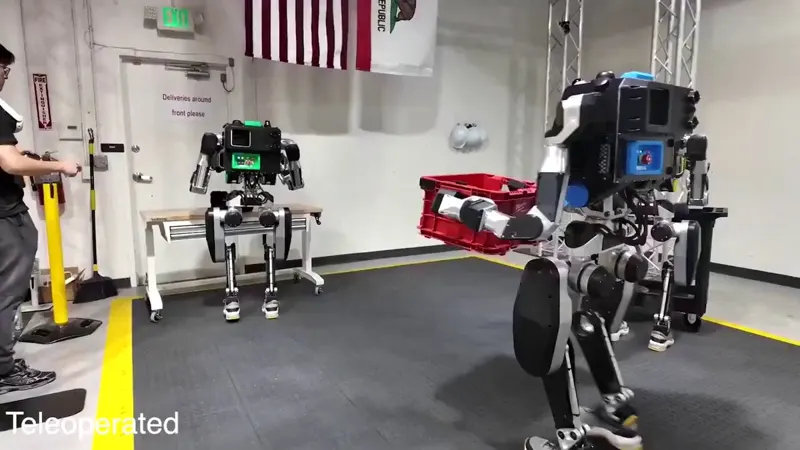
ORCS Releases a Humanoid Whole-Body Controller Toolkit
Loading video
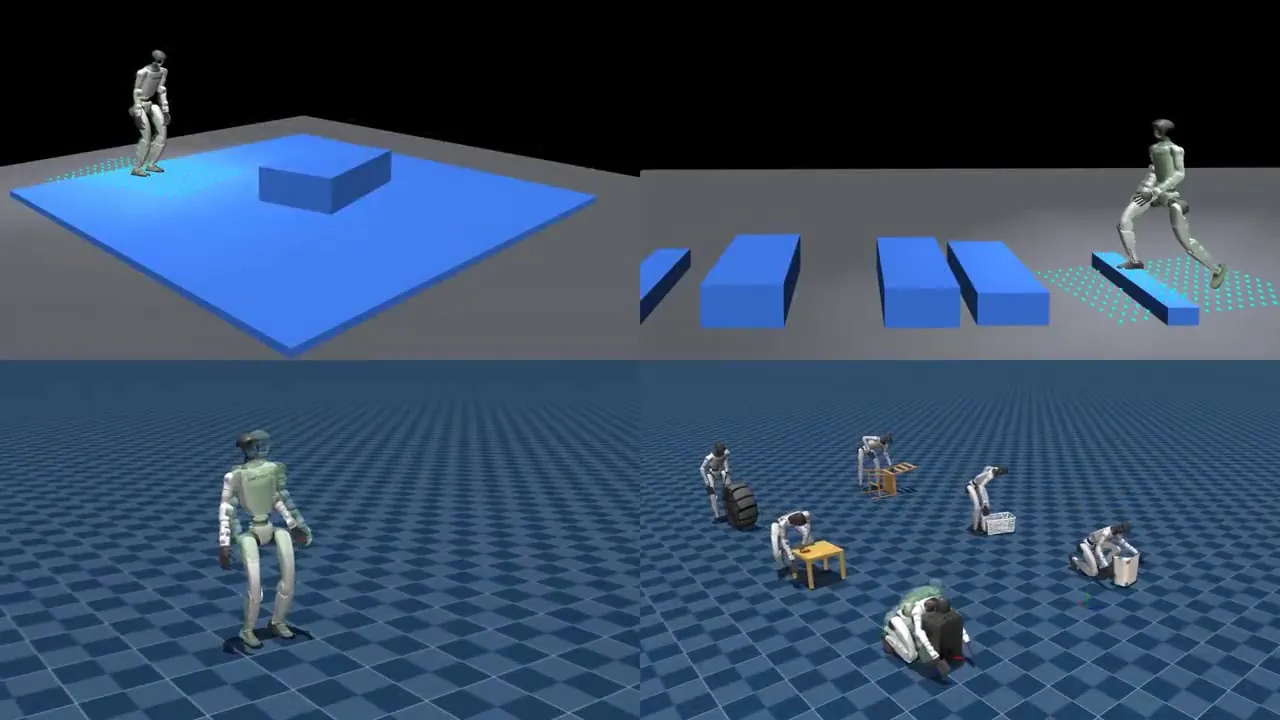
Loading videoORCS is an open toolkit for post-training privileged humanoid controllers with kinodynamic motion retargeting and reinforcement learning. Released Dodge, PerLoco, and UOLM checkpoints run in MuJoCo.
HumanoidWhole-Body ControlReinforcement LearningMotion retargetingLoRARSL-RLMuJoCoSONICORCSDodgePerLocoUOLMViBe
Category: humanoid
Author: @lok_s_h
Date: 2026-09-14T00:00:00
Duration: 14.0s
Reference: https://github.com/lok-i/orcs