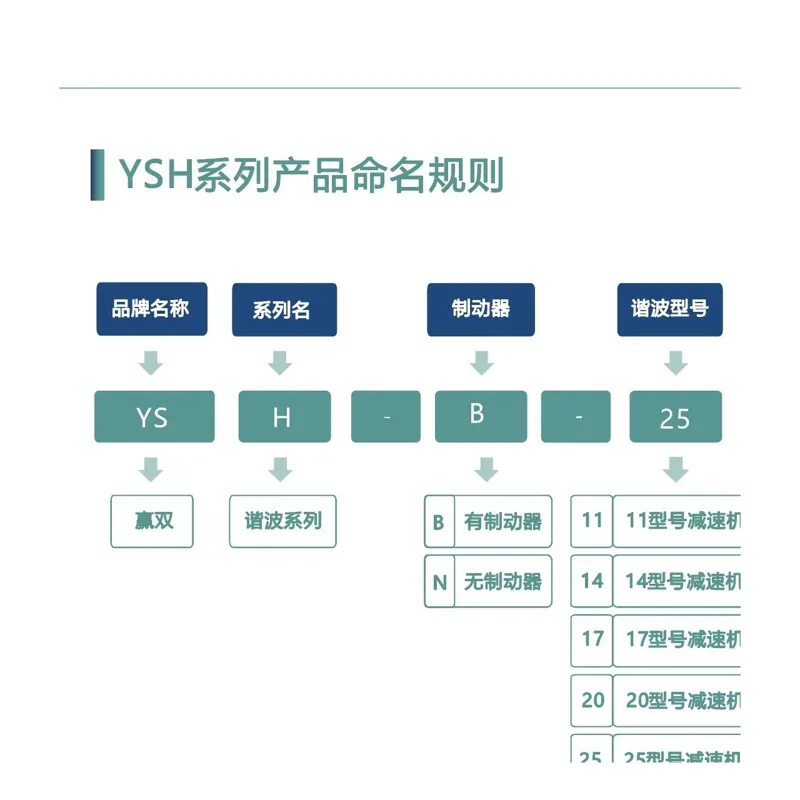
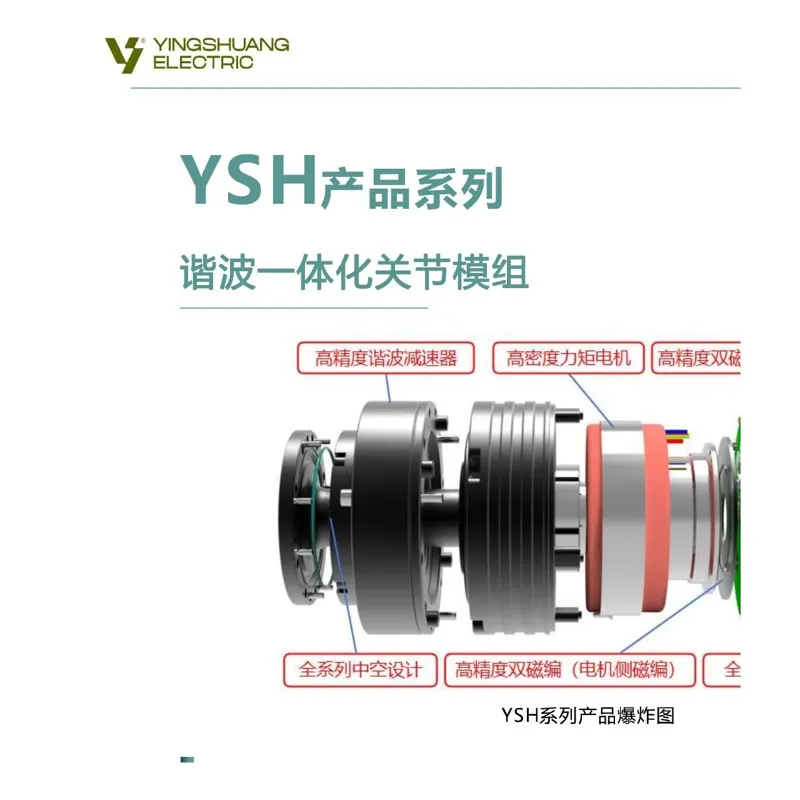
Windouble KSG-series KSG-17-100 harmonic joint module: 100:1 ratio, 85 Nm rated / 180 Nm peak torque, 80 mm body, 2.4 kg, Φ22h6 output shaft. Suited to small/medium-load robot joints. Windouble is a Chinese national-level specialized 'little giant' enterprise focused on high-precision harmonic drives for robots.
Windouble KSG-series KSG-14-100 harmonic joint module: 100:1 ratio, 40 Nm rated / 100 Nm peak torque, 70 mm body, 1.8 kg, Φ19h6 output shaft. Suited to light-load robot joints. Windouble is a Chinese national-level specialized 'little giant' enterprise focused on high-precision harmonic drives for robots.
QST (Shanghai) QMI8658 is a 6-axis MEMS IMU chip in a 2.5×3.0×0.86 mm 14-pin LGA package: gyro ±16~±2048 °/s with 15 mdps/√Hz noise density, accelerometer ±2~±16 g; I3C/I2C/SPI interfaces, −40 to +85 °C operation, on-chip temperature sensor with compensation and on-chip self-calibrated 9-axis fusion. Aimed at highly integrated designs such as drones and robot vacuums, it also serves as a chip-scale sensing option for robots.
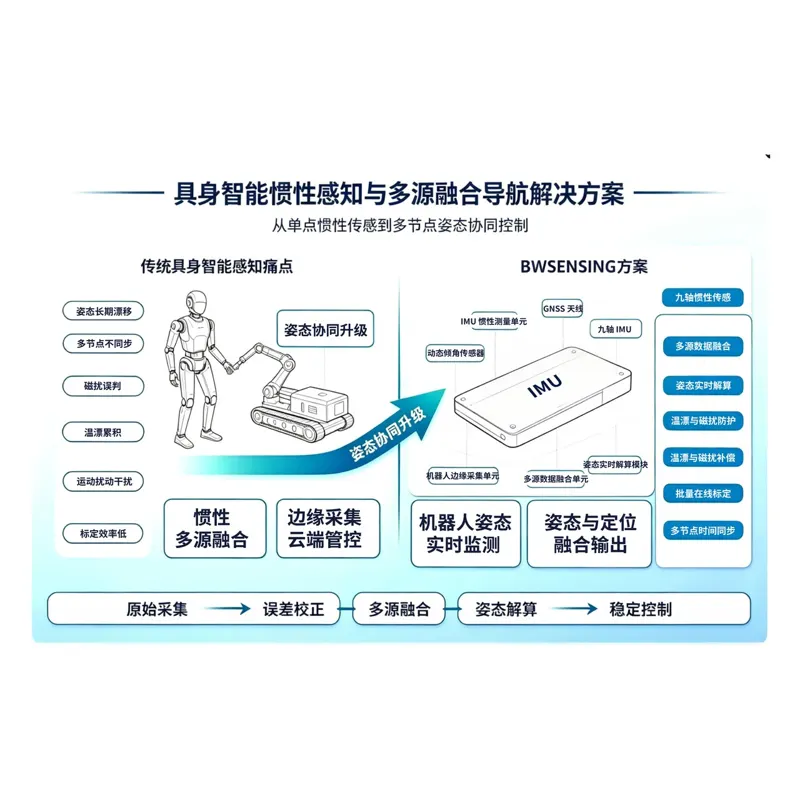
BWsensing (Wuxi) IMU400C is a high-precision 6-axis inertial measurement unit: gyro ±400 °/s with 0.01 °/s resolution, bias stability <0.5 °/h (100 s, 1σ) and angular random walk <0.1 °/√h; accelerometer ±3.6 g with 0.01 mg resolution and 0.001 mg bias stability. 500 Hz output over RS232/RS485/TTL, measuring 60×59×29 mm with −40 to +85 °C operation. Vendor-listed applications include unmanned boats/underwater robots, AGVs, robots and drones.
Asensing (Guangzhou) IMU5305 is a general-purpose industrial 6-axis IMU: gyro ±500 °/s with bias instability ≤2 °/h and angular random walk ≤0.18 °/√h; accelerometer ±16 g with bias instability ≤0.035 mg. Measures 30×30×10 mm, weighs 26.2±1 g, 5±0.5 V supply ≤0.1 A, UART+PPS interface (SPI optional) — a cost-effective domestic choice for attitude estimation on robots, AGVs and unmanned platforms.
Asensing (Guangzhou) IMU5134 is an automotive-grade 6-axis IMU certified to ISO 26262 ASIL-B functional safety: gyro ±500 °/s with bias instability ≤1.2 °/h, angular random walk ≤0.14 °/√h and 200 Hz output; accelerometer ±16 g with bias instability ≤0.04 mg and operating bias ≤0.45 mg. Measures 22.4×22.4×8.8 mm, weighs 14±1 g, 5±0.5 V supply ≤0.5 A, UART+PPS interface — suited to automotive GNSS/INS positioning and service-robot platforms with functional-safety requirements.
Asensing (Guangzhou) IMU5146 is an automotive-grade high-precision 6-axis IMU: gyro ±500 °/s (±2000 °/s optional) with bias instability ≤1.2 °/h and angular random walk ≤0.14 °/√h; accelerometer ±16 g (±32 g optional) with bias instability ≤0.015 mg; roll/pitch accuracy ≤0.1° and heading accuracy ≤0.2°, with optional ±49 Gauss magnetometer. Measures 22.4×22.4×8.8 mm, weighs 14±1 g, 5 V supply ≤50 mA, UART+PPS output. Asensing is a leading domestic automotive inertial-positioning vendor; the module also fits attitude estimation on robots and robot dogs.
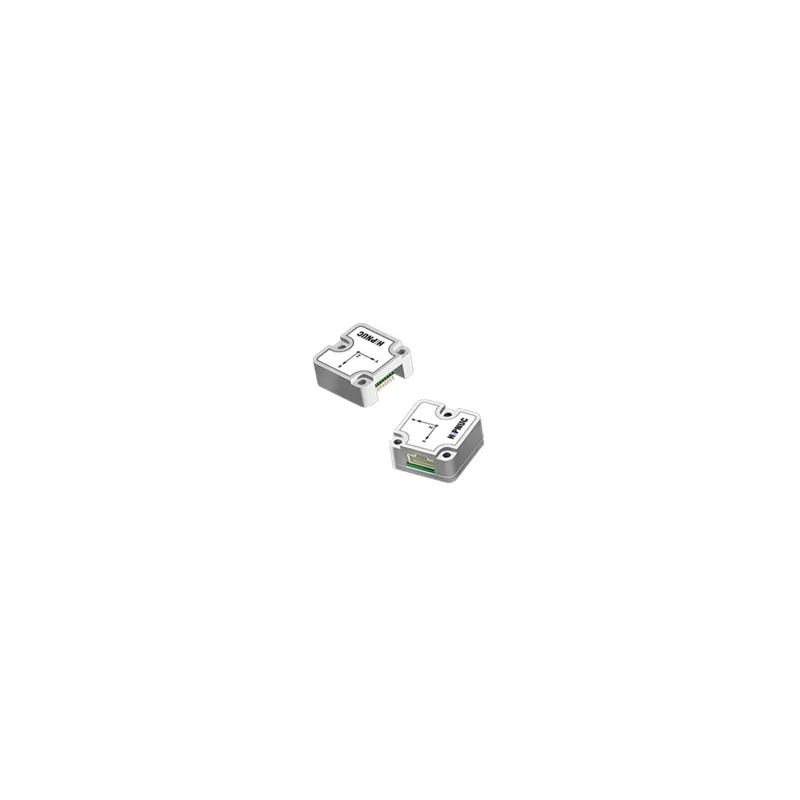
HiPNUC (Beijing) HI14 is a high-precision industrial IMU: gyro ±2000 °/s (±4000 °/s on S* high-range variants) with best S5-grade three-axis bias instability of 0.9/1.1/1.0 °/h; accelerometer ±24 g/±32 g with best bias instability of 0.0045~0.01 mg. IP68-rated housing (M12 version 59×40×20 mm, PG version 40×36×16.5 mm), wide 7~48 V supply, output at UART 1000 Hz / RS485 250 Hz / CAN 200 Hz, RoHS/CE certified — built for harsh environments such as outdoor robots, robot dogs, unmanned boats and industrial mobile platforms.
HiPNUC (Beijing) HI12 is a compact industrial 6-axis IMU for robotics, officially listed on the vendor's humanoid-robot and robot-dog solution pages. Gyro ±2000 °/s with 2.5/3.2/3 °/h three-axis bias instability at H1 grade; accelerometer ±24 g with 0.021~0.032 mg bias instability; static pitch/roll accuracy 0.15~0.2°. UART output at 1000 Hz and CAN at 200 Hz, measuring only 22×22×10 mm with 3.2~5.5 V supply, 240~300 mW power and −40 to +85 °C operation — suited to attitude estimation and motion control on humanoid robots, robot dogs and small mobile platforms.
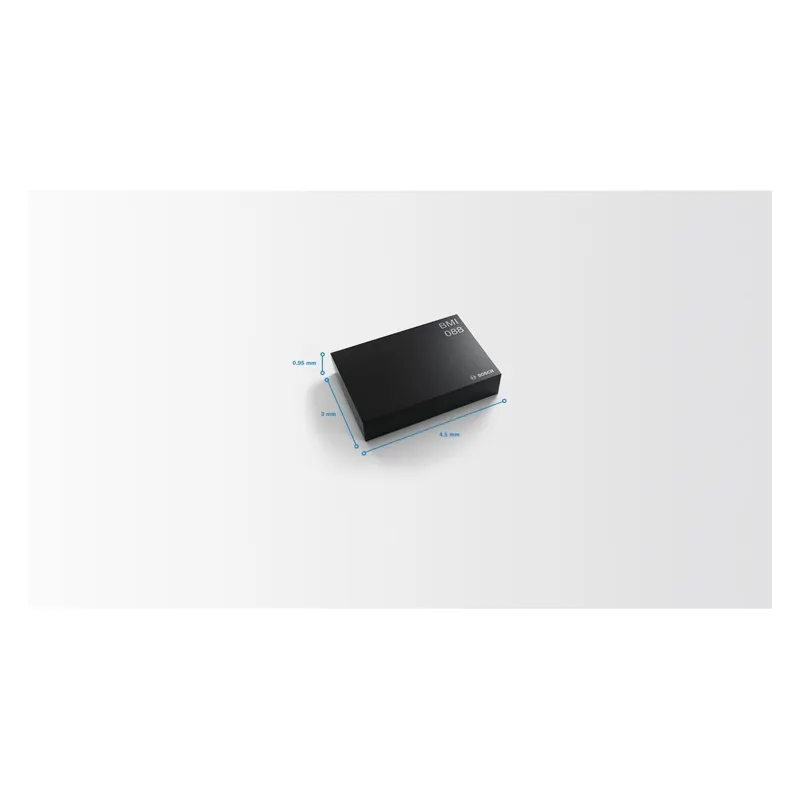
Bosch Sensortec (Germany) BMI088 is a high-performance inertial measurement unit purpose-built for drones and robots, providing highly accurate orientation and motion measurement along three orthogonal axes with excellent temperature stability. Accelerometer range selectable from ±3/±6/±12/±24 g with 16-bit resolution of 0.09 mg, 175 µg/√Hz noise density and programmable 5~523 Hz bandwidth; gyro range ±125 to ±2000 °/s with 16-bit resolution of 0.004 °/s, 0.014 °/s/√Hz noise density and output data rates of 12.5 Hz to 2 kHz. Zero offset (typ. over lifetime) is ±20 mg (accel) and ±1 °/s (gyro) with TCO of ±0.2 mg/K and ±0.015 °/s/K respectively. SPI/I²C interfaces, 2.4~3.6 V supply at 5.15 mA full-operation current, −40 to +85 °C — a classic choice for flight/attitude control on racing drones, robot dogs and humanoid robots.
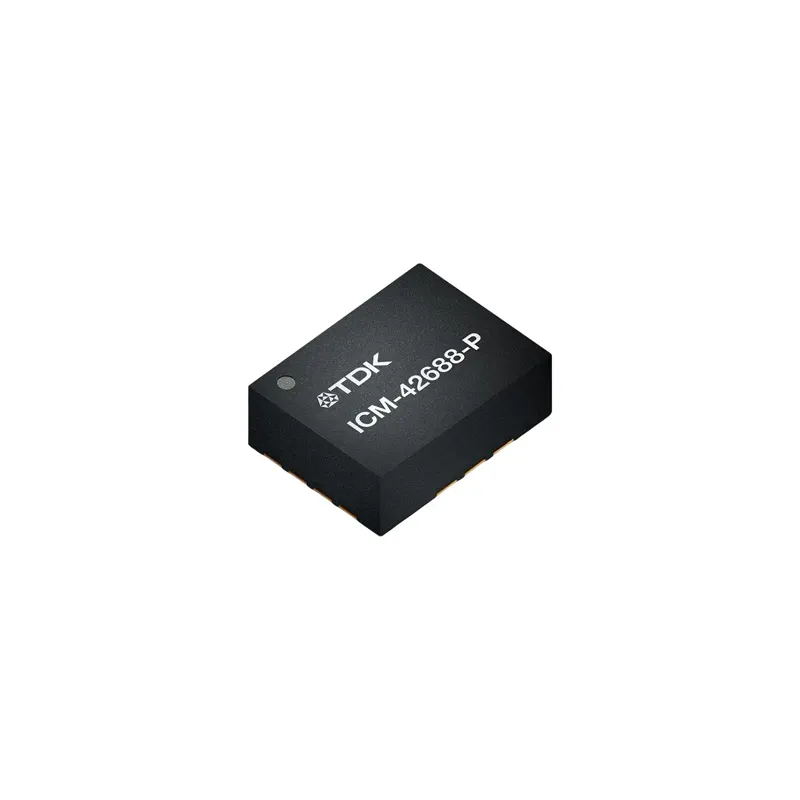
TDK InvenSense ICM-42688-P is the flagship 6-axis SmartIndustrial™ MotionTracking MEMS device for robotics and high-performance IoT, combining a 3-axis gyro and 3-axis accelerometer. Gyro noise is only 2.8 mdps/√Hz and accelerometer noise 70 µg/√Hz, with 6-axis current as low as 0.88 mA in low-noise mode; gyro full scale is selectable from ±15.6 to ±2000 dps and accelerometer from ±2 to ±16 g, with user-programmable digital filters. Host interfaces include 12.5 MHz I3C, 1 MHz I²C and 24 MHz SPI in a thin 2.5 × 3 × 0.76 mm 14-pin LGA package with drop-in 6-axis footprint compatibility. Officially targeted at AR/VR/XR, robotics and high-performance IoT, it is one of the most widely used consumer/industrial IMUs for joint and body attitude sensing on humanoid robots and robot dogs.
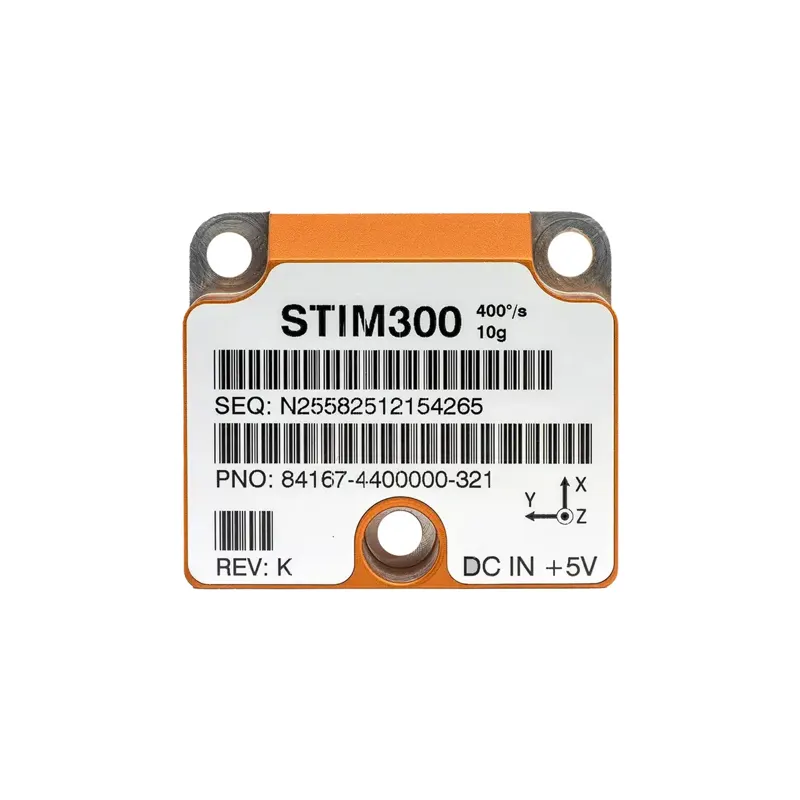
Safran Navigation & Timing (formerly Sensonor, Norway) STIM300 is a small, lightweight, high-performance non-GPS-aided tactical-grade MEMS IMU containing 3 highly accurate MEMS gyros, 3 high-stability accelerometers and 3 inclinometers, factory calibrated and temperature compensated. Gyro full scale ±400 °/s (output capped at ±480 °/s) with 262 Hz bandwidth and up to 2000 samples/s; 0.3 °/h bias instability and 0.15 °/√h angular random walk (Allan variance, 25 °C), 3 °/h drift-rate stability over temperature; the ±10 g accelerometer shows 0.04 mg bias instability and 0.07 m/s/√h velocity random walk; axis misalignment is just 1 mrad. Single +5 V supply at 1.5~2 W, RS422 interface, 55 g mass, ITAR-free — a cost-effective FOG-class alternative for precision navigation on humanoid robots, robot dogs, unmanned systems and stabilization platforms.