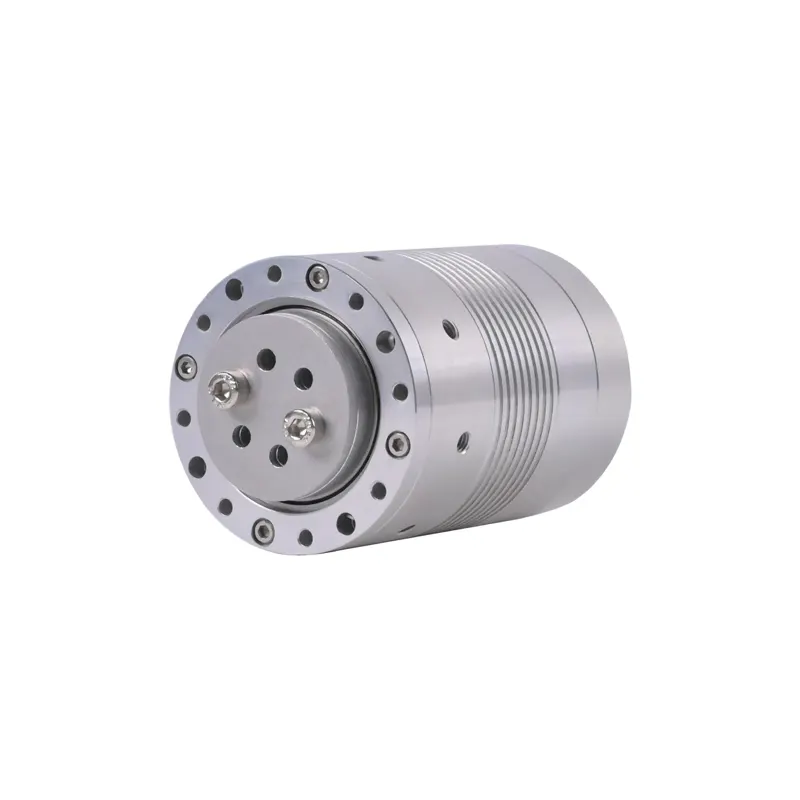
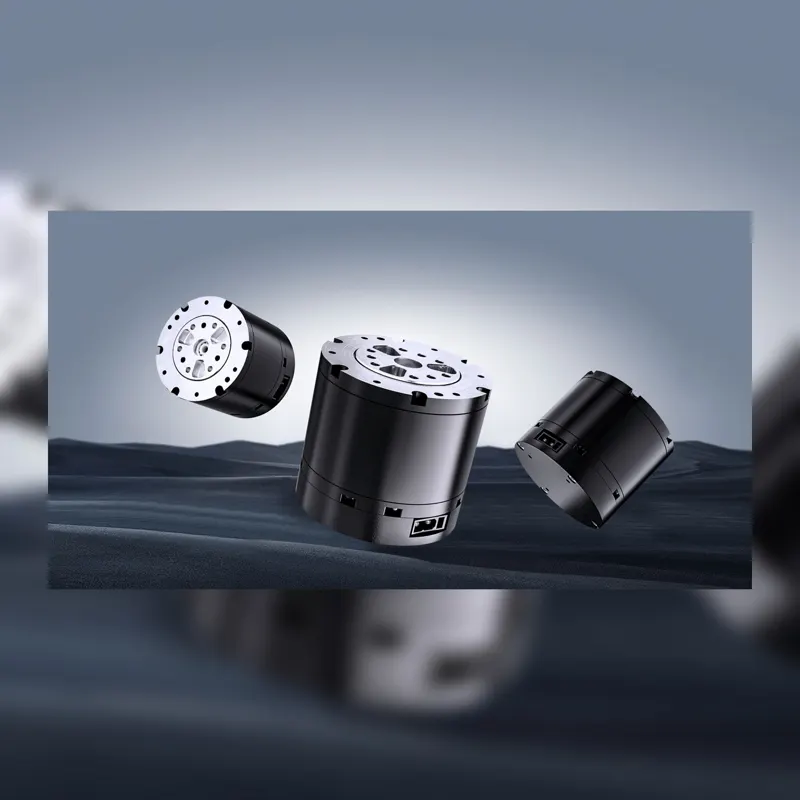
ENCOS (Nanjing Encos Intelligent Technology) EC-A series integrated joint module with size-14 harmonic drive (ratio 107): 20 N·m rated / 60 N·m peak torque, 52rpm peak speed, Φ53 × 78.5mm, 434g. Low-speed high-precision large reduction, suited to wrists, necks and other precision joints of humanoid robots.
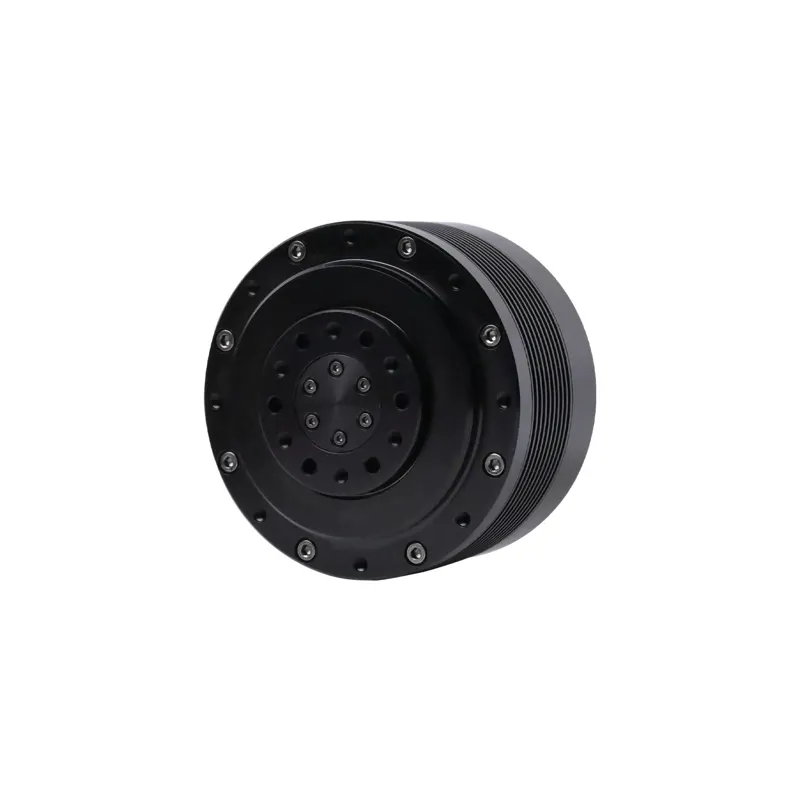
ENCOS (Nanjing Encos Intelligent Technology) EC-A series integrated joint module with two-stage planetary (ratio 25): 40 N·m rated / 120 N·m peak torque, 120rpm peak speed, Φ88 × 67.5mm, 805g. Medium-torque relatively-high-speed joints such as elbows, knees and shoulders of humanoid robots.
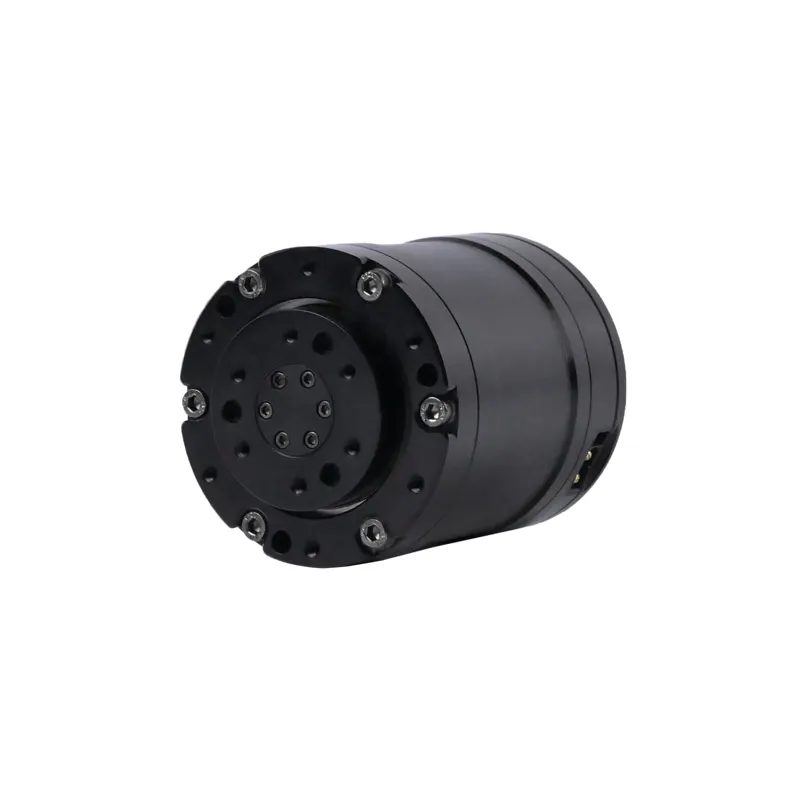
ENCOS (Nanjing Encos Intelligent Technology) EC-A series integrated joint module with two-stage planetary (ratio 36): 25 N·m rated / 75 N·m peak torque, 117rpm peak speed, Φ56 × 69.5mm, 485g. Low-torque high-speed joints such as wrists, ankles and small joints of humanoid robots.
EduLite 05 entry-level quasi-direct-drive joint module for developers and education: 6N·m peak / 1.8N·m rated torque, 9:1 ratio, 242g, powder-metallurgy gears and dual magnetic encoders at just ¥299, ideal for teaching, research and DIY robots.
RobStride 06 mid-torque quasi-direct-drive joint module: 36N·m peak / 11N·m rated torque, 9:1 ratio, 621g, 88×88×49mm. FOC drive, dual magnetic encoders and closed-loop thermal control, for humanoid elbow/knee and quadruped hip joints.
RobStride 05 compact quasi-direct-drive joint module: 5.5N·m peak / 1.6N·m rated torque, 7.75:1 ratio, only 191g, 46×46×44mm. FOC drive with closed-loop thermal control, for humanoid wrist/ankle joints, small quadrupeds and exoskeletons.
RobStride 04 flagship high-torque quasi-direct-drive joint module: 120N·m peak / 40N·m rated torque, 9:1 ratio, 1420g, torque density 85.71N·m/kg, 700W rated power, dual 14-bit magnetic encoders, CE certified. Ideal for humanoid hip/knee joints.
RobStride 03 high-torque quasi-direct-drive joint module: 60N·m peak / 20N·m rated torque, 9:1 ratio, 880g, torque density 66.67N·m/kg, 380W rated power, dual magnetic encoders. Suited for humanoid shoulder/waist/hip joints.
RobStride 02 dual-encoder quasi-direct-drive joint module: driver, motor, planetary reducer and dual magnetic encoders in one, 17N·m peak / 6N·m rated torque, 7.75:1 ratio, 405g. Dual encoders enable output-side absolute position closed-loop control for humanoid limbs and cobots.
RobStride 02 IP67 quasi-direct-drive joint module with full dust/water protection: 17N·m peak / 6N·m rated torque, 7.75:1 ratio, 490g, 60×60×27mm, dual magnetic encoders. Built for outdoor quadrupeds and rugged deployments, 48V supply.
RobStride 01 quasi-direct-drive joint module integrating driver, motor, planetary reducer and encoder: 17N·m peak / 6N·m rated torque, 7.75:1 ratio, 380g, torque density 44.73N·m/kg, 170W rated output, IP52 (IP67 customizable), with tuning software and dev examples.
RobStride 00 quasi-direct-drive integrated joint module: motor + planetary reducer + driver in one, 14N·m peak / 5N·m rated torque, 10:1 ratio, only 310g, 57×57×51mm. FOC drive with dual magnetic encoders, 48V rated voltage, for quadruped/humanoid robot joints, robotic arms and exoskeletons.