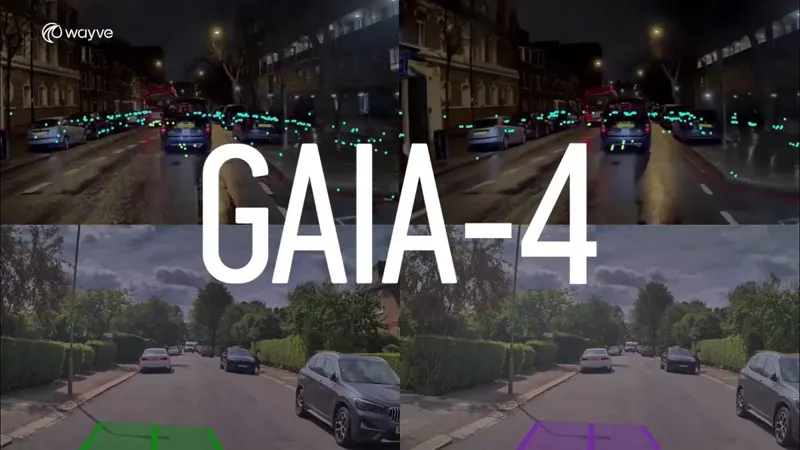
Wayve releases GAIA-4 world model for production-scale robotics simulation after a decade of research since their first world model in 2018.
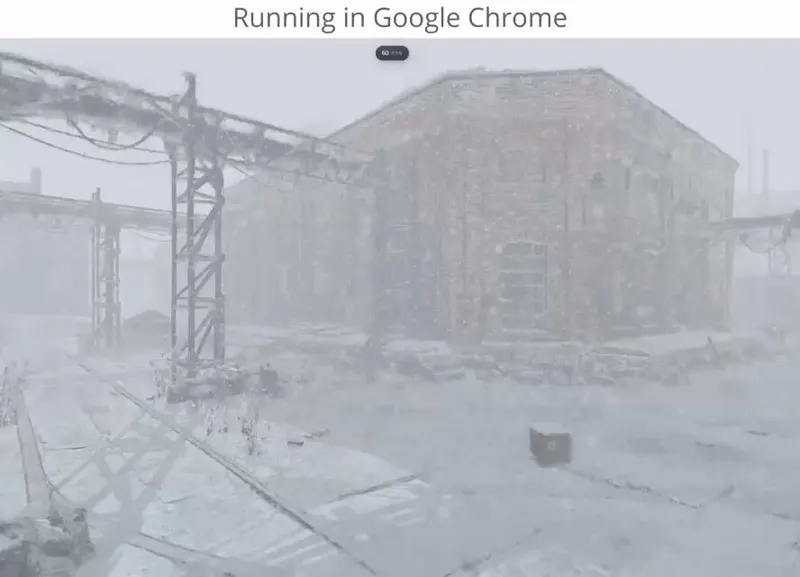
UnrealTwin uses WebGPU to render real-time physics-based snow in a 36M-splat 3D space.
FDDC embeds the first deployable dynamic center-of-mass (xCoM) observation directly into the on-hardware actor and pairs it with a reward library translated from human postural control, holding clean single-leg balance on 86 of 90 motions and transferring to a real Unitree G1.
Yikai Zhou, Xingyun Wang, Jieming Cui
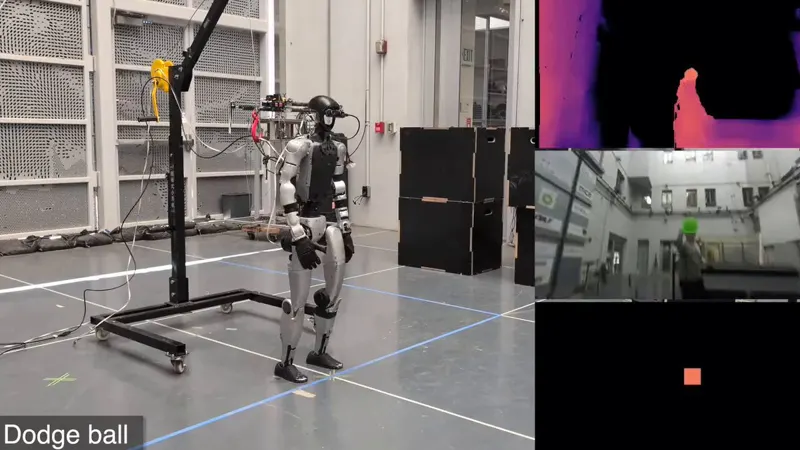
Unitree G1 dodges balls using onboard RGB-D vision, avoiding 19 of 20 throws without falling, with full-body reflexes and no real-world fine-tuning
Reframes camera trajectory planning as language-grounded spatial reasoning, equipping an LLM agent with a structured 3D scene graph to decompose prompts into trajectories
RoboSense shipped 719,200 LiDAR units in H1 2026, up 2.7x YoY, with robotics accounting for 282,600 units, a 6.1x increase
ACE-Data-0 is a large-scale synchronized multimodal dataset aligning ego and multi-view video, human/hand/object motion, audio, and tactile sensing on a unified timeline and shared coordinate system.
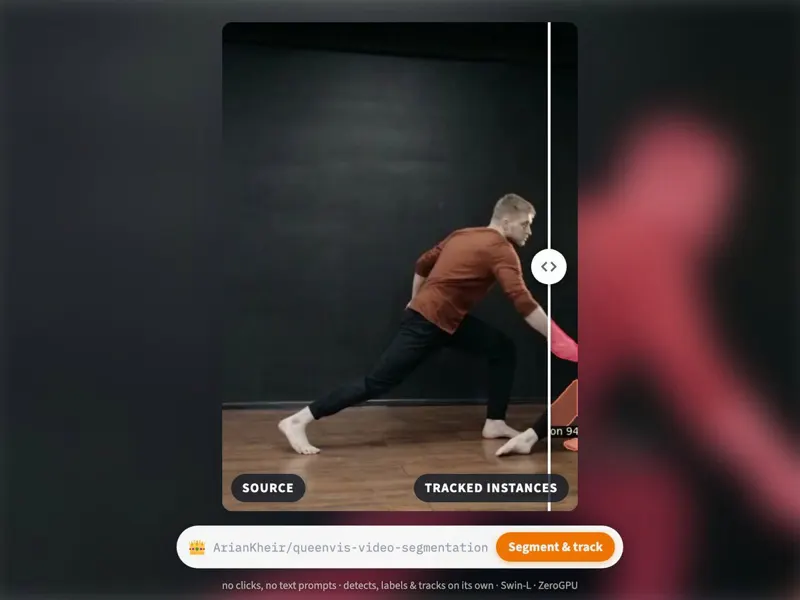
Detects, labels and tracks people and objects in raw video with no prompting needed, maintaining identities through occlusion
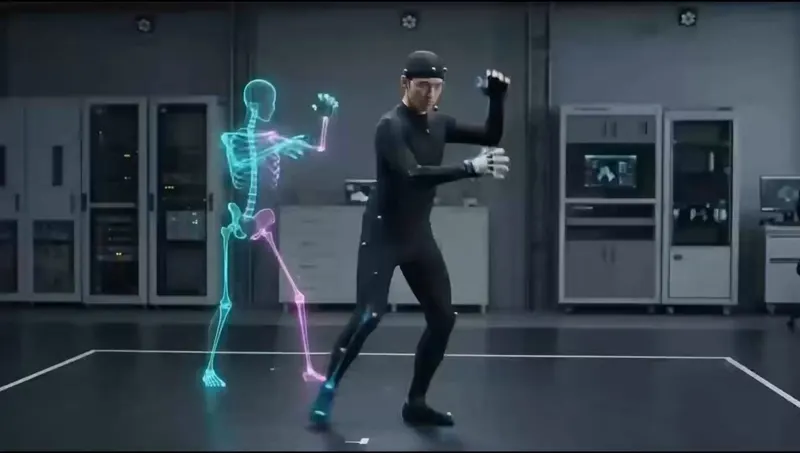
Archon Robotics achieves full self-perception on the robot itself, no motion capture cage required
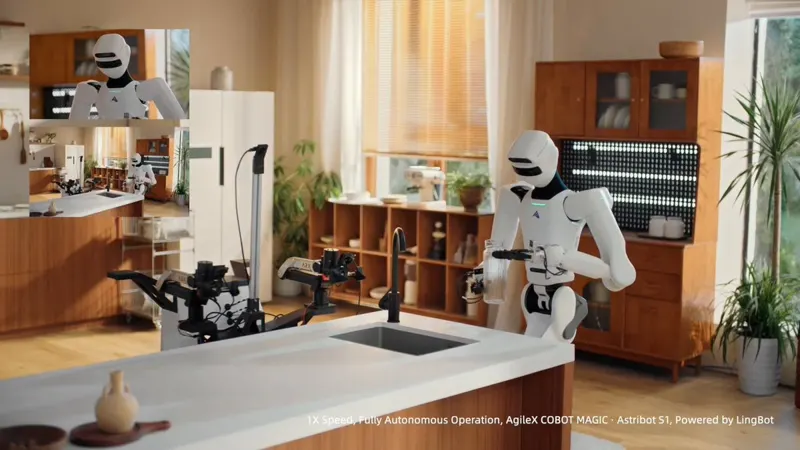
Solves transparent water perception for robots — recognizes invisible water columns in real time and performs precise autonomous water filling
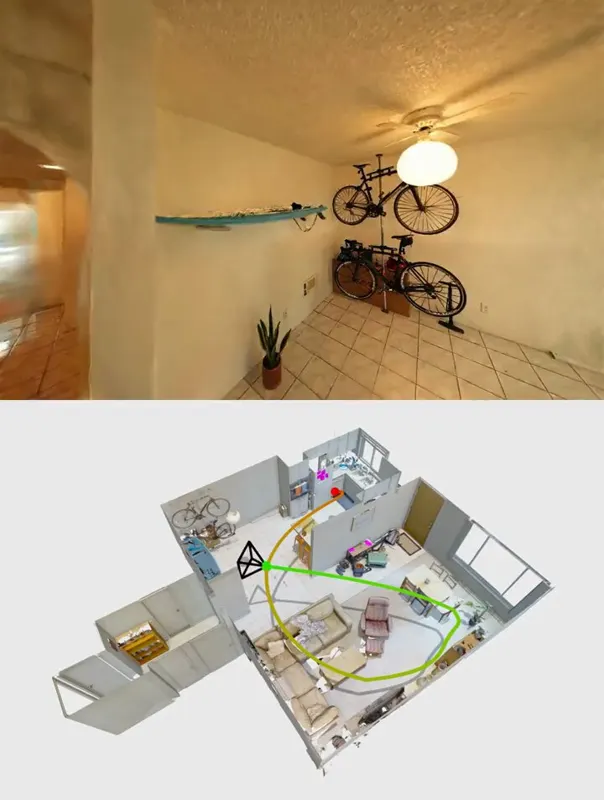
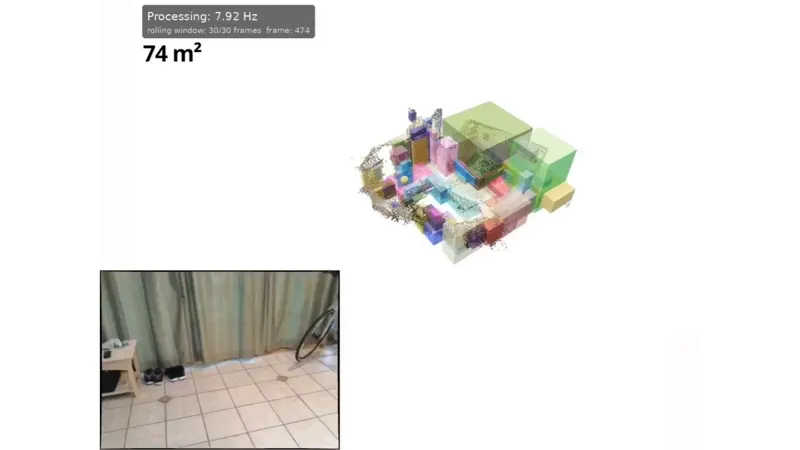
Builds structured spatial memory integrating object features and relative positions, enabling language-guided precise object search across 15,000 sqm construction sites
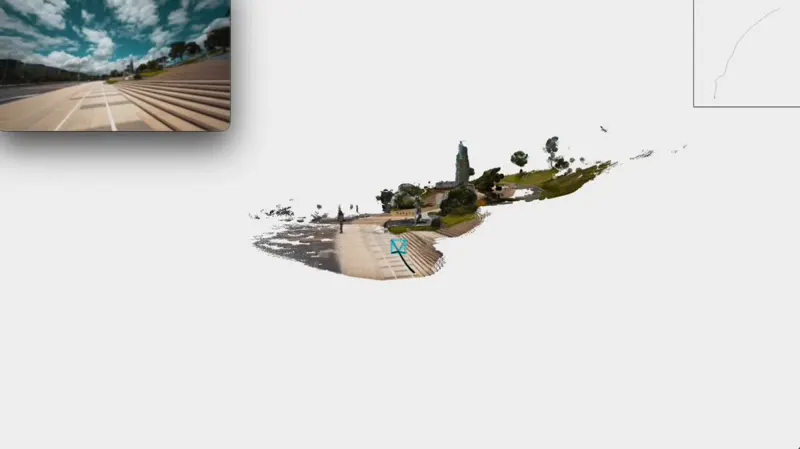
HKUST and Alibaba propose Glob3R, a scalable global 3D reconstruction framework built on geometric foundation models for large-scale SfM
As an Amazon Associate, we earn from qualifying purchases.