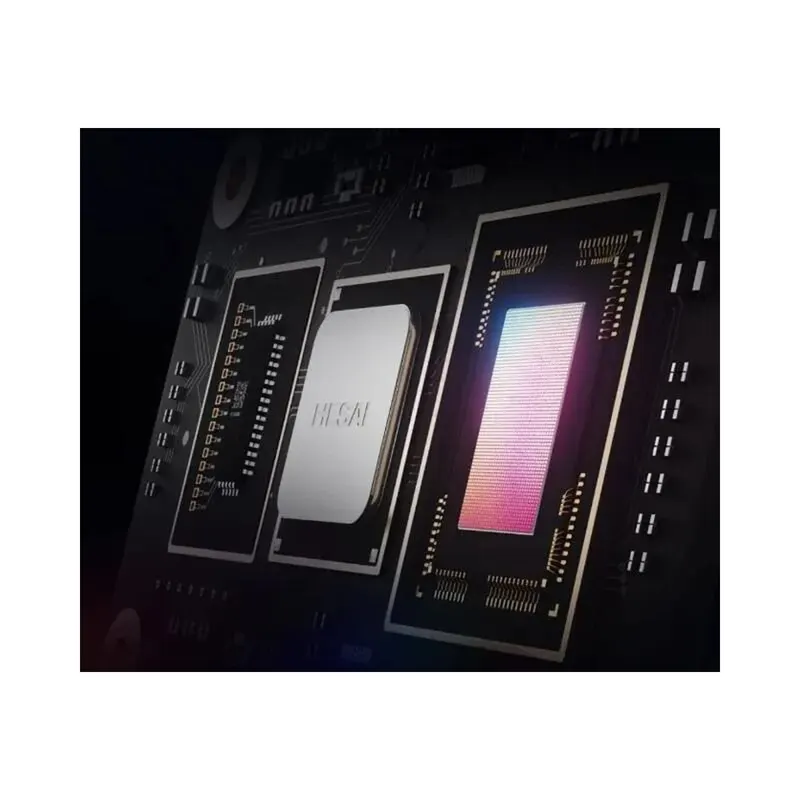
Hesai's Picasso SPAD-SoC fuses color imaging and ToF ranging at pixel level on a single chip, sensing 3D space (XYZ) and object color (RGB) simultaneously and outputting color point clouds directly; photon detection efficiency (PDE) exceeds 40%, debuting in the ETX LiDAR series with up to 4320-line full-color 4K perception, mass production targeted for H2 2026.
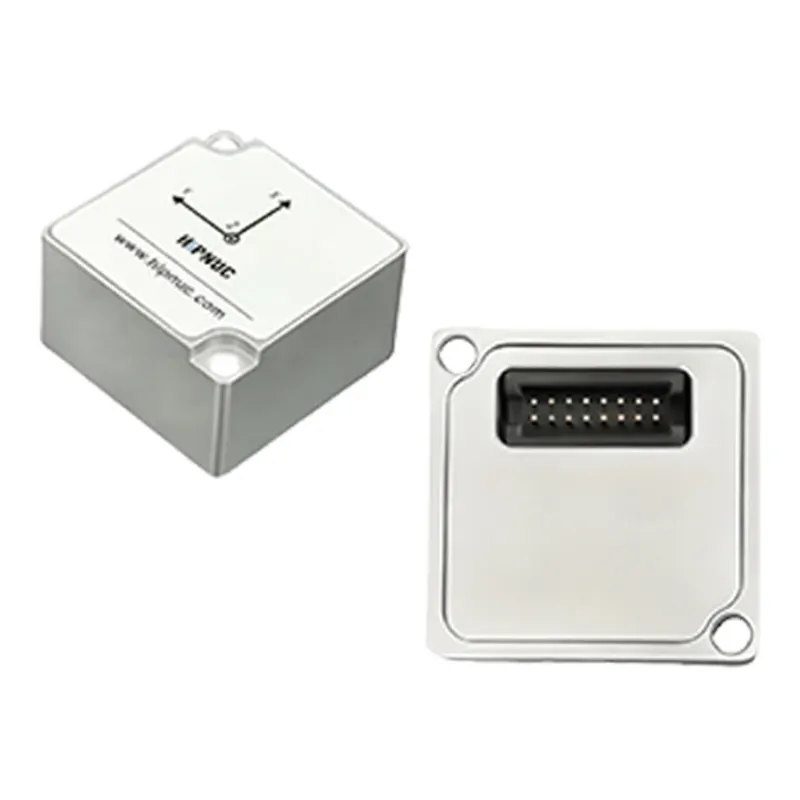
HiPNUC (Beijing) HI71 is a tactical-grade compact inertial module in a 24×24×14 mm aluminum case with board-to-board connectors for easy integration. Four variants: T2 (VRU), T4 (AHRS + barometer), M4 (MRU heave) and N4 (INS): gyro ±300 °/s with 0.3 °/h bias instability and 0.0004 °/s√Hz XY noise density; accelerometer ±16 g with 10 μg bias instability; T4/M4/N4 add a ±20 Gauss magnetometer and 300~1200 hPa barometer. Pitch/roll 0.05~0.1°, UART up to 1000 Hz and CAN at 200 Hz, binary/CANopen/Modbus/NMEA protocols with PPS/UTC sync, 3.6~5 V supply at 370 mW.
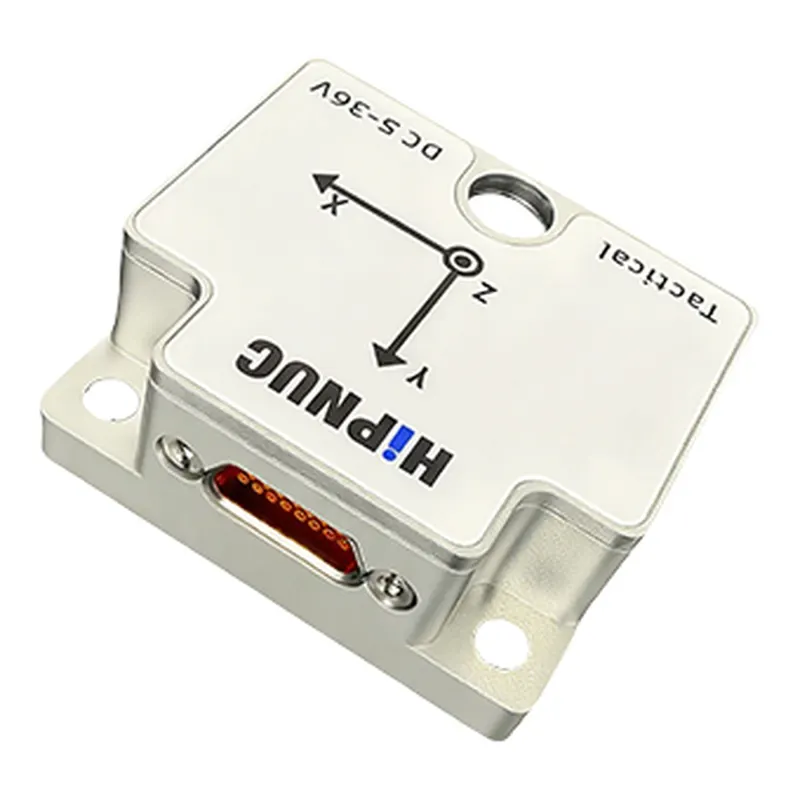
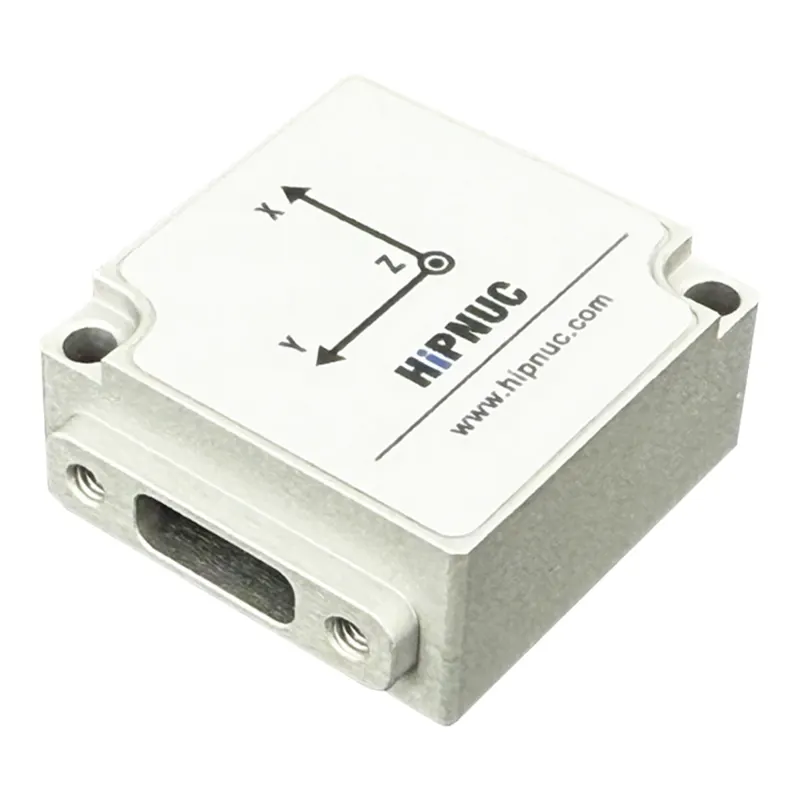
HiPNUC (Beijing) HI70 is a tactical-grade high-precision inertial sensor in a 44.8×38.6×18.5 mm aluminum enclosure weighing 55 g, with full-temperature factory calibration of scale factor, cross-axis and bias plus excellent vibration tolerance. Gyro ±300 °/s with 0.3 °/h bias instability and 0.0004 °/s√Hz XY noise density, up to 250 Hz 3dB bandwidth; accelerometer ±16 g with 10 μg bias instability; T3 variant adds a ±20 Gauss magnetometer. Static/dynamic pitch-roll 0.05~0.07° with 0.1° heading drift over 2 h stationary. RS-232/RS-422 up to 1000 Hz and CAN at 200 Hz, binary and CANopen protocols, wide 4.8~36 V input at 400 mW.
HiPNUC (Beijing) HI13 is a stand-alone aluminum-enclosure attitude sensor of 26×24×12 mm with plug-and-play USB Type-C and a fully symmetric design for easy integration. Seven variants M0/M3/R2/R3/S2/S3/S4: M/R series offer ±2000 °/s gyro and ±24 g accelerometer, while S series reach ±4000 °/s and ±32 g, with bias instability up to 1.6 °/h; three variants include a ±2000 μT wide-range magnetometer. USB output up to 1000 Hz, 4.5~5.5 V supply, 215~300 mW, −40 to +85 °C — ideal for robots needing ready-to-read attitude data.
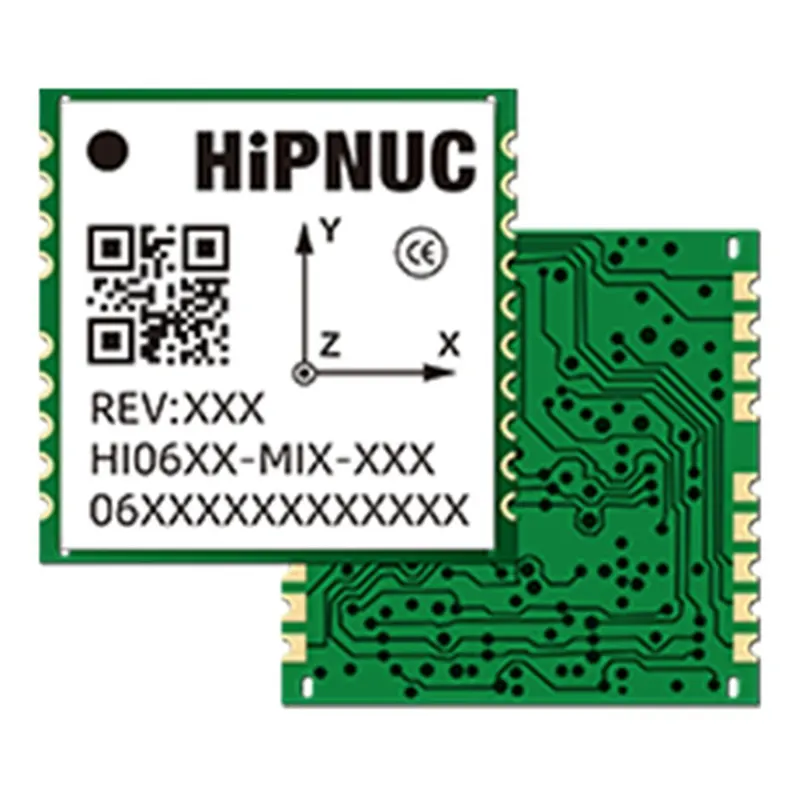
HiPNUC (Beijing) HI06 is a tactical-grade compact SMD attitude module of 15×15.2×2.6 mm with full-temperature calibration of scale factor, cross-axis alignment and bias. Gyro ±4000 °/s with 0.0025 °/s√Hz noise density and bias instability as low as 0.9/1.0/1.1 °/h, up to 400 Hz 3dB bandwidth; accelerometer ±32 g with 0.011~0.05 mg bias instability; T3/N3 variants add a ±2000 μT magnetometer. Static pitch/roll 0.08~0.12°, UART at 1000 Hz and CAN at 200 Hz, PPS/UTC sync, 3.2~5.5 V supply at 220 mW, with official ROS, C and QT example code.
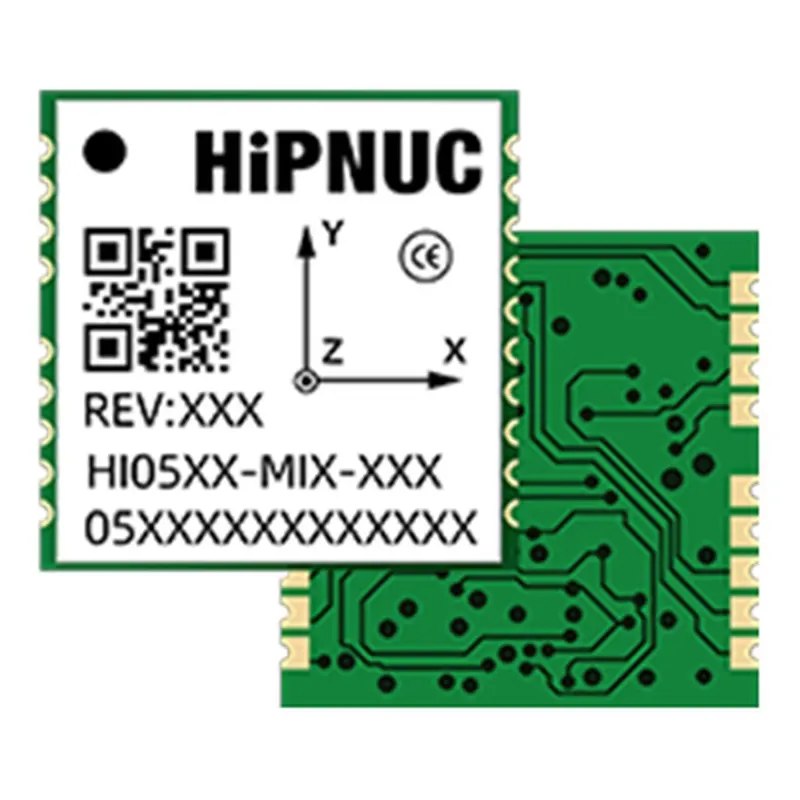
HiPNUC (Beijing) HI05 is a full-featured, low-noise SMD attitude module of 15×15×2.6 mm and under 1.5 g, offering IMU/VRU/AHRS/INS variants with optional barometer. Gyro ±4000 °/s with 0.0025 °/s√Hz noise density, 4/1.5/1.7 °/h bias instability and up to 400 Hz 3dB bandwidth; accelerometer ±32 g with 0.012~0.016 mg bias instability. R3/N3/R4/N4 variants add a ±2000 μT magnetometer, and R4/N4 a 300~1200 hPa barometer. UART at 1000 Hz and CAN at 200 Hz, 3.2~5.5 V supply, 195~205 mW, with PPS/UTC time synchronization.
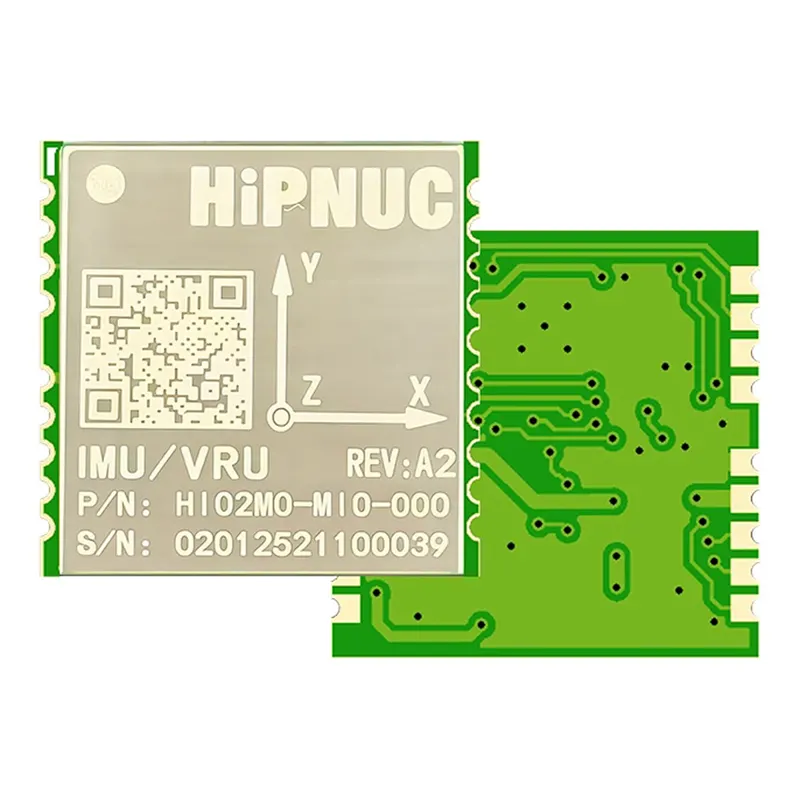
HiPNUC (Beijing) HI02 is a compact SMD 6-axis attitude module built for cost-sensitive mobile platforms, measuring just 15×15×2.6 mm with full-temperature factory calibration. Gyro ±2000 °/s with 2.5/3.2/3 °/h three-axis bias instability; accelerometer ±24 g; static pitch/roll accuracy 0.1~0.2°. UART(TTL) output at 200 Hz, 3.2~5.5 V supply, −40 to +85 °C operation, and onboard EKF fusion delivering both calibrated raw data and fused attitude — aimed at robot vacuums, lawn mowers and pool cleaners.
IMU-G-1020-S is an industrial 6-axis IMU module from Shenzhen SZLIGHT (SZLCTEK), built on a purple PCB (V1.0, 2025-08-29) around a HiPNUC HI14-series MEMS inertial chip (silkscreen HIPNUCHI14). The HI14 family offers gyro ranges of ±2000 to ±4000 °/s and accelerometer ranges of ±24 to ±32 g, outputs fused Euler angles and quaternions at up to 1000 Hz over UART/USB, and applies full-temperature compensation from -40 to +85 °C for harsh outdoor environments. This board breaks out 5V/GND, TXD/RXD, an RSYNC sync pin and RS-485 (485A/485B) through an 8-pin connector, targeting robot attitude sensing and stabilization. No public page exists for the module vendor, so core specs follow the official HiPNUC HI14 datasheet.
QST (Shanghai) QMI8658 is a 6-axis MEMS IMU chip in a 2.5×3.0×0.86 mm 14-pin LGA package: gyro ±16~±2048 °/s with 15 mdps/√Hz noise density, accelerometer ±2~±16 g; I3C/I2C/SPI interfaces, −40 to +85 °C operation, on-chip temperature sensor with compensation and on-chip self-calibrated 9-axis fusion. Aimed at highly integrated designs such as drones and robot vacuums, it also serves as a chip-scale sensing option for robots.
BWsensing (Wuxi) IMU400C is a high-precision 6-axis inertial measurement unit: gyro ±400 °/s with 0.01 °/s resolution, bias stability <0.5 °/h (100 s, 1σ) and angular random walk <0.1 °/√h; accelerometer ±3.6 g with 0.01 mg resolution and 0.001 mg bias stability. 500 Hz output over RS232/RS485/TTL, measuring 60×59×29 mm with −40 to +85 °C operation. Vendor-listed applications include unmanned boats/underwater robots, AGVs, robots and drones.
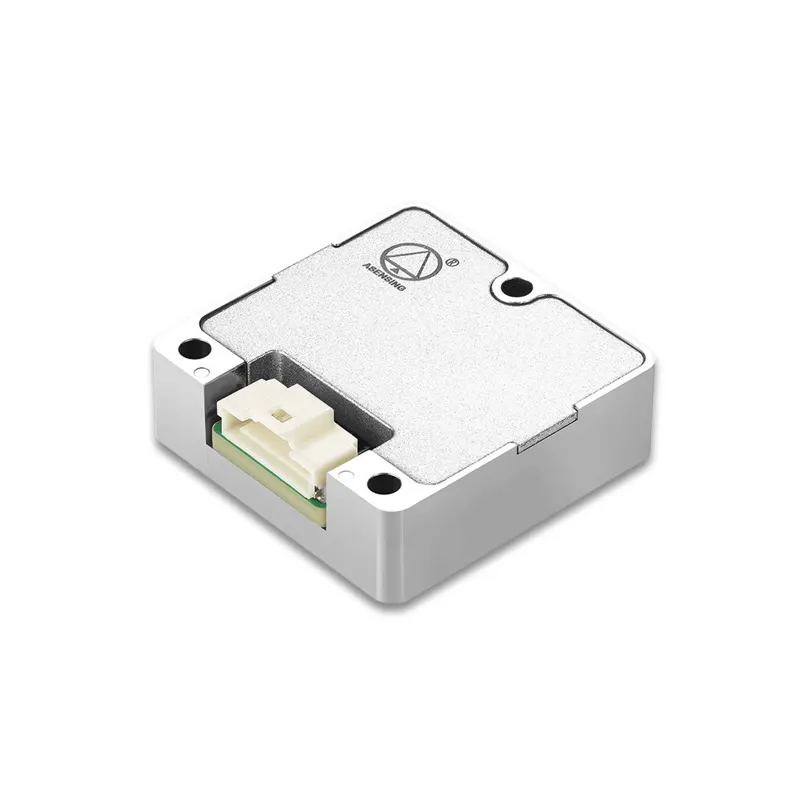
Asensing (Guangzhou) IMU5305 is a general-purpose industrial 6-axis IMU: gyro ±500 °/s with bias instability ≤2 °/h and angular random walk ≤0.18 °/√h; accelerometer ±16 g with bias instability ≤0.035 mg. Measures 30×30×10 mm, weighs 26.2±1 g, 5±0.5 V supply ≤0.1 A, UART+PPS interface (SPI optional) — a cost-effective domestic choice for attitude estimation on robots, AGVs and unmanned platforms.
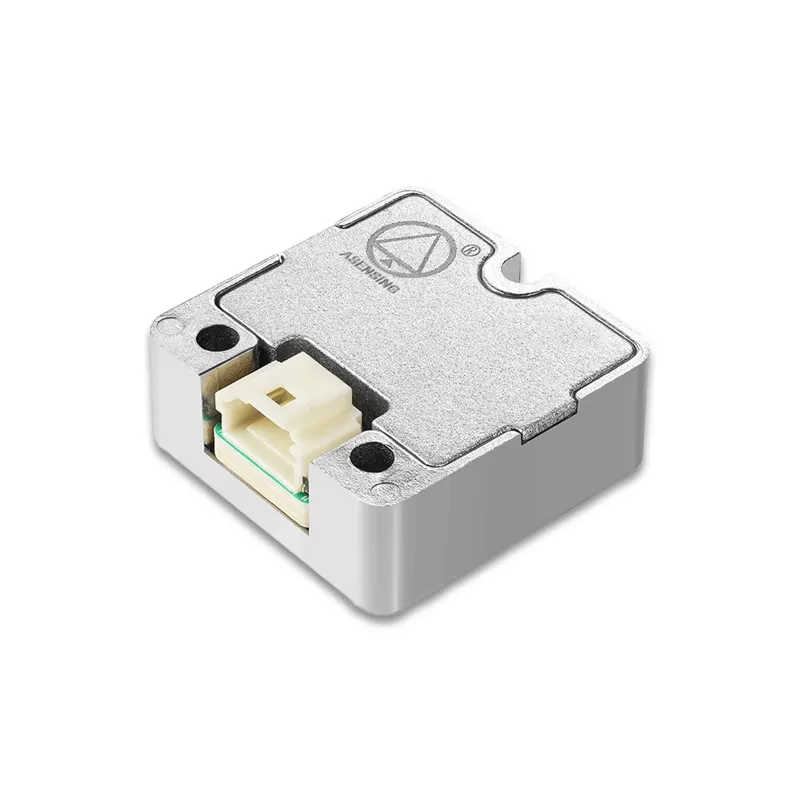
Asensing (Guangzhou) IMU5134 is an automotive-grade 6-axis IMU certified to ISO 26262 ASIL-B functional safety: gyro ±500 °/s with bias instability ≤1.2 °/h, angular random walk ≤0.14 °/√h and 200 Hz output; accelerometer ±16 g with bias instability ≤0.04 mg and operating bias ≤0.45 mg. Measures 22.4×22.4×8.8 mm, weighs 14±1 g, 5±0.5 V supply ≤0.5 A, UART+PPS interface — suited to automotive GNSS/INS positioning and service-robot platforms with functional-safety requirements.