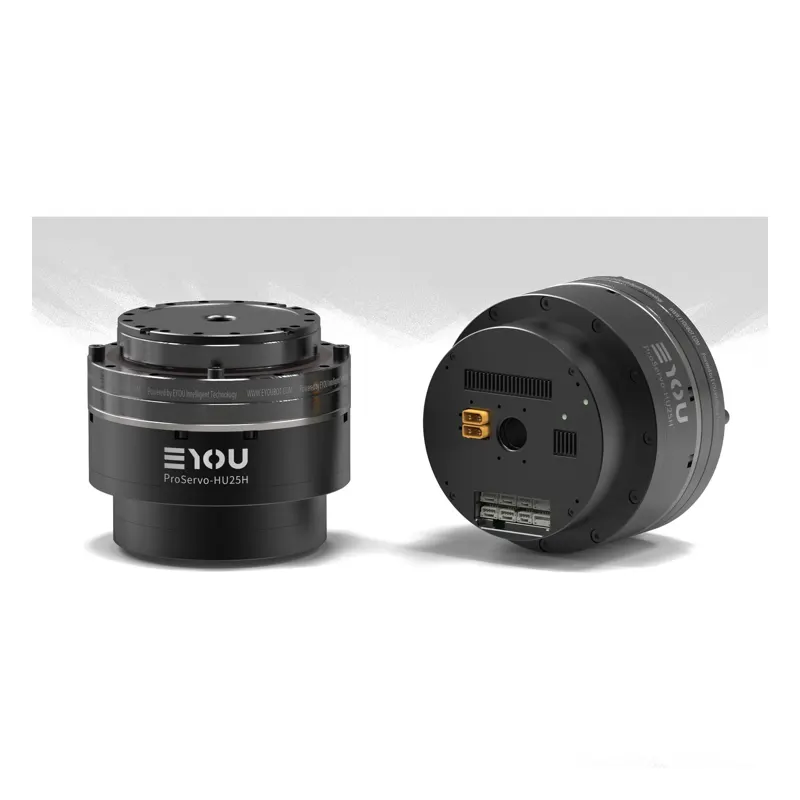
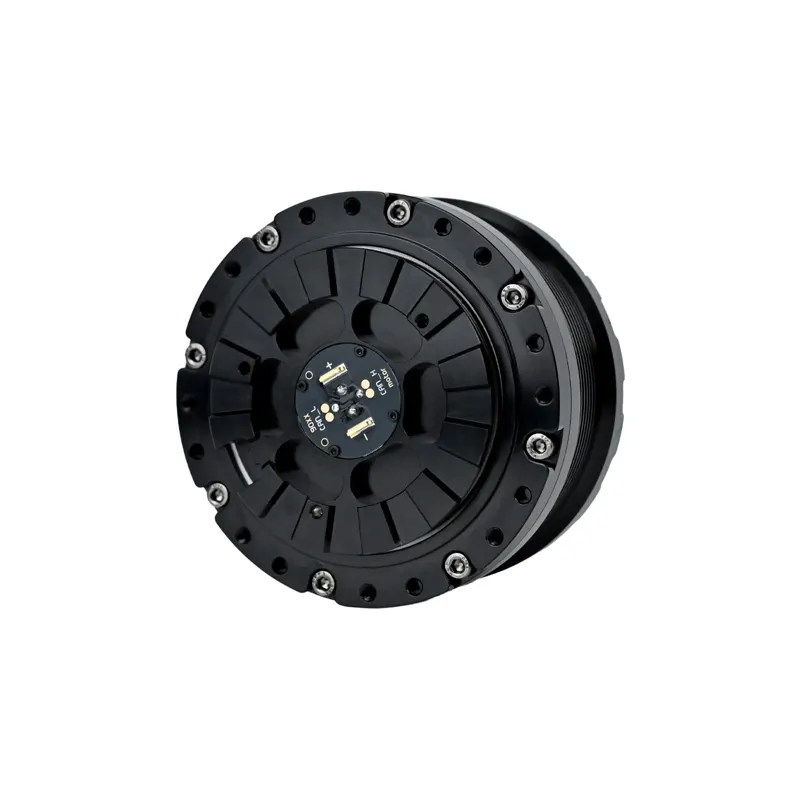
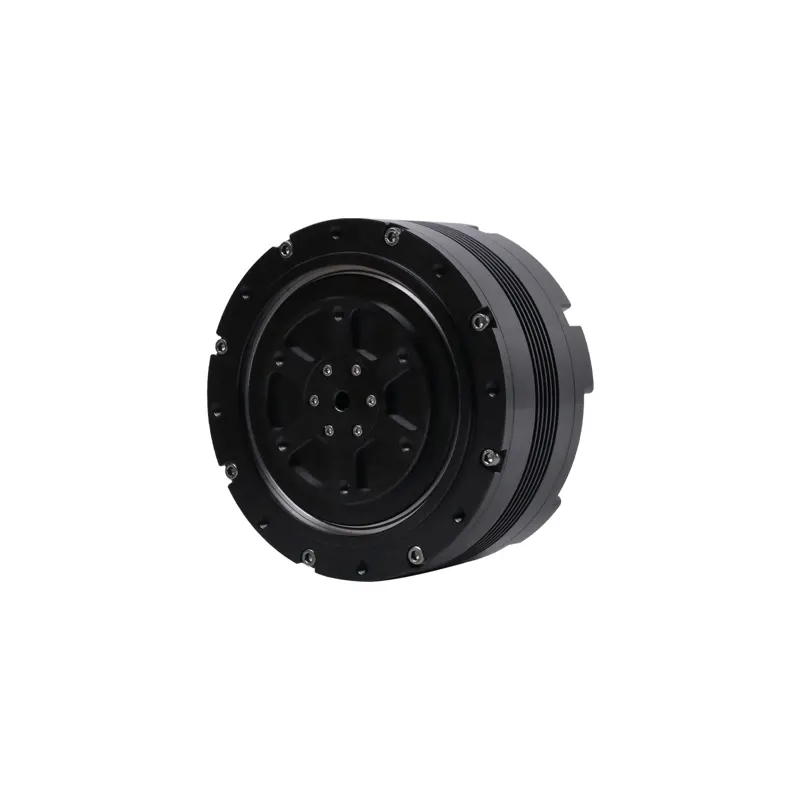
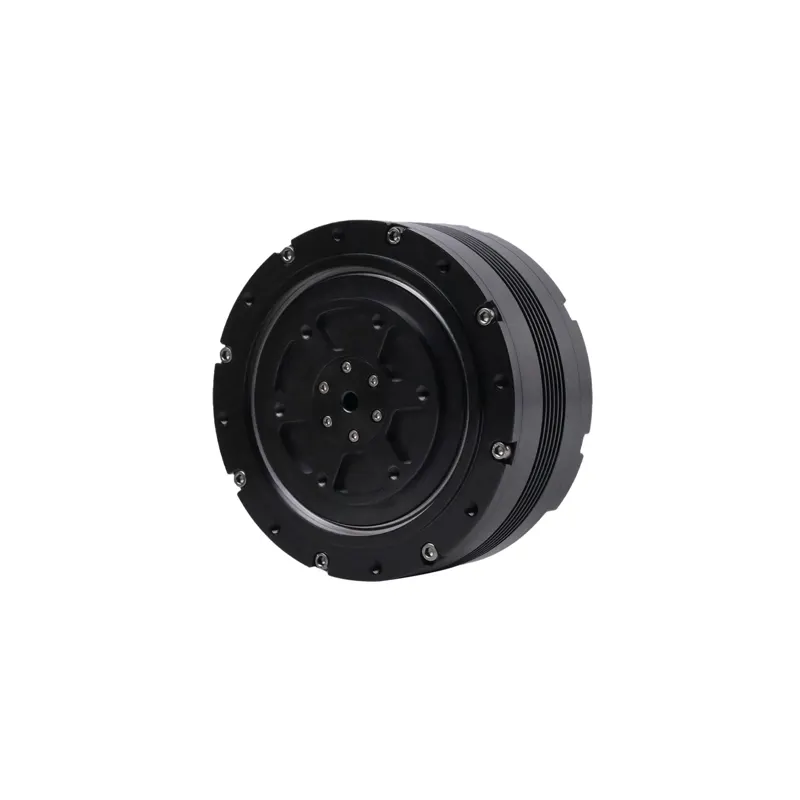
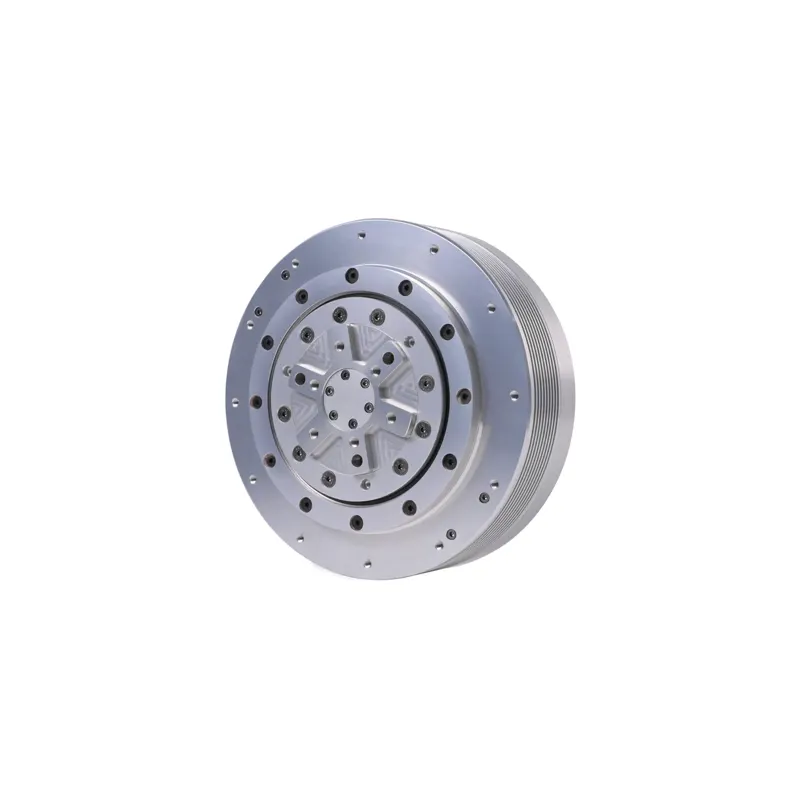
Flagship of EYOBOT's PHU enhanced harmonic series: φ170×149mm, 9160g (B) / 8520g (N), 23mm hollow shaft, ratio 81/101/121/161, rated torque at 2000rpm 255-320 N·m, peak 641-800 N·m, instantaneous max up to 1210-1458 N·m. Dual-absolute 19-bit encoders, EtherCAT/CANopen, 24-48V, >8000h life. For waist and hip ultra-heavy-load joints of humanoid robots.
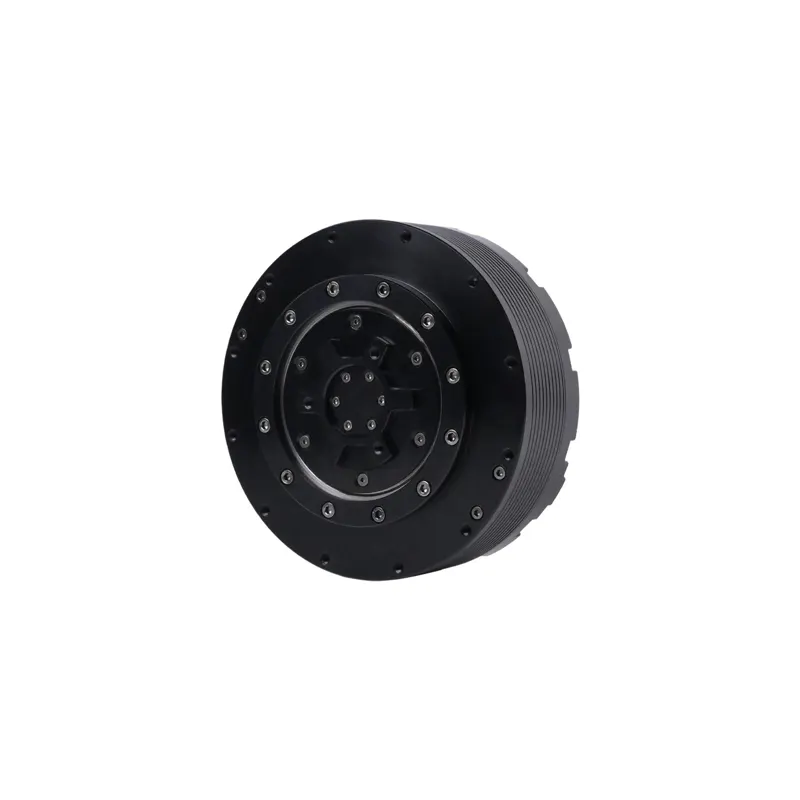
EYOBOT PHU enhanced harmonic joint module: φ142×144mm, 6130g (B) / 5650g (N), 22mm hollow shaft, ratio 81/101/121/161, peak torque 376-459 N·m, instantaneous max 702-848 N·m. Dual-absolute 19-bit encoders, EtherCAT/CANopen, 24-48V, >8000h life. Suits heavy-load hip and upper-leg joints of humanoid robots.
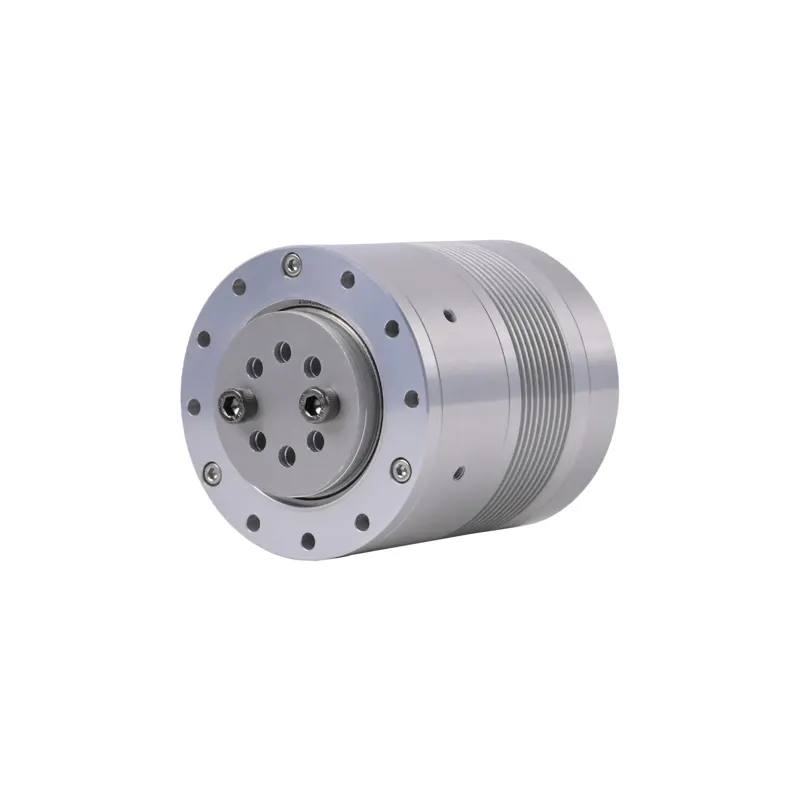
EYOBOT PHU enhanced harmonic joint module: φ110×94mm, 2545g (B) / 2354g (N), 13mm hollow shaft, ratio 81/101/121, rated torque at 2000rpm 78-84 N·m, peak 169/194/207 N·m, instantaneous max 315-376 N·m. Dual-absolute 19-bit encoders, EtherCAT/CANopen, 24-48V, >8000h life. Suits high-torque hip and knee joints of humanoid robots.
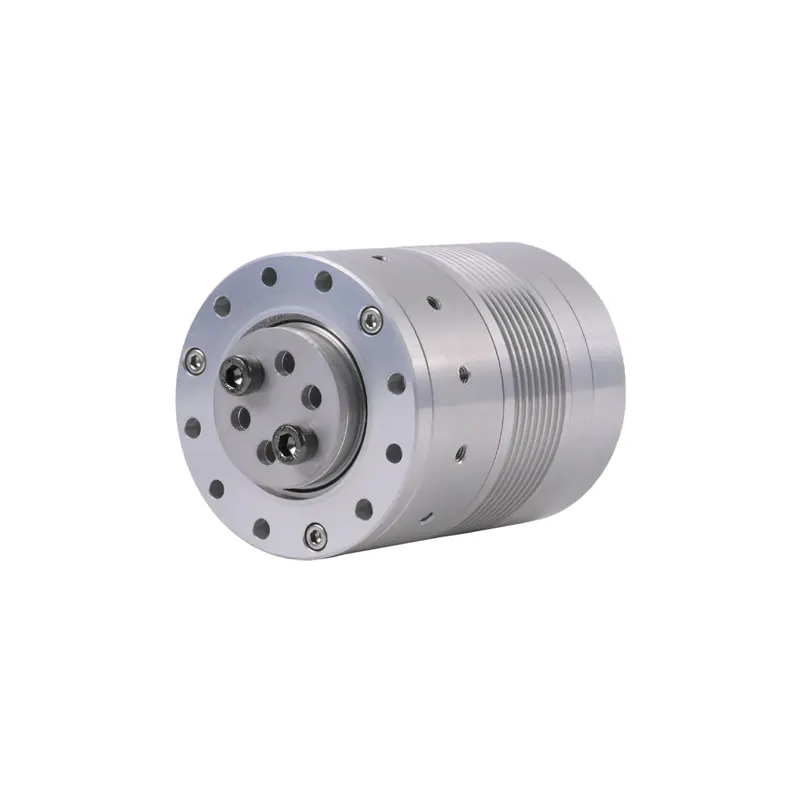
EYOBOT PHU enhanced harmonic joint module: φ70×75.4mm, 893g (B) / 812g (N), 10.8mm hollow shaft, ratio 51/101, peak torque 23/34 N·m, instantaneous max 43/66 N·m. Dual-absolute 19-bit encoders, EtherCAT/CANopen, 24-48V, optional power-off brake, >8000h life. Suits wrists, ankles and forearm joints of humanoid robots.
EYOBOT (designated supplier for Agibot A2) PHU enhanced harmonic joint module: φ40×56mm, only 196g, 4.4mm hollow shaft, ratio 51/101, peak torque 2.3/3.3 N·m, instantaneous max 4.6/6.3 N·m. Dual-absolute 19-bit encoders, EtherCAT/CANopen, 24-48V, >8000h life. The smallest model of the world's first automated mass-produced harmonic joint series, ideal for fingers and wrists of humanoid robots.
ENCOS (Nanjing Encos Intelligent Technology) EC-A series integrated joint module with two-stage planetary (ratio 23.625) with hollow-shaft cable routing: 100 N·m rated / 320 N·m peak torque, 235rpm peak speed, Φ106 × 87mm A / 84mm B, 1690g A / 1645g B. About 320 n·m peak (estimated) with 235 rpm high speed, aimed at high-load high-dynamics joints such as humanoid hips; a/b variants are different-thickness versions with power connectors.
ENCOS (Nanjing Encos Intelligent Technology) EC-A series integrated joint module with single-stage planetary (ratio 18) with hollow-shaft cable routing: 40 N·m rated / 130 N·m peak torque, 140rpm peak speed, Φ105 × 57mm, 968g. Hollow shaft for cable routing with higher torque than the 8112, suited to hip and shoulder joints of humanoid robots.
ENCOS (Nanjing Encos Intelligent Technology) EC-A series integrated joint module with single-stage planetary (ratio 18) with hollow-shaft cable routing: 30 N·m rated / 90 N·m peak torque, 157rpm peak speed, Φ105 × 53mm, 883g. Hollow shaft for cable routing and high speed, suited to shoulder/hip joints requiring internal wiring.
ENCOS (Nanjing Encos Intelligent Technology) EC-A series integrated joint module with single-stage planetary (ratio 12.67): 110 N·m rated / 320 N·m peak torque, 135rpm peak speed, Φ170 × 73mm, 2695g. 170 mm large diameter with 320 n·m peak torque, aimed at high-load joints such as humanoid hips.
ENCOS (Nanjing Encos Intelligent Technology) EC-A series integrated joint module with single-stage planetary (ratio 12): 50 N·m rated / 150 N·m peak torque, 140rpm peak speed, Φ124 × 60mm, 1373g. Large-diameter high-speed, suited to fast-swinging joints such as hips and shoulders of humanoid robots.
ENCOS (Nanjing Encos Intelligent Technology) EC-A series integrated joint module with size-20 harmonic drive (ratio 100): 40 N·m rated / 130 N·m peak torque, 47rpm peak speed, Φ73 × 84mm, 906g. Low-speed high-precision high-torque, suited to high-load precision joints such as hips and knees of humanoid robots.
ENCOS (Nanjing Encos Intelligent Technology) EC-A series integrated joint module with size-17 harmonic drive (ratio 100): 30 N·m rated / 90 N·m peak torque, 38rpm peak speed, Φ63 × 81.5mm, 630g. Low-speed high-precision, suited to medium-load precision joints such as elbows and shoulders of humanoid robots.